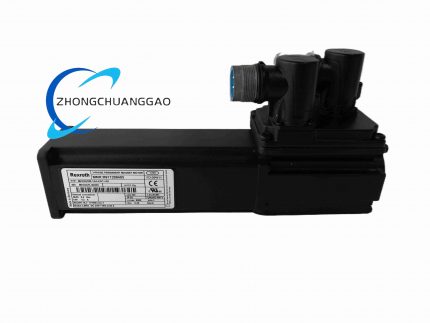
Rexroth MHD041B-144-PG1-UN

Product Name
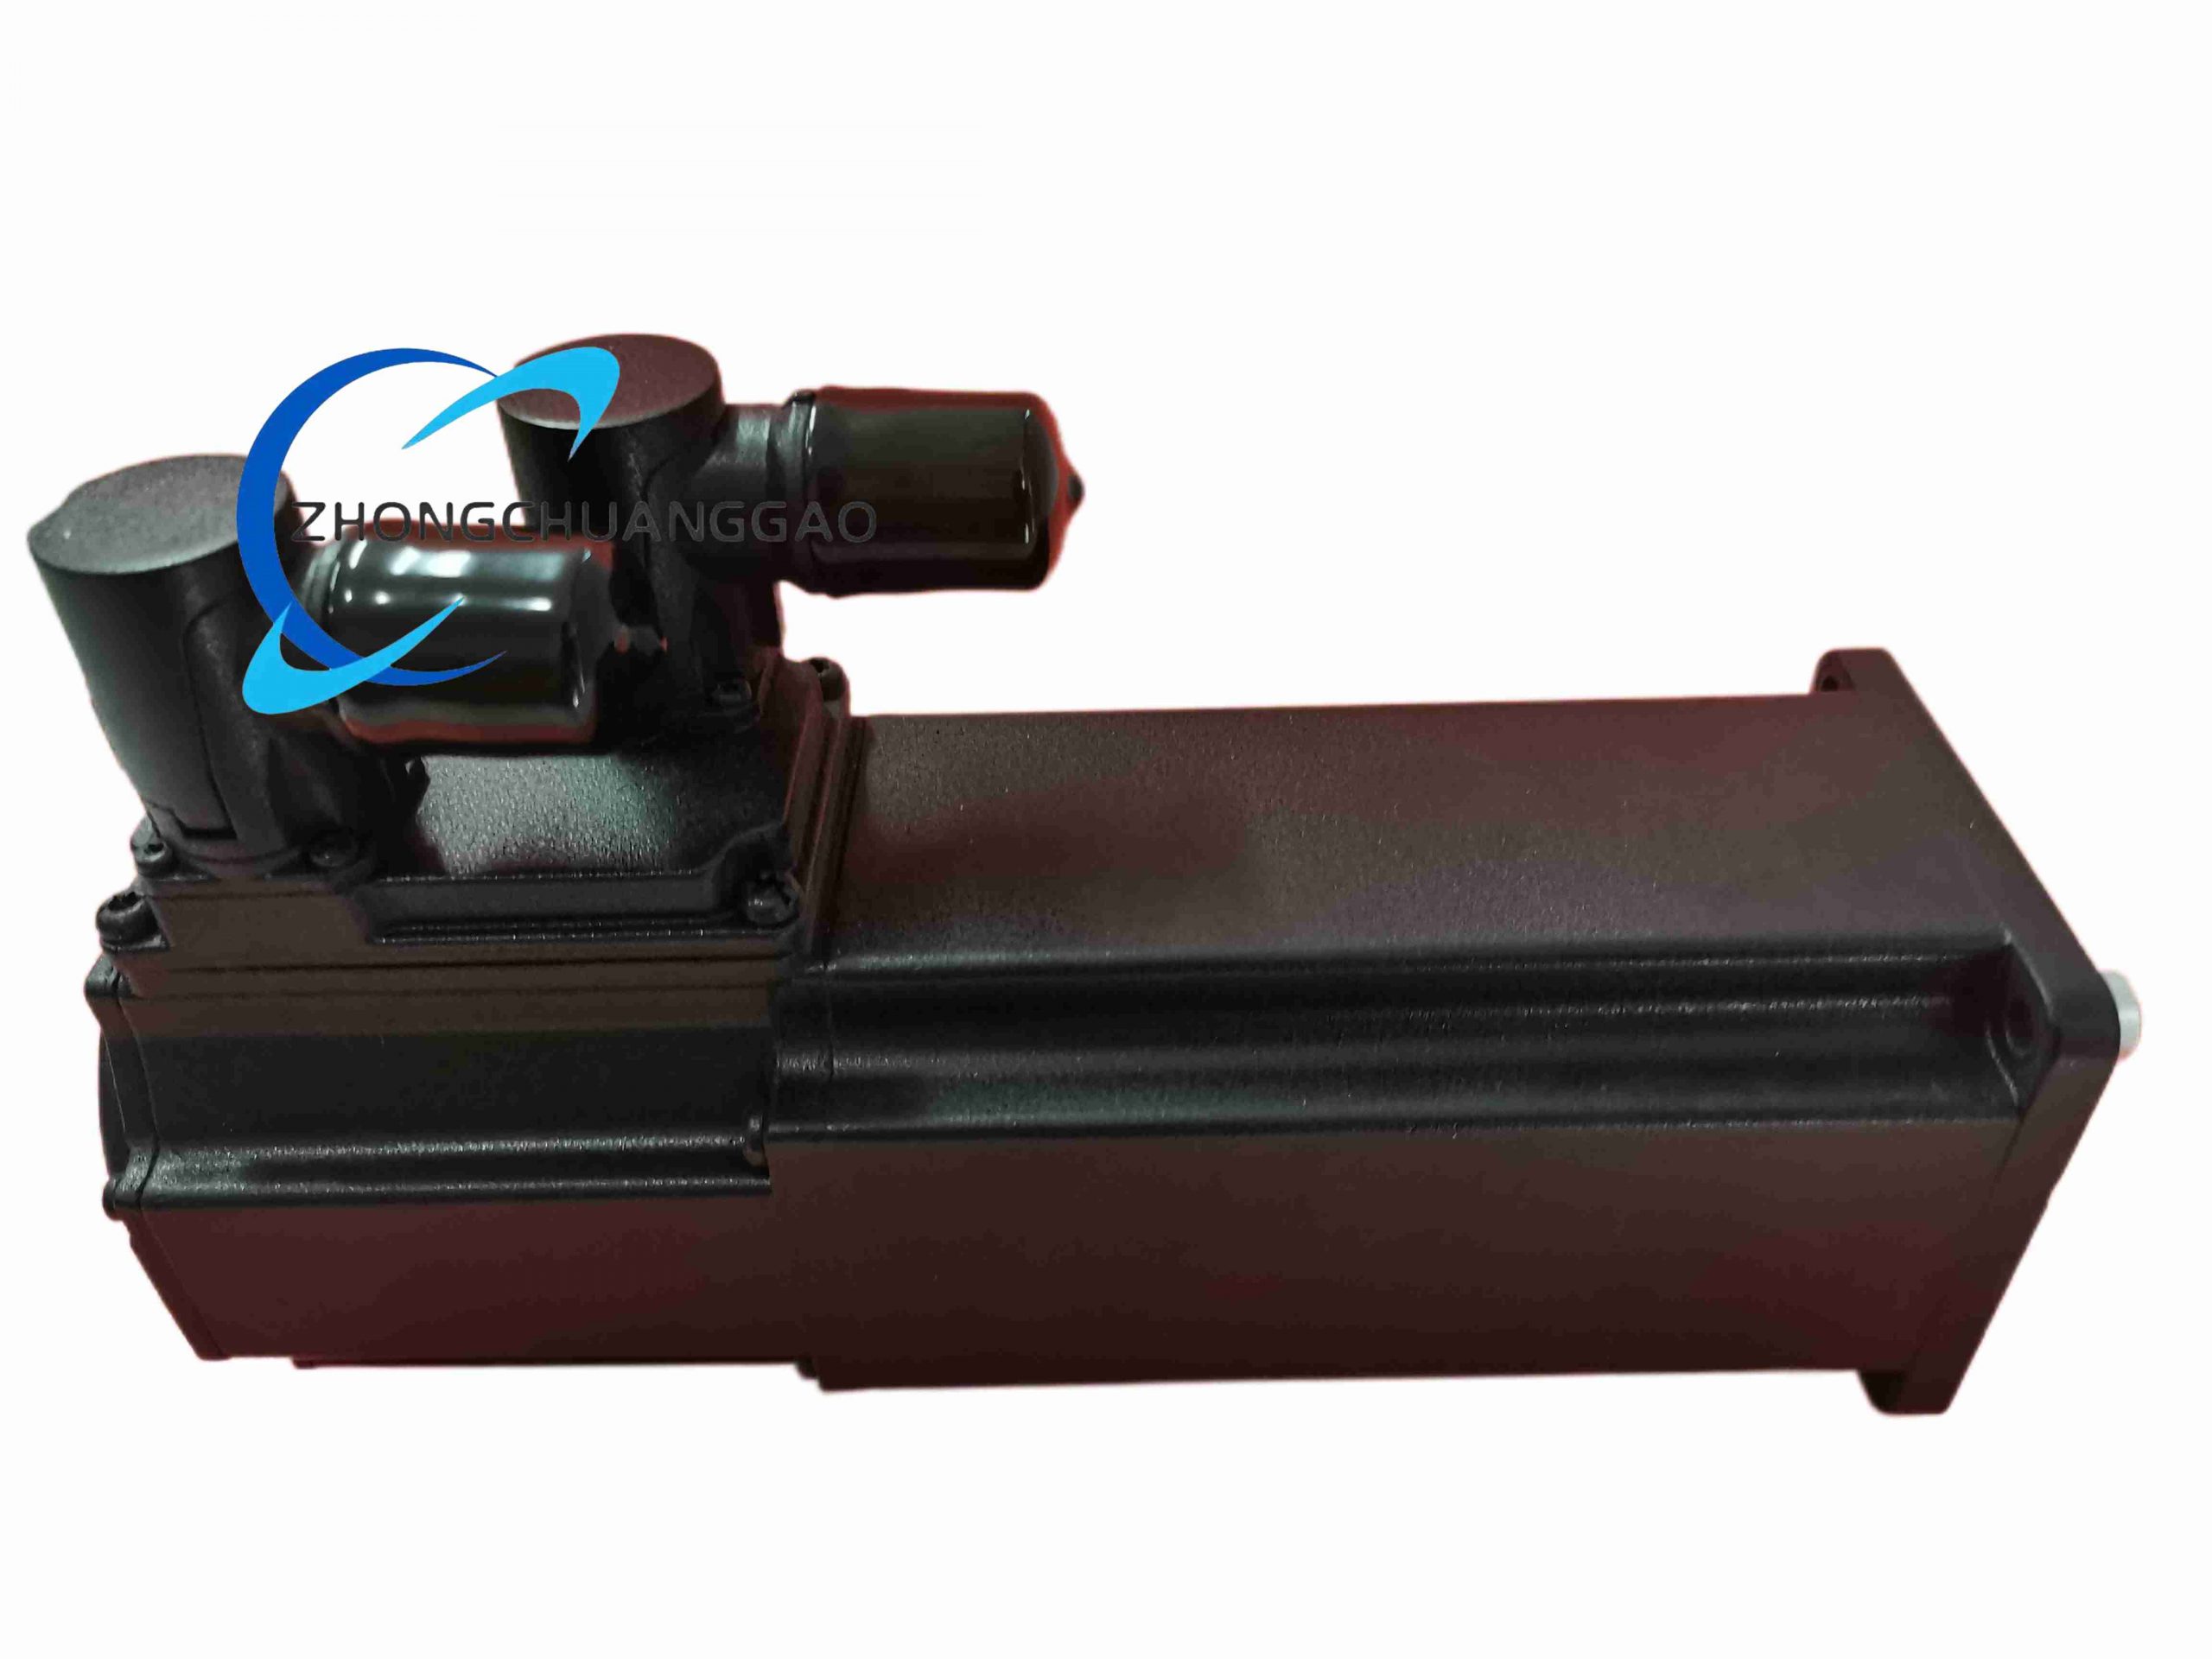
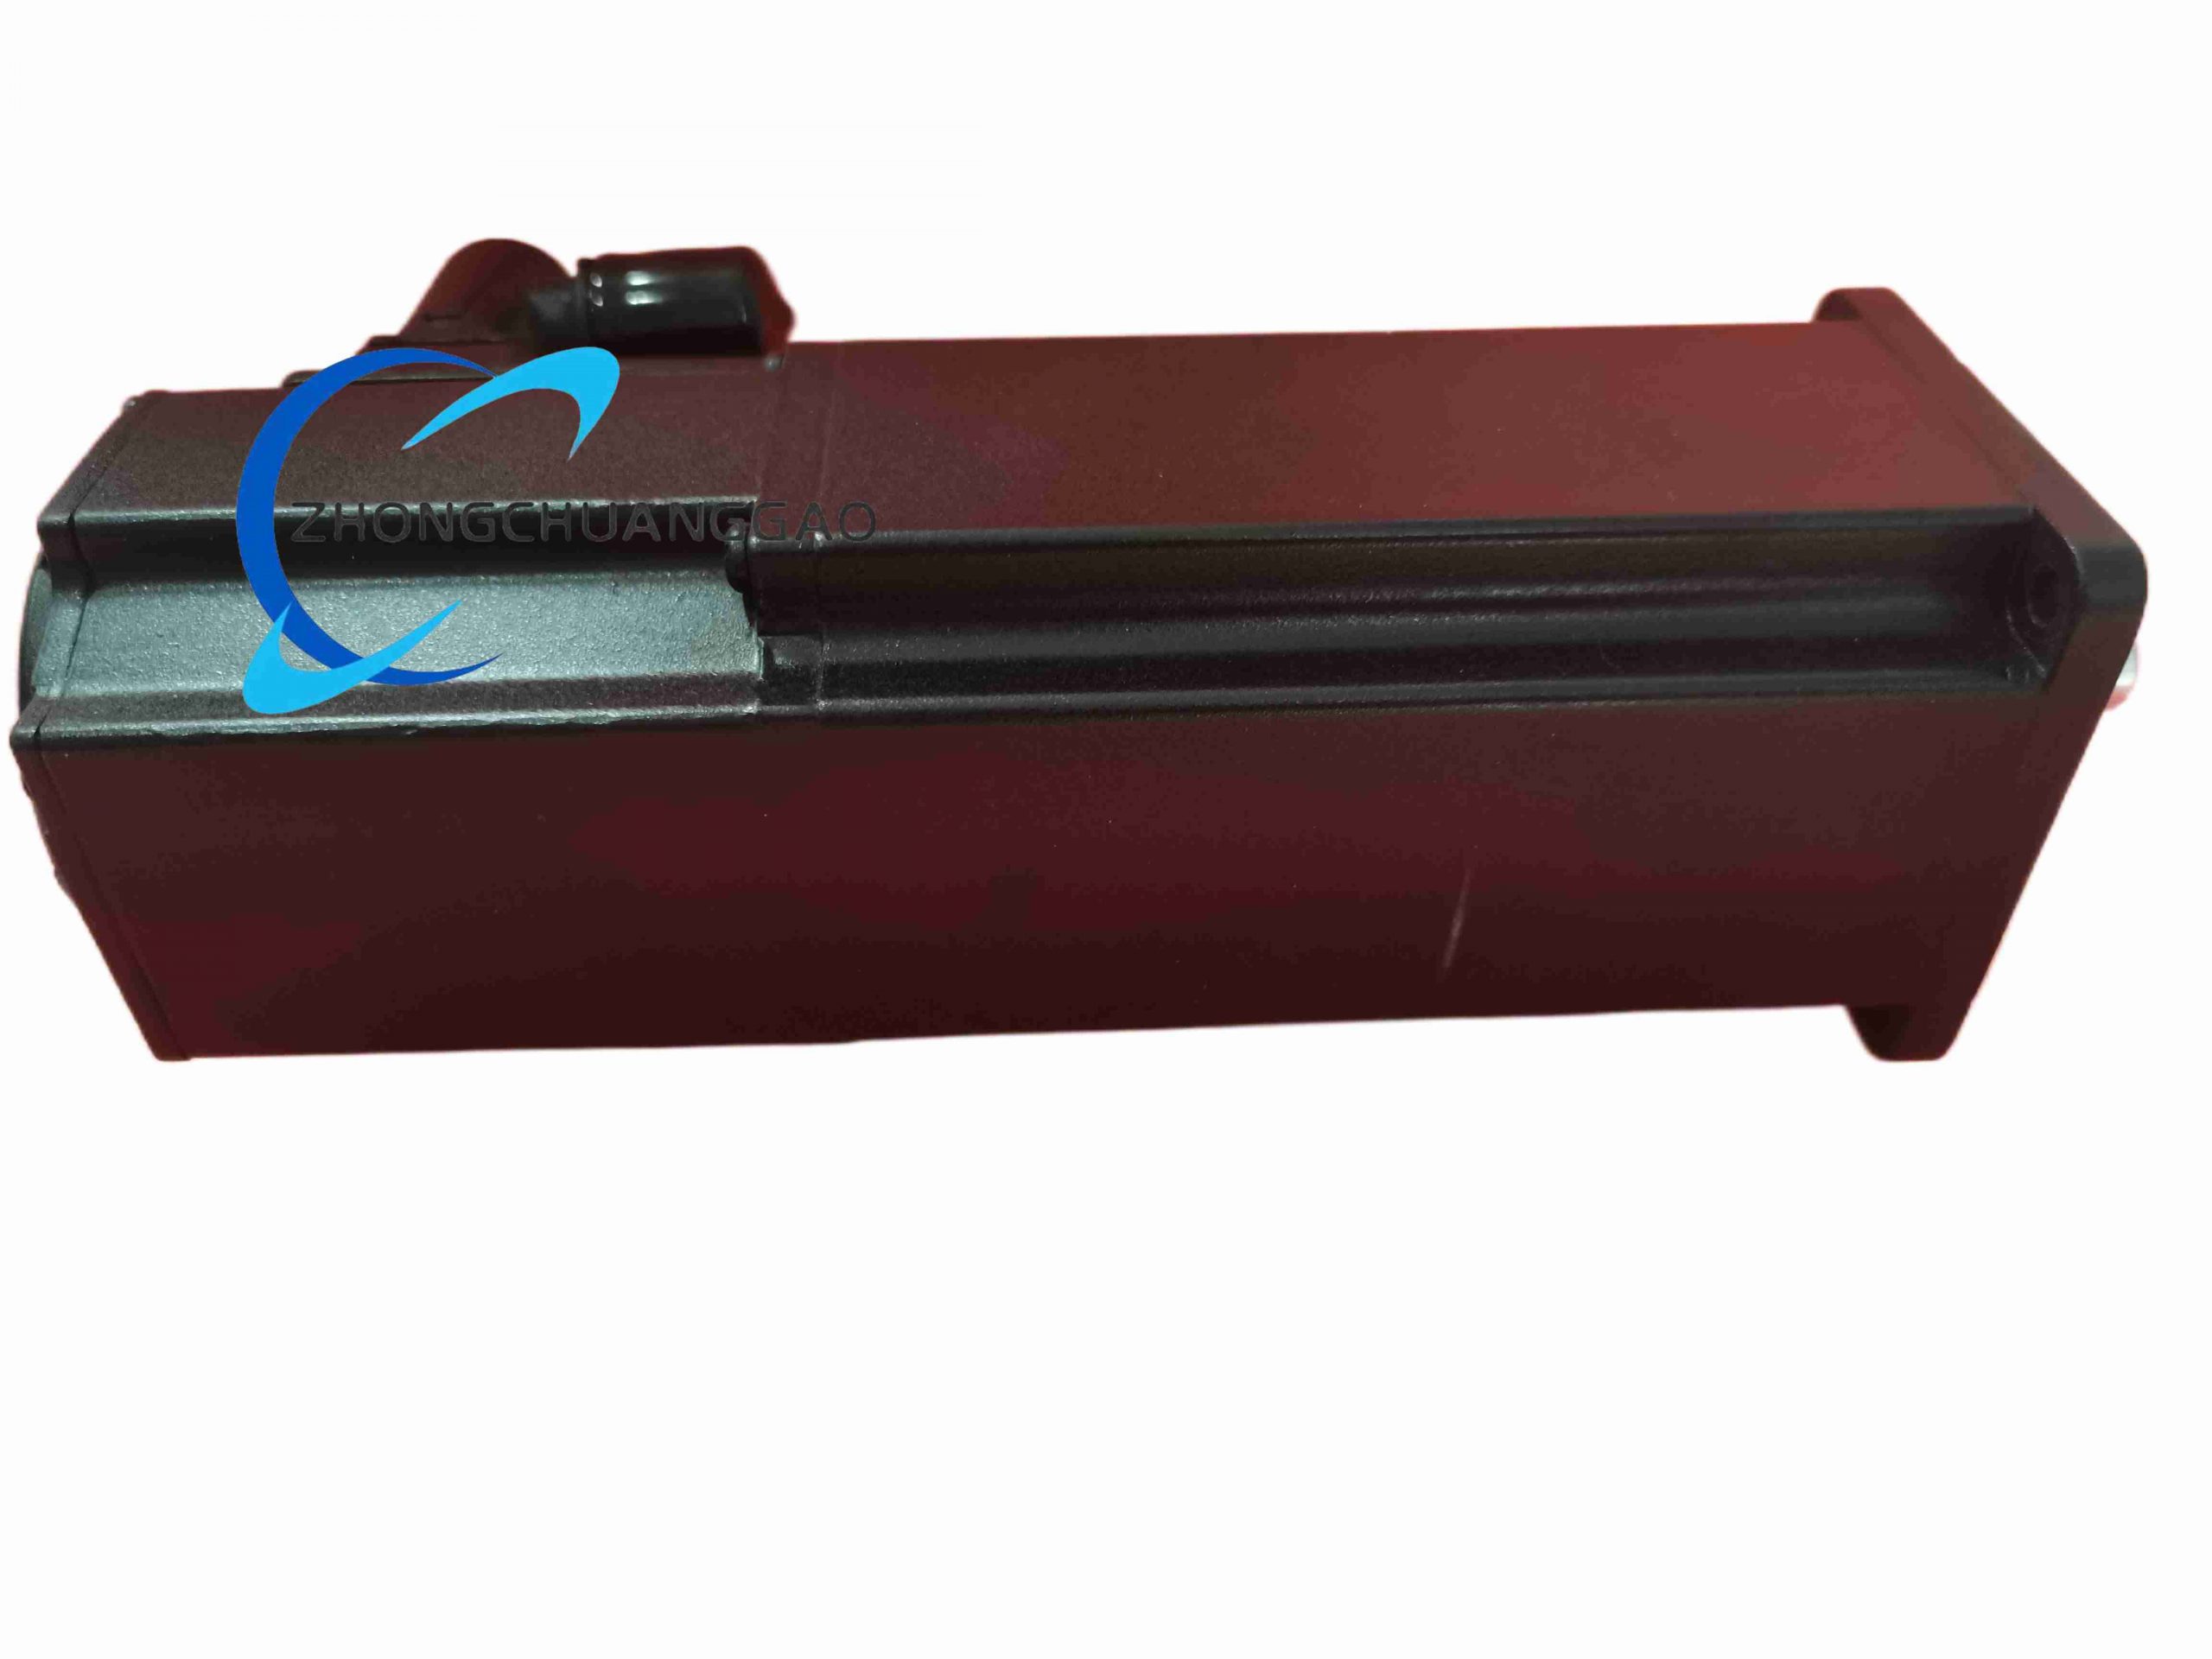
MHD series liquid-cooled permanent-magnet synchronous servo motor with holding brake and absolute digital feedback.
Product Introduction
MHD041B-144-PG1-UN is a Bosch Rexroth Indramat MHD synchronous servo motor intended for high-dynamic industrial motion axes. The 041 frame, 144 winding, liquid-cooled housing and 2.2 Nm holding brake support precise positioning and sustained torque duties.
Category:
Description
Technical Specifications
Motor family: MHD synchronous servo.
Size: 041.
Length: B.
Winding code: 144.
Flange size: 82 mm.
Centering diameter: 50 mm.
Continuous torque at standstill: 2.7 Nm.
Nominal current: 7.5 A.
Holding brake torque: 2.2 Nm.
Shaft: plain shaft with shaft seal.
Feedback: digital servo feedback with integrated encoder, absolute position detection over more than 4096 revolutions.
Cooling: liquid cooling.
Connectors: power and feedback connectors rotatable within 270°.
Protection class: IP65.
Functional Features
Liquid cooling sustains high current density in a compact frame.
Absolute encoder eliminates manual homing after power recovery.
Rotatable connectors simplify cable routing in tight cabinets.
Holding brake secures the load when power is removed.
Sealed shaft and IP65 housing resist dust and coolant ingress.
Application Scenarios
CNC feed axes, packaging systems, textile machines, handling gantries, robotic joints and automation cells requiring accurate torque and position control.
Performance Parameters
The motor delivers 2.7 Nm continuous standstill torque with 7.5 A nominal current. The absolute encoder provides multivolt/rev absolute tracking for repeatable restart. The 2.2 Nm brake holds stationary axes during power loss. Liquid cooling stabilizes winding temperature under continuous cyclic load.
Material Composition
Cast aluminum or cast-iron motor housing with liquid jacket, copper stator windings, permanent-magnet rotor, steel shaft with seal, electronic encoder assembly, spring-applied electromagnetic brake and corrosion-resistant connector housings.
Structural Characteristics
Cylindrical or square MHD housing with liquid cooling passages, 82 mm mounting flange, 50 mm centering pilot, rear connector plate with 270° rotation, integral brake stack and sealed encoder compartment.
Working Principle
The servo drive produces regulated three-phase current according to the control loop. The permanent-magnet rotor follows the stator field. The digital encoder reports absolute rotor position to the drive. The brake releases with the specified control voltage and engages mechanically when de-energized. Liquid coolant circulates through the housing jacket to remove heat.
Installation Requirements
Mount the motor on a flat 82 mm flange with 50 mm centering bore alignment. Connect inlet and outlet coolant lines with proper flow, pressure and filtration. Orient power and feedback connectors within the 270° range for shortest cable path. Bond the housing to protective earth. Configure the drive for 144 winding, absolute encoder and brake release voltage.
Usage Precautions
Maintain uninterrupted coolant flow during operation. Verify brake release voltage and do not use the brake for continuous stopping duty. Inspect shaft seal and connector seals regularly. Prevent coolant leaks onto electrical connectors. Validate encoder communication after every cable replacement.
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “Rexroth MHD041B-144-PG1-UN”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.