A-B MPL-B540K-SJ24AA

Product Name
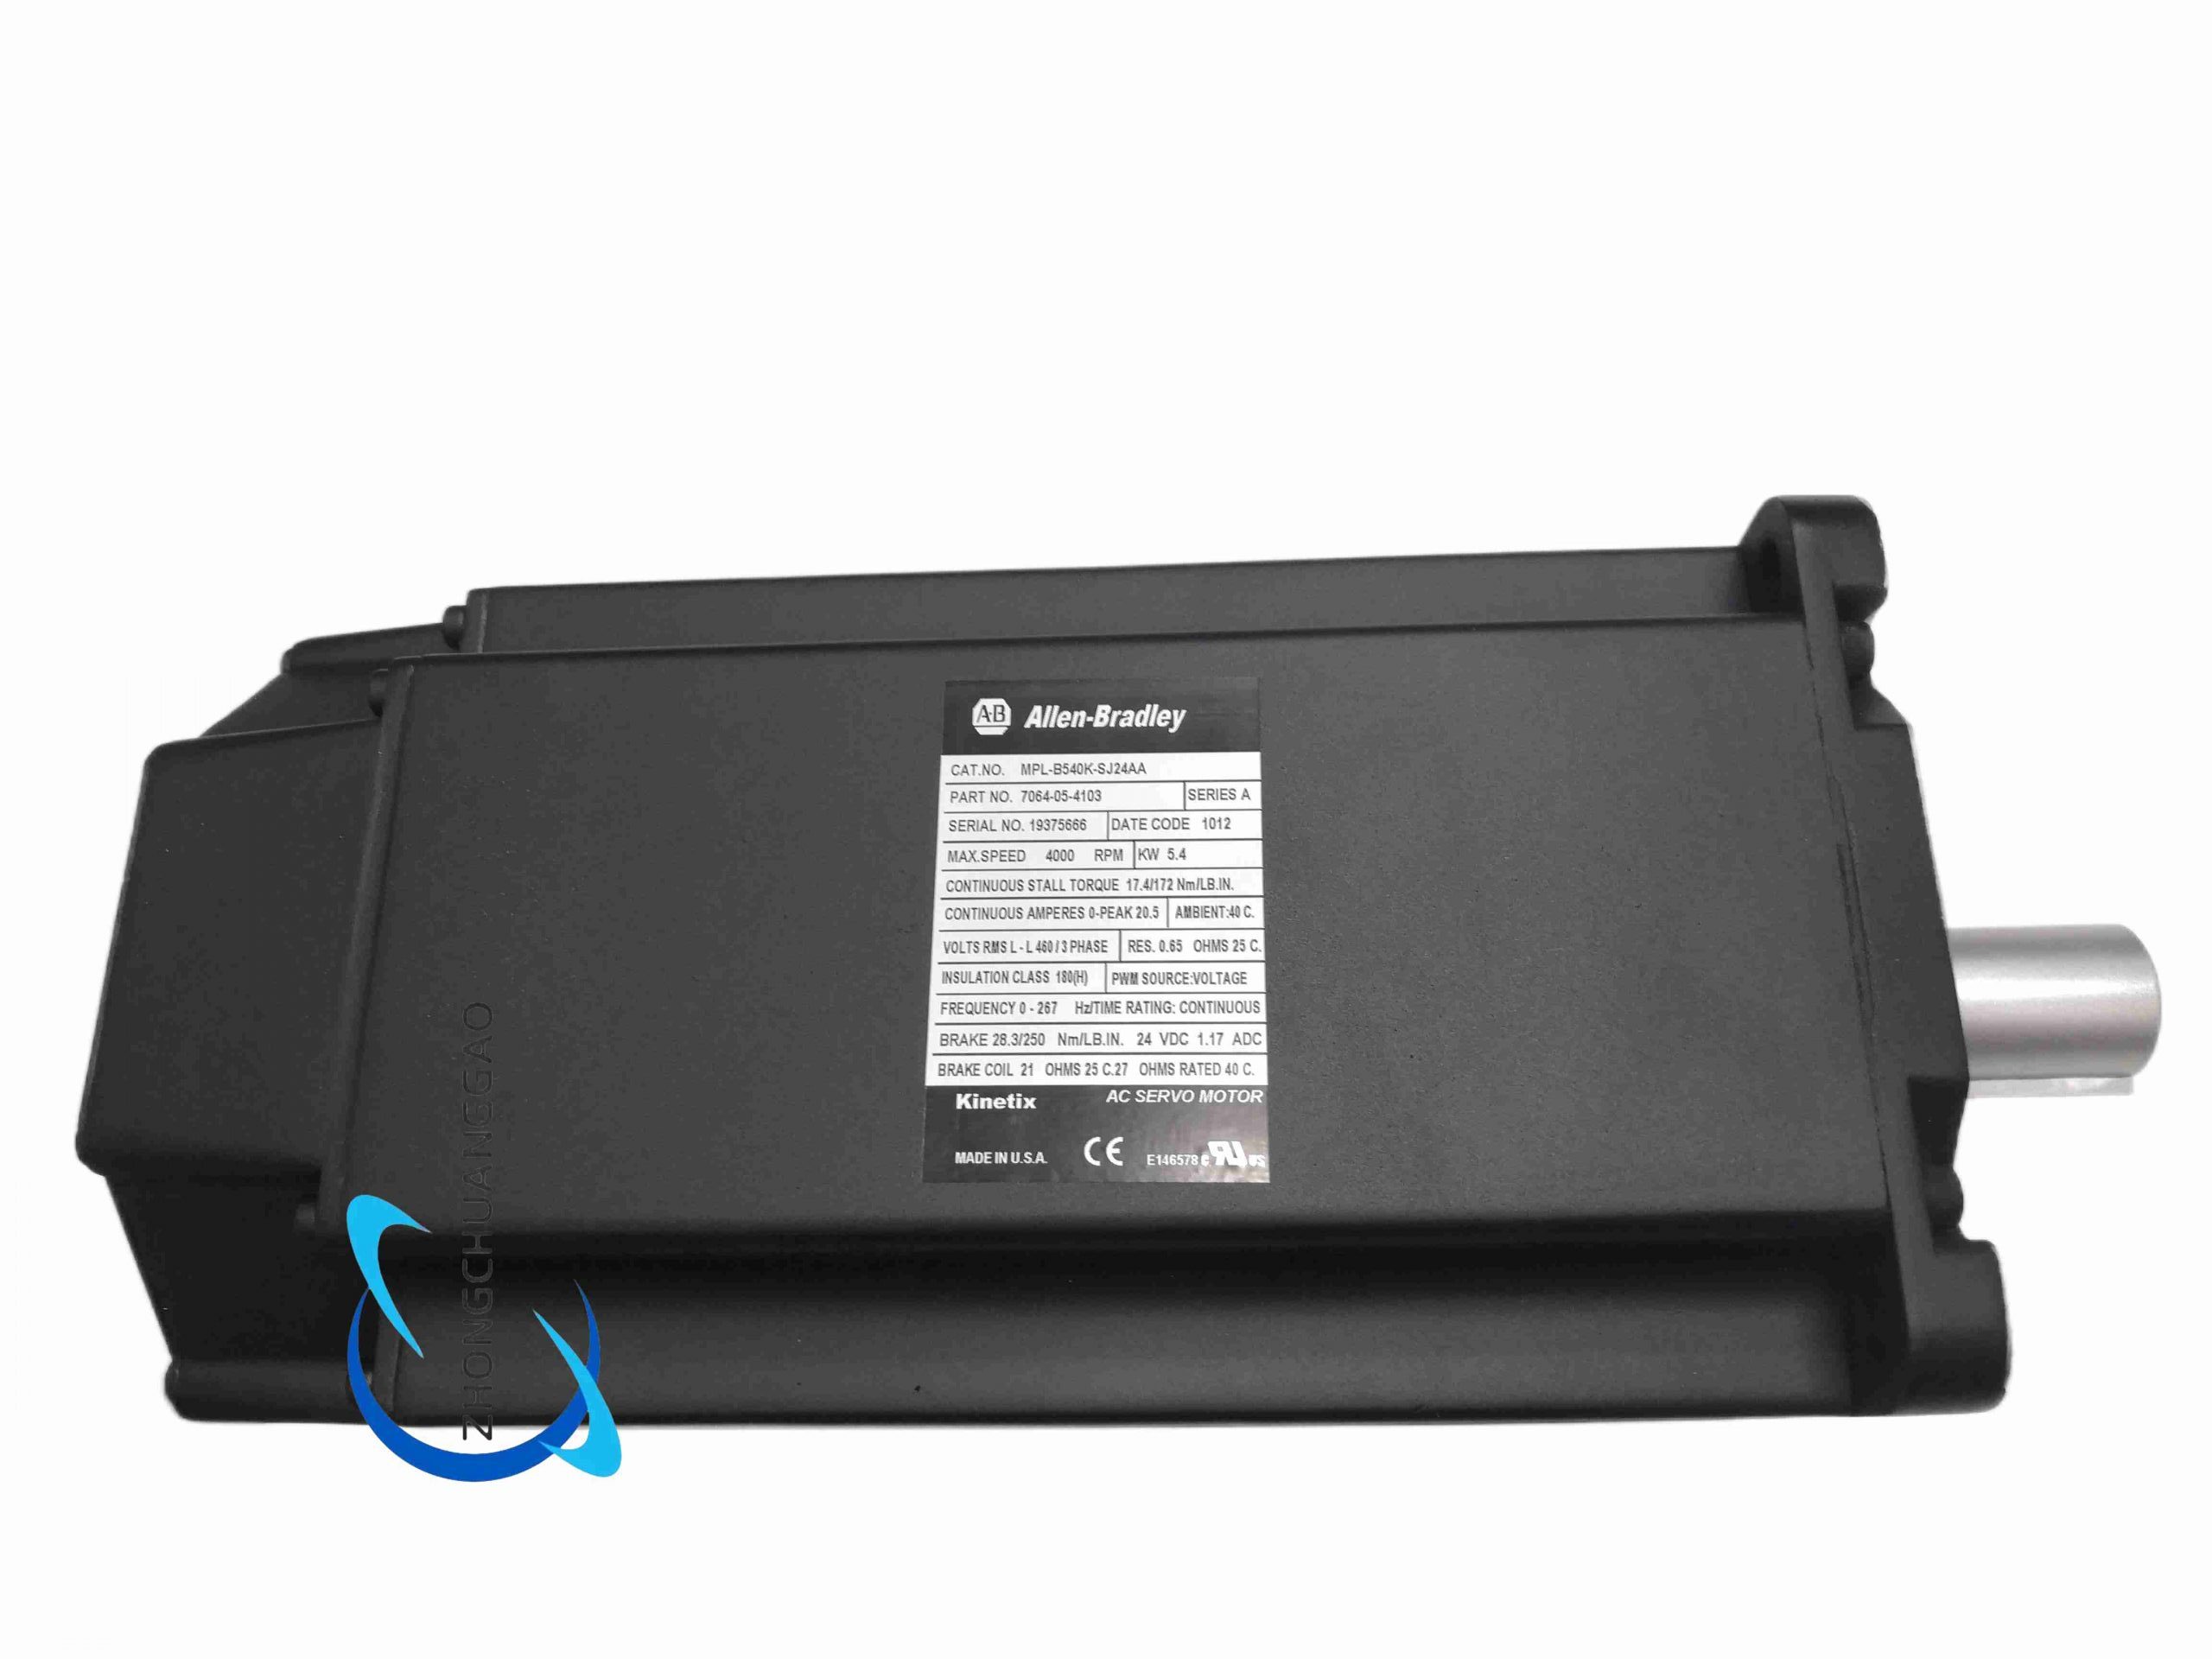
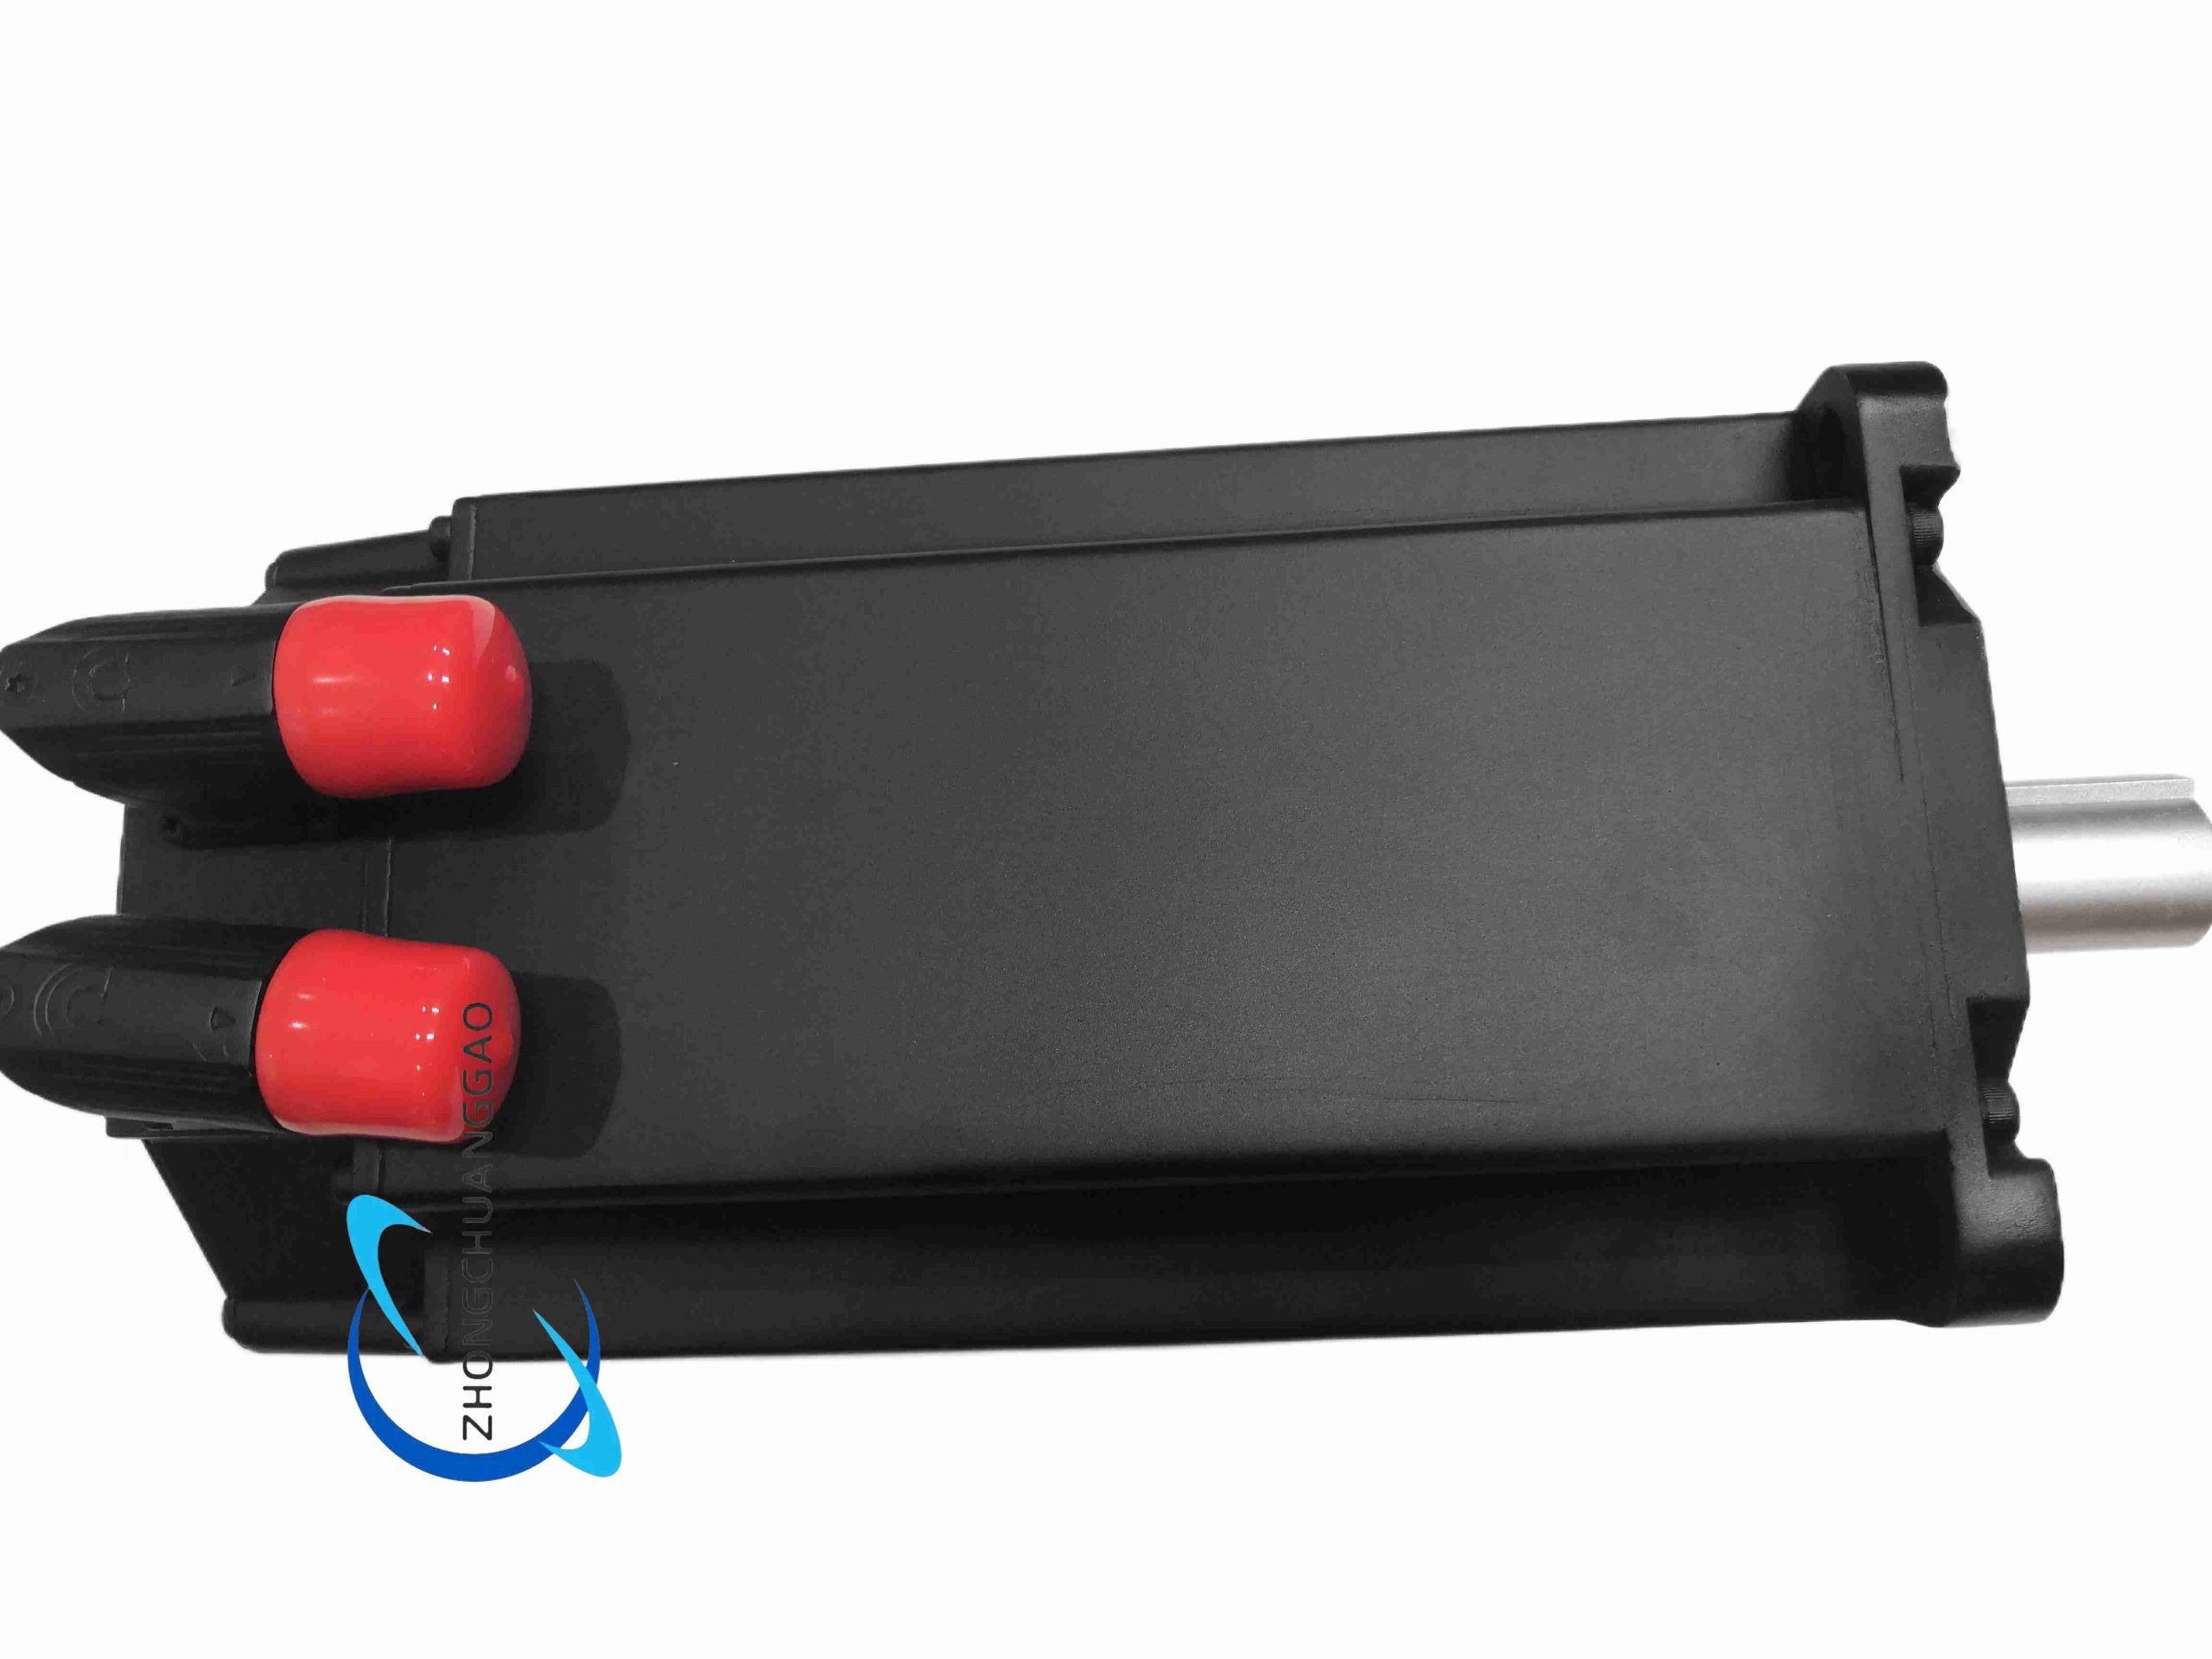
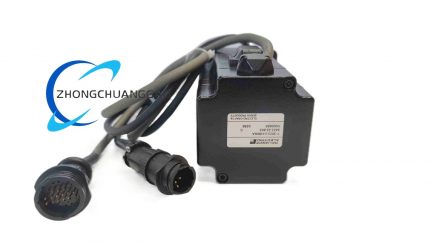
Allen-Bradley MPL-B540K-SJ24AA low-inertia AC permanent-magnet rotary servo motor
Product Introduction
This motor belongs to the Rockwell Automation MP-Series low-inertia servo family. It is built for high-speed positioning, velocity regulation and torque control in machine automation. The design combines a permanent-magnet rotor, high-resolution absolute encoder and integral holding brake to support rapid acceleration, accurate feedback and safe holding under power loss.
Category:
Description
Technical Specifications
Parameter​
Value​
Rated voltage class​
400 VAC, 3-phase servo drive supply
Rated output power​
5.4 kW
Rated speed​
4000 rpm
Continuous stall torque​
172 lb-in, 19.4 Nm
Peak stall torque​
420 lb-in, 47.4 Nm
Rotor inertia​
0.014 lb-in-s², 0.00147 kg·m²
Frame / stack length​
165 mm frame, 101.6 mm magnet stack, 4 in
Approximate weight​
33 lb, 15 kg
Feedback​
1024 sin/cos absolute single-turn encoder, Hiperface protocol
Brake​
24 VDC electrically released holding brake
Connector​
Circular bayonet motor connectors, shaft-facing orientation
Shaft​
Keyed shaft, optional shaft seal kit
Mounting flange​
IEC metric flange
Standard protection​
IP50 base, higher rating with seal kit option
Functional Features
High torque density with low rotor inertia for fast dynamic response. Absolute single-turn encoder removes unnecessary homing on restart. Integral 24 VDC brake holds the load during stop and power loss. Rotatable circular bayonet connectors simplify cable routing. IEC metric flange and keyed shaft provide standardized mechanical integration.
Performance Parameters
Sustained operation at 4000 rpm with 5.4 kW output, 19.4 Nm continuous stall torque and 47.4 Nm peak stall torque. Low-inertia rotor supports short cycle times in high-duty indexing, feed and transfer applications. Encoder resolution and Hiperface interface maintain precise position loop performance with Rockwell servo drives.
Materials And Construction
Aluminum or alloy motor frame with standardized MP-Series mechanical dimensions. Permanent-magnet rotor assembly, laminated stator, sealed bearing system and optional shaft seal. Bayonet connector housings use industrial-grade molded bodies rated for the stated voltage class.
Working Principle
The servo drive energizes the stator windings in a controlled sequence. The permanent-magnet rotor follows the rotating magnetic field. The encoder returns position and speed to the drive; the controller adjusts current to regulate torque, velocity or position. The 24 VDC brake engages mechanically when de-energized and releases when powered.
Application Scenarios
CNC feed axes, packaging machines, material handling, robotic indexers, converting equipment, assembly systems and high-speed automated production lines.
Installation Requirements
Mount on a flat IEC metric flange using correct bolt grade. Align the keyed shaft with the machine coupling to avoid side load on bearings. Use designated servo power and encoder cables. Verify drive voltage class, encoder compatibility and brake supply before energizing. Provide adequate ventilation for continuous 4000 rpm duty.
Usage Notes
Inspect shaft seals periodically in dusty or wet environments. Confirm brake function after maintenance. Do not operate without proper servo drive commissioning. Use only Rockwell-approved encoder and power cables. Record rotor inertia, stack length and flange data when replacing existing MP-Series motors.
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “A-B MPL-B540K-SJ24AA”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.