Technical Specifications
- Input Power: Single-phase 120 / 240 VAC 50/60 Hz universal mains input
- Continuous RMS Output Current: 8 A
- Peak Transient Overload Current: 20 A RMS (1.5 second maximum overload duration)
- Compatible Motor Power Range: 750 W – 2000 W Parker permanent magnet brushless servo motors
- Supported Feedback Devices: Incremental quadrature encoder, EnDat absolute encoder, Parker Smart Encoder auto-recognition
- Communication Interfaces: CANopen, SERCOS II, RS232 serial, Modbus RTU fieldbus protocols
- Supported Control Modes: Position closed-loop, velocity closed-loop, torque closed-loop, electronic gearing, electronic cam interpolation, standalone motion sequencing
- External Command Inputs: ±10 V analog reference signal, step/direction pulse train, 8-channel isolated digital input, 4-channel programmable digital output
- Position Feedback Processing Resolution: 24-bit high-precision encoder signal sampling
- Integrated Protection Logic: Over-current, over-voltage, under-voltage, power stage over-temperature, motor winding phase fault, encoder signal loss, hardware emergency stop interlock
- Mounting Architecture: Plug-in module for Parker AR series shared multi-axis rack chassis
- Operating Ambient Temperature: 0 °C – 45 °C cabinet internal air temperature
- Industrial Safety Certifications: CE EMC/LVD compliance, UL508c, cUL listed
- Net Weight: 1.5 kg
Functional Features
- Parker Smart Encoder auto-detection function automatically loads all motor rated parameters on power-up without manual configuration
- Real-time CANopen multi-axis synchronization with microsecond-level setpoint alignment for heavy-duty gantry and printing press motion systems
- Embedded standalone motion programming engine for independent axis positioning without external master motion controller
- Permanent fault history storage with timestamped error codes for rapid equipment maintenance troubleshooting
- Front panel multi-status LED indicator array for power supply, servo enable, fieldbus communication and fault alarm status visualization
- Complete galvanic isolation between AC mains power stage, digital control logic and motor feedback circuits to eliminate industrial ground loop interference
- Hot-swappable rack module construction enabling single-axis drive replacement without full rack mains power cut-off
Working Principle
Single-phase AC mains input flows through internal EMI suppression filter and full-wave diode rectifier to generate shared DC bus voltage within the AR rack chassis. The drive’s 32-bit floating-point DSP motion processor receives motion reference signals from analog voltage, pulse train or industrial fieldbus communication channels, while continuously sampling high-resolution position feedback from the motor encoder. Advanced field-oriented control (FOC) algorithm calculates sinusoidal three-phase output current for the servo motor stator windings to deliver precise closed-loop torque, velocity and position regulation. Smart Encoder detection circuit reads non-volatile parameter memory inside Parker servo motor encoders to auto-configure motor pole count, rated current and voltage parameters during initial power cycle. Real-time monitoring circuits sample DC bus voltage, output phase current and power semiconductor junction temperature; out-of-limit operating conditions immediately disable three-phase inverter switching and lock fault data to internal flash memory for host system readback. CANopen and SERCOS communication ports synchronize motion command data with adjacent rack-mounted servo drives for coordinated multi-axis heavy-load movement.
Material Composition
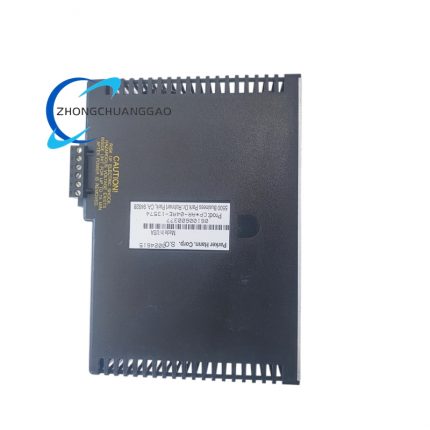
- Module Enclosure: Black powder-coated extruded aluminum alloy frame integrated with vertical finned passive heat sink
- Power Stage Substrate: Aluminum nitride high thermal conductivity base PCB for IGBT power device heat dissipation
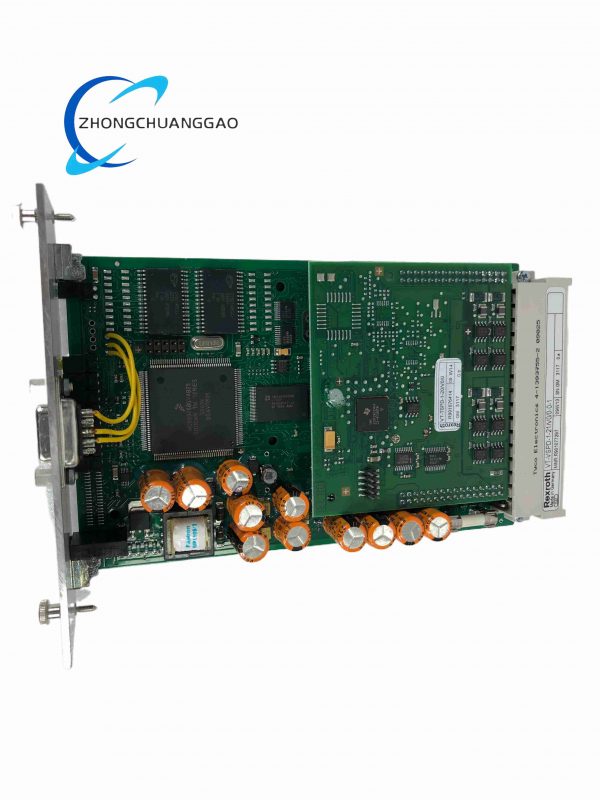
- Digital Control Circuit Board: FR-4 fiberglass signal PCB with optocoupler isolated digital I/O interfaces
- Rack Backplane Contact Strip: Gold-plated copper alloy spring contacts for shared rack DC bus and inter-axis communication bus
- Wiring Terminal Blocks: Vibration-resistant spring-clamp insulated copper terminals for motor power cable and encoder feedback wiring
Structural Characteristics
- Standard AR rack plug-in module mechanical form factor, vertically stackable with AR-04AE low-current drives inside unified rack chassis
- Taller finned aluminum heat sink structure to accommodate higher power stage heat generation from 8 A continuous output current
- Rear edge gold-plated multi-pin contact strip connects to rack backplane for shared mains rectified DC bus and inter-axis fieldbus communication
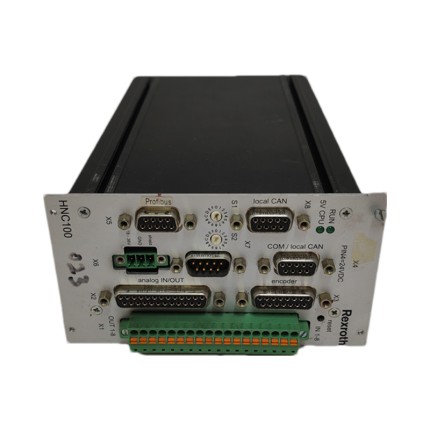
- All motor power, encoder and external I/O wiring terminals centralized on front panel for simplified harness routing
- Spring mechanical locking latch on module side wall prevents vibration-induced disconnection from rack backplane during heavy machine operation
Advantage Highlights
- Higher 8 A continuous output rating supports heavy torque servo motors for injection molding, metal cutting and heavy packaging machinery axes
- Unified rack platform compatible with AR-04AE low-current modules to build mixed high/low power multi-axis motion control systems
- Smart Encoder automatic parameter identification drastically reduces field commissioning engineering time
- Shared rack DC bus architecture eliminates redundant power supply hardware for each independent axis, lowering cabinet component cost and space occupation
- Hot-swap module design minimizes unplanned production downtime during single-axis drive failure replacement
- Multi-protocol industrial fieldbus compatibility enables seamless integration with all mainstream PLC and upper-level motion control platforms
- Vibration-resistant spring-clamp wiring terminals maintain stable electrical connection under continuous heavy machine vibration cycles
Applicable Industries
Heavy-duty packaging machinery, offset printing presses, metal CNC machining centers, injection molding auxiliary axis control, automated warehouse heavy material handling gantries, textile weaving equipment, industrial robotic heavy payload manipulators
Installation Requirements
- Install module only within matching Parker AR series shared multi-axis rack chassis; rack must be vertically mounted inside IP54 or higher industrial control cabinet
- Maintain minimum 20 mm vertical airflow clearance between stacked drive modules to avoid heat accumulation
- Motor encoder feedback wiring must use shielded differential twisted pair cable, physically separated from high-current motor power cables to reduce electromagnetic noise coupling
- Rack chassis must connect to dedicated equipment protective earth ground bus to suppress radiated EMI interference
- Auxiliary cabinet forced cooling fan mandatory for continuous full-load operation at ambient temperature above 35 °C
Usage Precautions
- Strictly limit AC mains input voltage within 100 VAC – 264 VAC; overvoltage permanently damages internal rectifier power components
- Verify encoder wiring pinout matches Parker Smart Encoder specification before applying mains power; miswiring triggers persistent encoder loss fault state
- Continuous operation above rated 8 A output current limited to maximum 1.5 seconds to activate thermal protection shutdown
- Monthly cleaning of rack ventilation filter required to prevent dust blockage of heat sink fin airflow
- Store spare drive modules in temperature-controlled low-humidity storage environment to prevent gold-plated backplane contact oxidation and corrosion





Reviews
There are no reviews yet.