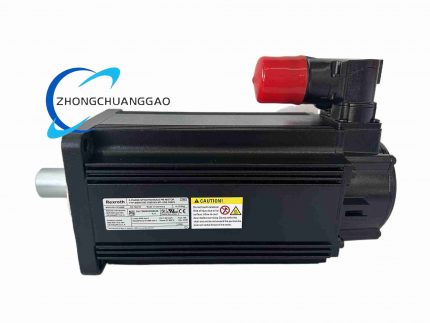
Rexroth MSK060C-0600-NN-S1-UP1-NNNN

Product Name
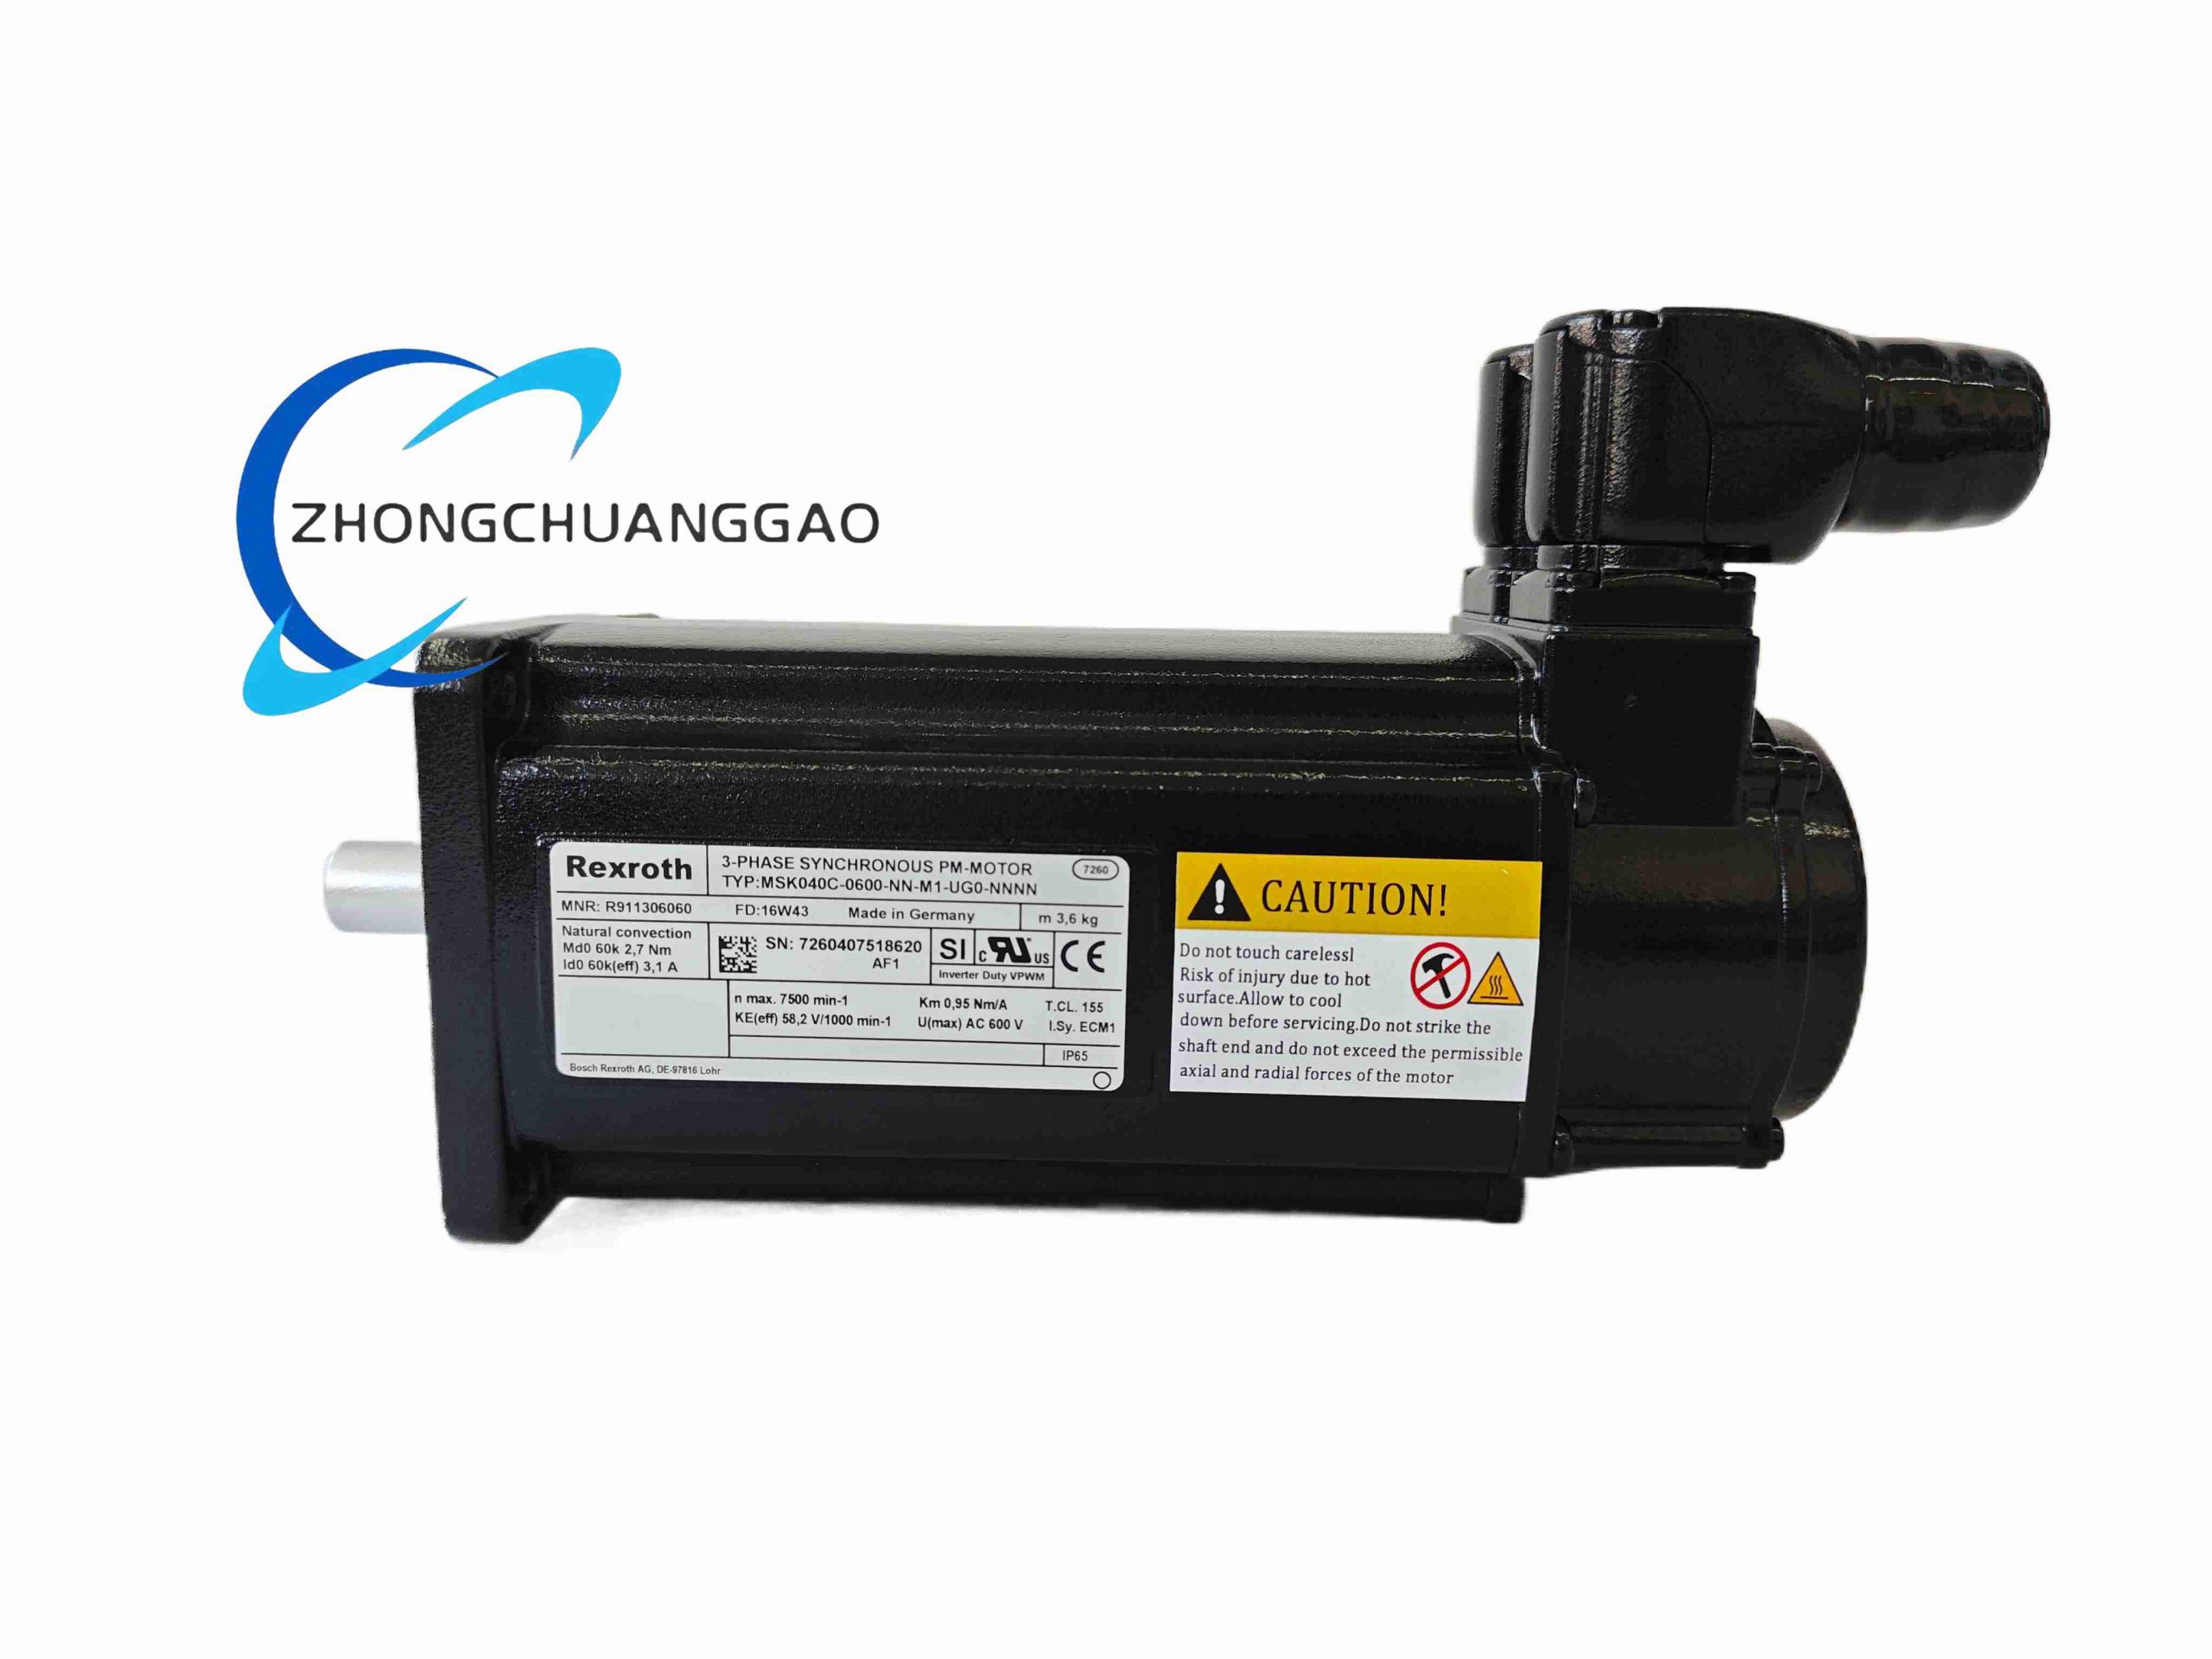
Bosch Rexroth MSK060C-0600-NN-S1-UP1-NNNN IndraDyn S permanent-magnet synchronous servo motor
Product Introduction
This MSK060C motor is part of the Rexroth IndraDyn S high-dynamic servo family. It is intended for precision motion control with IndraDrive controllers and other compatible servo systems. The 060 frame with C length and 0600 winding provides high-speed operation, while the encoder and construction support demanding positioning tasks.
Category:
Description
Technical Specifications
Parameter​
Value​
Motor series​
IndraDyn S MSK synchronous servo motor
Frame size​
060, approximately 82 mm width by 124.5 mm height
Length code​
C, medium/extended length, approximately 185.5 mm stack housing length depending on options
Winding code​
0600, high-speed winding
Rated / maximum speed​
Maximum approximately 6000 rpm; rated speed according to drive and thermal setup
Continuous torque​
Approximately 8.8 Nm at rated duty
Peak torque​
Approximately 24 Nm short-term
Continuous current​
Approximately 10.5 A
Peak current​
Approximately 38 A
Voltage class​
3-phase 380–480 VAC servo supply with IndraDrive
Encoder​
Hiperface encoder; S1 code defines single-turn/interface configuration, confirm exact turn count from order code
Encoder resolution​
Optical Hiperface, 128 signal periods per turn standard for MSK; higher digital resolution depends on drive and encoder option
Cooling​
Natural convection, surface cooling
Protection rating​
IP65 with appropriate shaft seal and connector configuration
Insulation class​
F, 155 °C
Brake and shaft options​
UP1 defines shaft, brake or connector variant; confirm brake presence from original order code
Mounting​
Standard servo flange, keyed or smooth shaft according to configuration
Functional Features
High torque density for compact machine designs. Hiperface feedback supports accurate position and speed loops. Natural convection reduces maintenance compared with forced-air cooling. Modular encoder, shaft, brake and connector options adapt the motor to robotics, CNC and automation systems.
Performance Parameters
Continuous 8.8 Nm output with 10.5 A rated current supports sustained cyclic motion. Peak 24 Nm with 38 A supports acceleration and overload transients. 6000 rpm maximum winding speed suits high-throughput spindle feeds, handling and indexing.
Materials And Construction
Aluminum stator housing, rare-earth permanent-magnet rotor, insulated windings, sealed bearings and IP65 exterior seals where specified. Rotatable encoder and power connectors simplify cabinet layout.
Working Principle
The servo inverter supplies 3-phase current to the stator. The permanent-magnet rotor follows the rotating field. The Hiperface encoder returns position data to the drive, which regulates current vectors for torque, speed or position control. Optional brake holds the shaft when de-energized.
Application Scenarios
Robotics, CNC axes, packaging machines, semiconductor handling, pick-and-place systems, printing presses and high-speed assembly equipment.
Installation Requirements
Install with standard servo flange and verified shaft alignment. Use Rexroth-approved power and encoder cables. Match drive parameters to 0600 winding, encoder type and brake option. Provide IP65 conditions only when shaft seal and connectors are correctly fitted. Ensure cooling air or convection space around the motor body.
Usage Notes
Confirm S1 encoder type and UP1 brake/shaft/connector details from the original order code before replacement. Avoid exceeding 6000 rpm winding limit. Check brake release voltage where fitted. Inspect seals, bearings and encoder connectors during preventive maintenance. Use IndraDrive commissioning tools for encoder alignment and parameter backup.
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “Rexroth MSK060C-0600-NN-S1-UP1-NNNN”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.