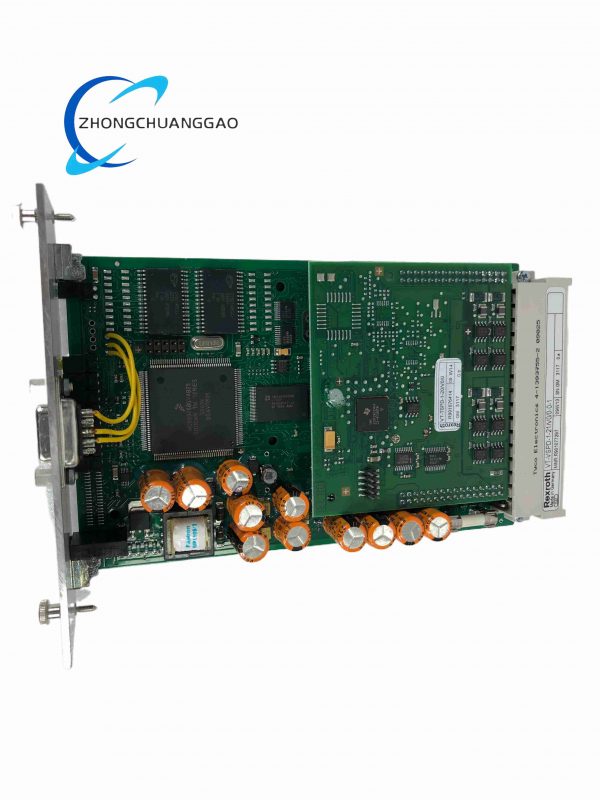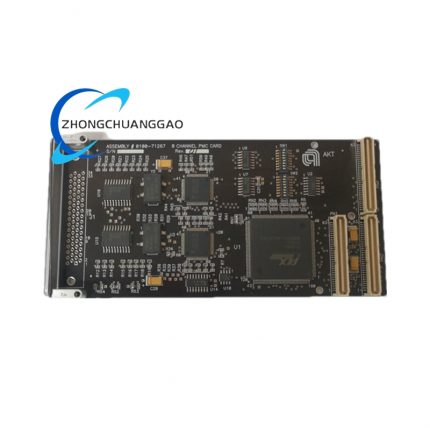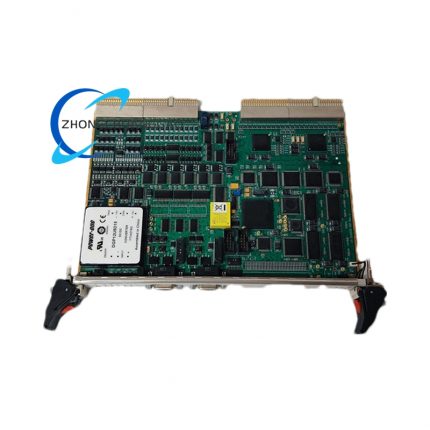
Maestro MAESTRO60X714

Product Name​
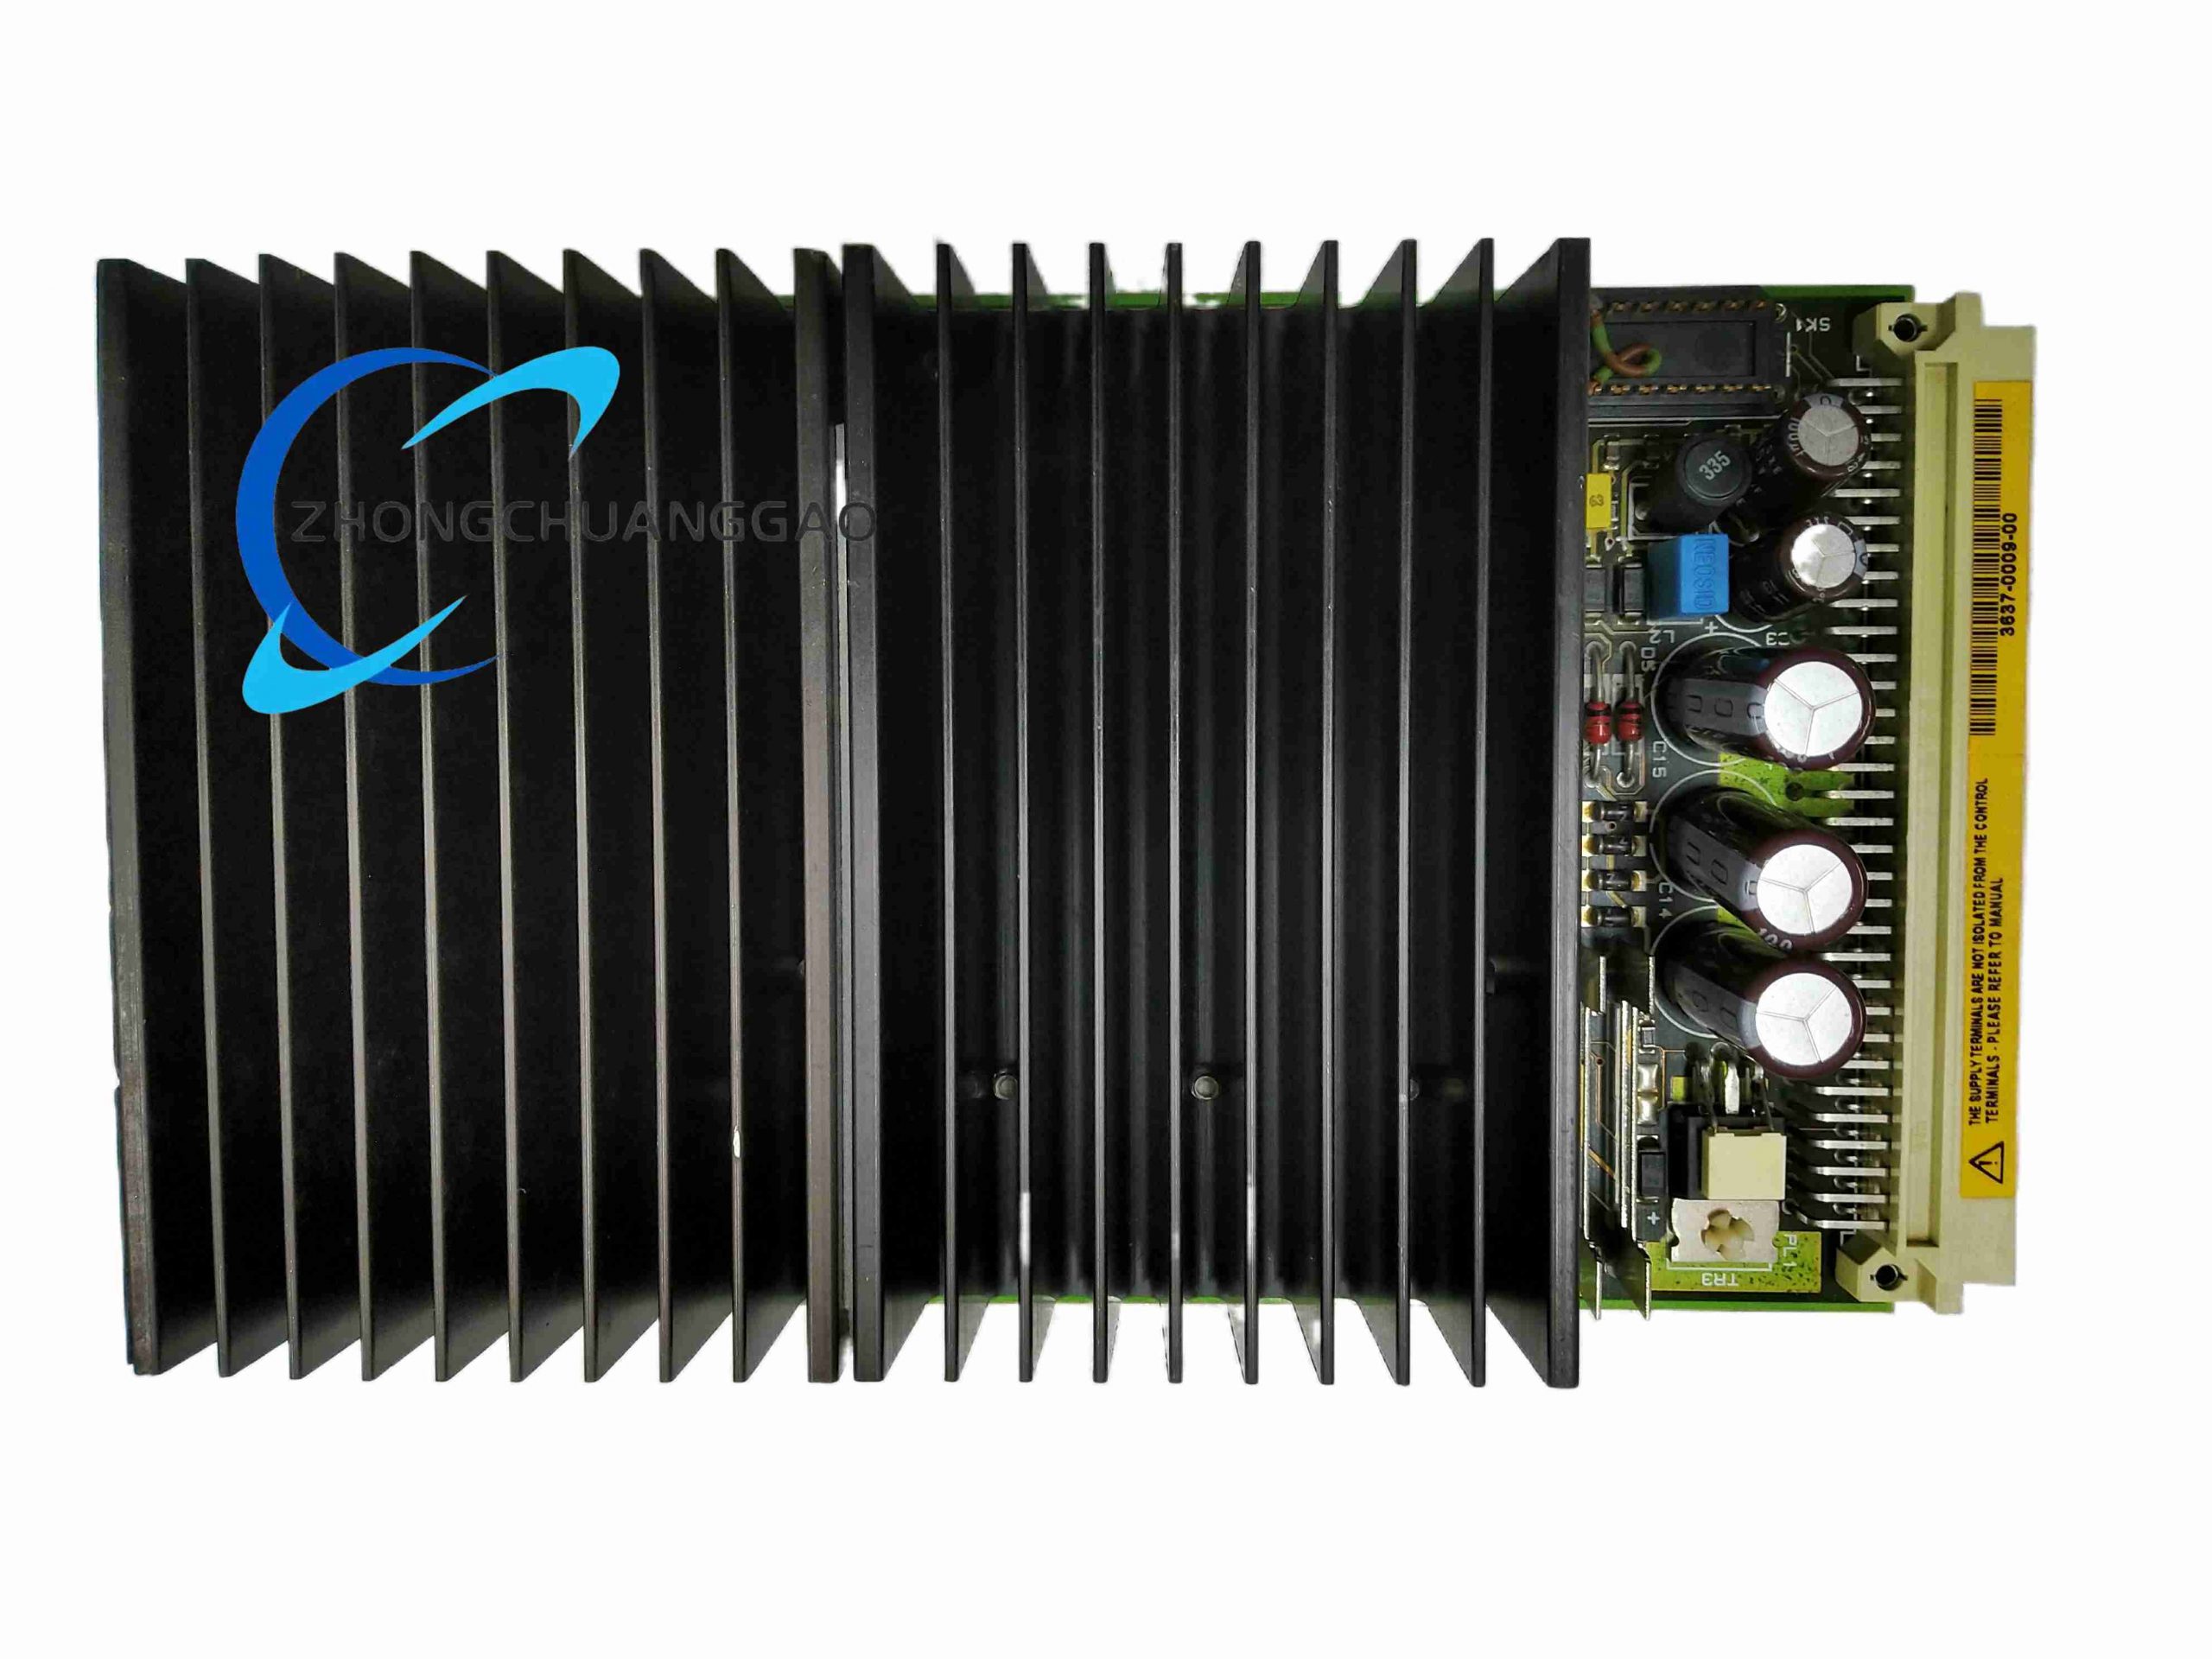
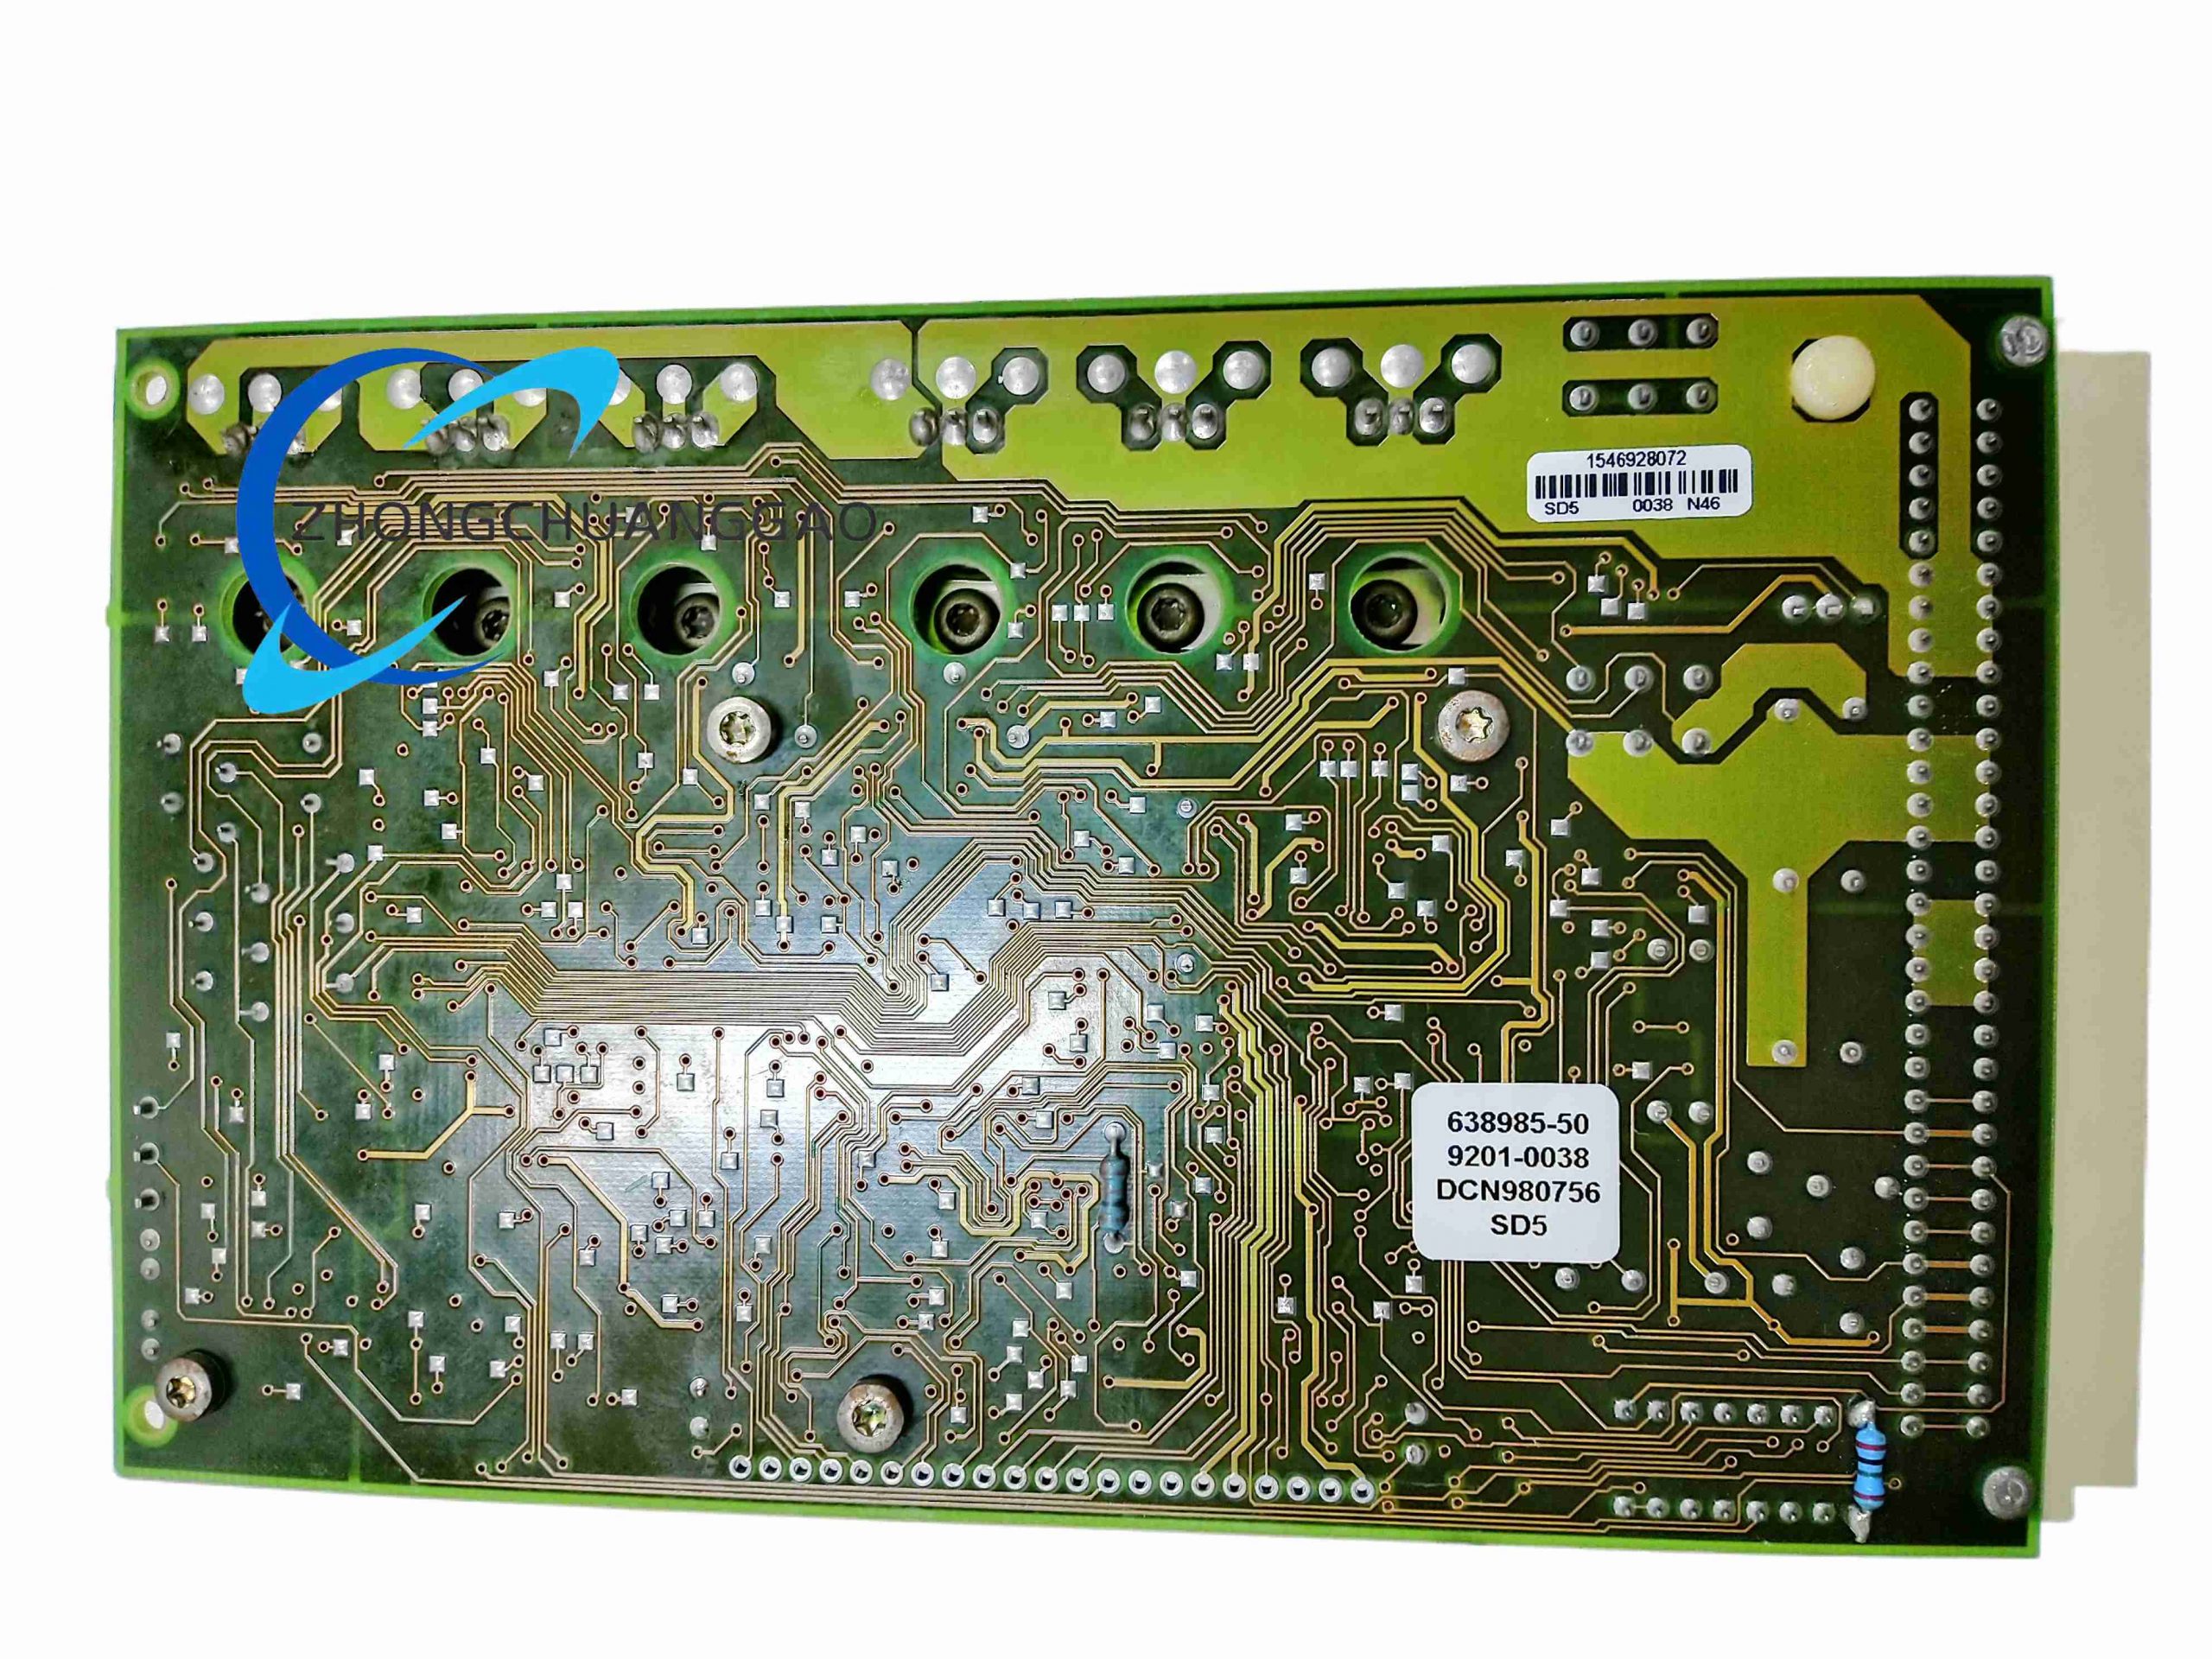
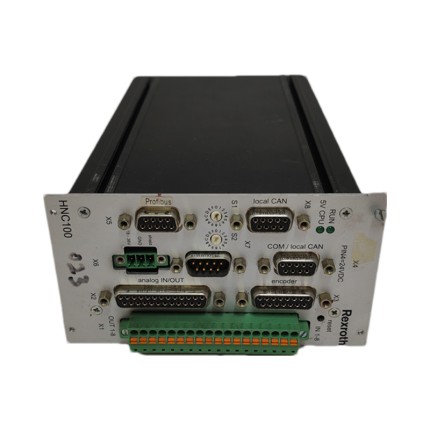
MINI MAESTRO 60X714 DC Servo Drive
Product Introduction​
The MAESTRO 60X714 is a compact industrial DC servo drive engineered for brushed or brushless permanent magnet motors in precision motion systems. It delivers closed-loop speed, torque and position regulation through PWM power stage technology and accepts analog, pulse or tachogenerator feedback references.
Category:
Description
Technical Specifications​
  • DC bus voltage: 24 VDC to 72 VDC nominal 60 VDC class
  • Continuous output current: 7 A
  • Peak output current: 14 A for 2 seconds
  • Control reference: ±10 V analog, PWM/direction or encoder closed loop
  • Feedback support: tachogenerator, armature voltage, encoder, resolver applicable configurations
  • PWM switching frequency: approximately 20 kHz
  • Protection class: panel mount aluminum housing with integrated heatsink
  • Operating temperature: -10°C to +45°C
  • Dimensions: 160 mm x 71 mm x 140 mm approximate
Functional Features​
  • Independent speed, torque and position control modes
  • I²t thermal motor protection against sustained overload
  • Overvoltage, undervoltage, overcurrent and short-circuit monitoring
  • High efficiency PWM stage with low audible noise
  • Configurable feedback selection for retrofit and new machinery
Application Scenarios​
  • Robotics joint and actuator control
  • Packaging machines and labeling systems
  • CNC axis retrofits and small machining stations
  • Medical automation and laboratory motion platforms
  • Conveyor indexing and precision feeding systems
Performance Parameters​
  • Current regulation accuracy suitable for low-inertia servo loops
  • 7 A continuous power delivery with 14 A acceleration reserve
  • Sub-millisecond response in tuned analog velocity loops
  • Stable standby and enable logic for safety integration
Material And Construction​
  • Aluminum extruded housing for heat dissipation
  • Printed circuit board with conformal coating options for industrial environments
  • Screw terminals and panel mounting brackets
  • Integrated heatsink fins for natural convection cooling
Working Principle​
The drive rectifies and filters the DC bus, then switches MOSFET or IGBT bridges at fixed PWM frequency to regulate motor armature voltage and current. Feedback signals are compared with the command reference; the error is processed by proportional-integral current and velocity loops to adjust duty cycle. Tachogenerator or encoder signals provide actual speed, while armature sensing provides backup commutation data.
Installation Requirements​
  • Mount on flat panel or DIN arrangement with free air clearance above and below the heatsink
  • Use insulated copper cabling sized for 14 A peak with separate signal shielding
  • Connect motor armature, tachometer and encoder grounds to designated terminals only
  • Provide DC supply with reverse polarity protection and proper fusing
Usage Precautions​
  • Verify bus voltage before power-up and never exceed 72 VDC
  • Do not operate without heatsink contact or in ambient above 45°C
  • Isolate control signals from high-power wiring to prevent feedback noise
  • Perform I²t and current limit setting according to motor nameplate
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “Maestro MAESTRO60X714”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.