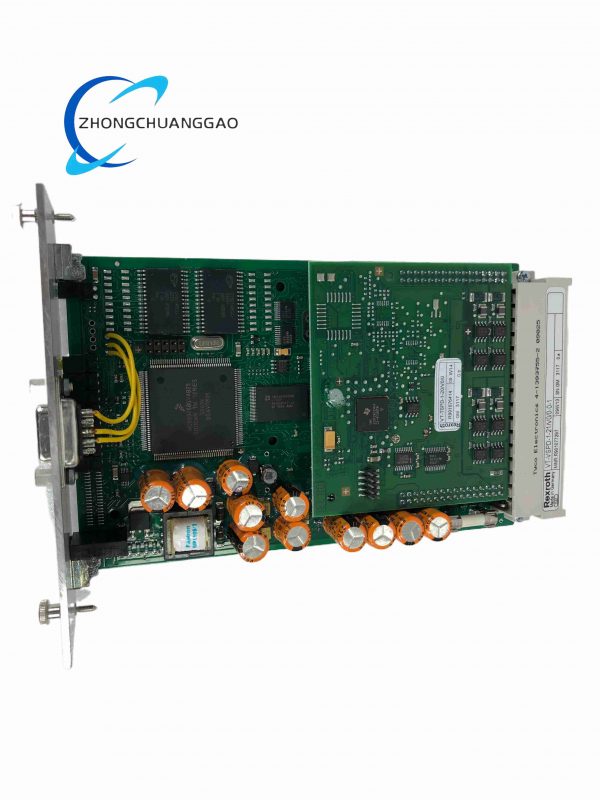
ELAU MAX-41103128991100

Product Name​
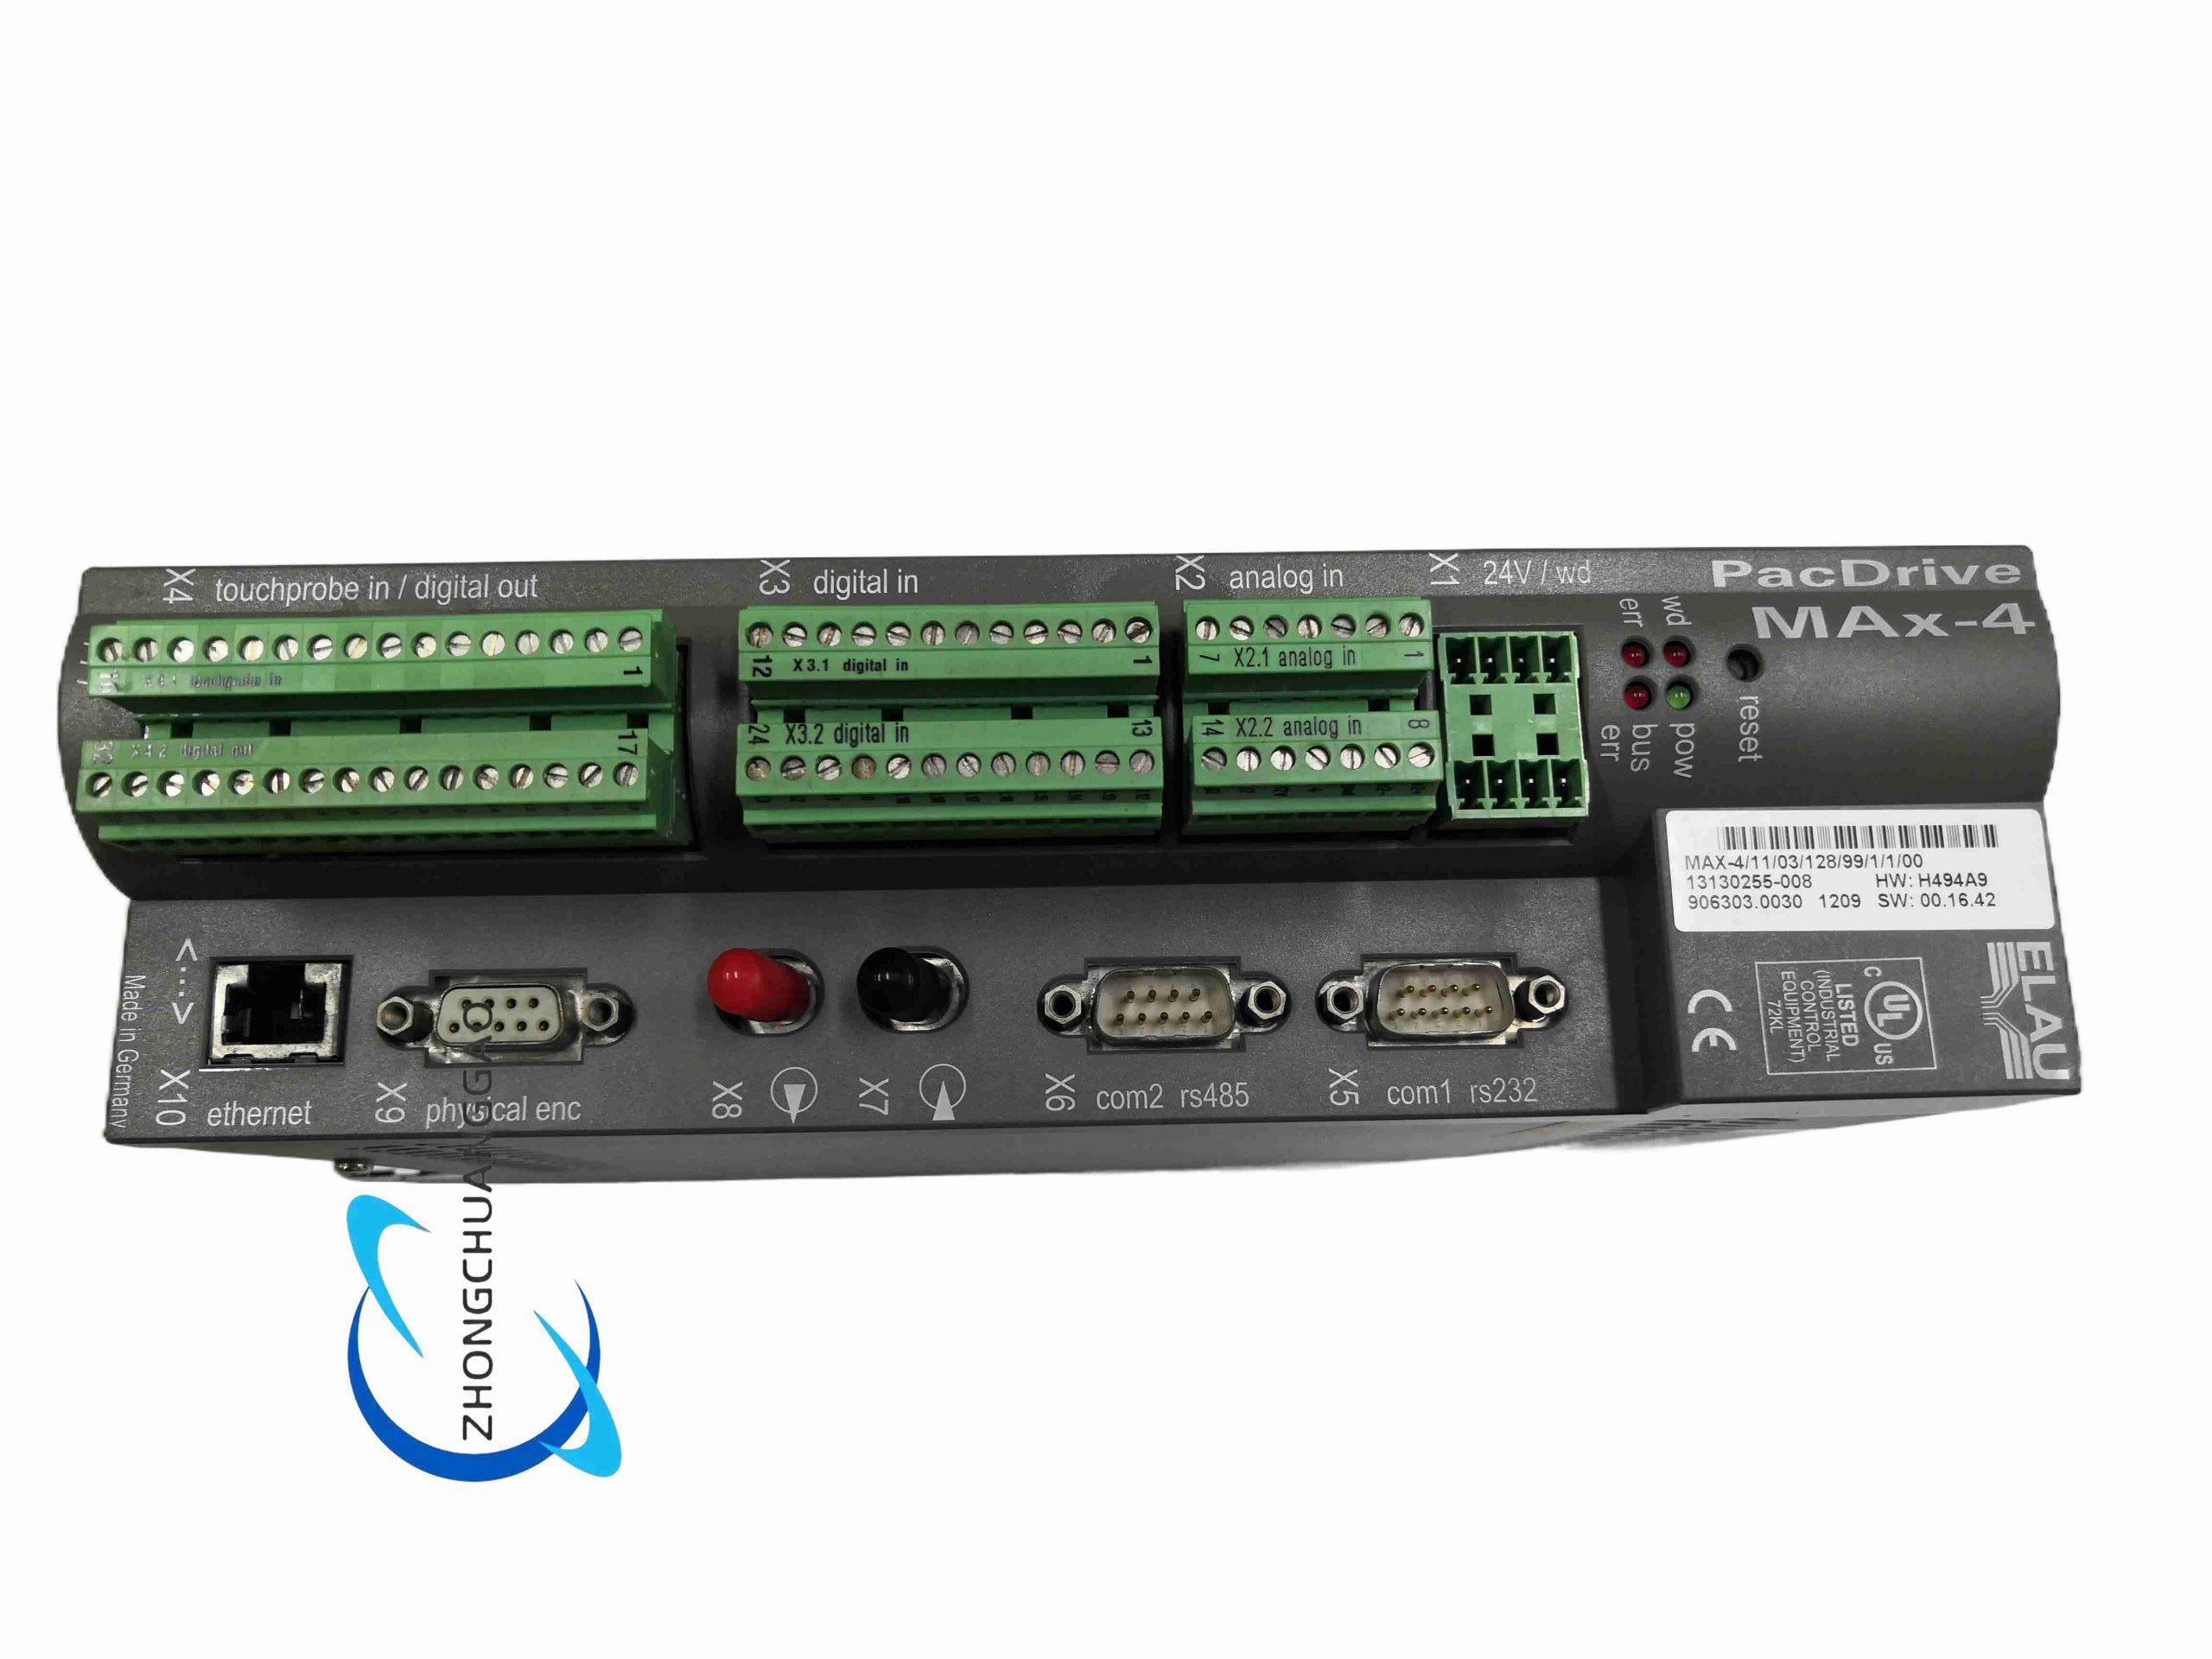
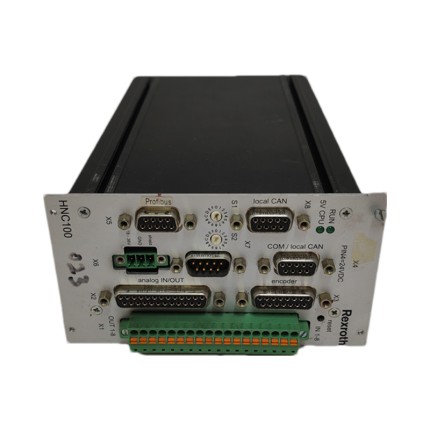
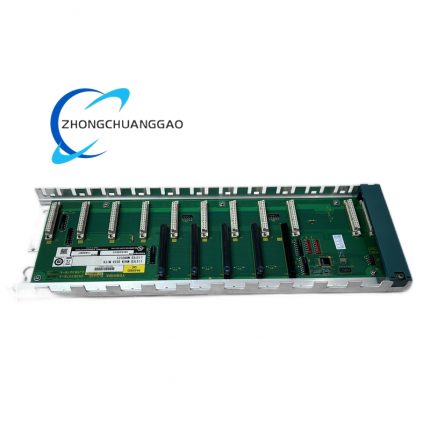
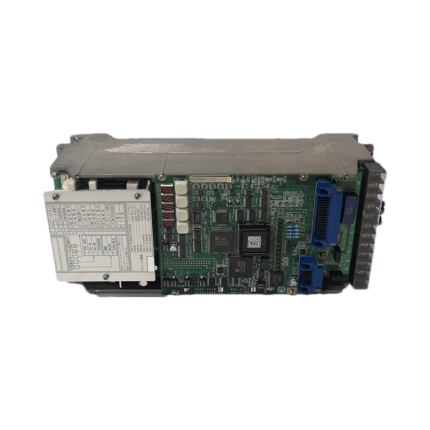
ELAU MAX-4 11A 128MB Integrated Servo Drive and Motion Controller
Product Introduction​
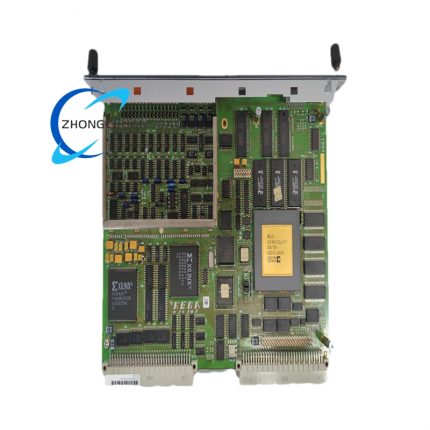
The MAX-4 controller identified by 41103128991100 belongs to the ELAU PacDrive MAX-4 family and combines a 3-phase servo amplifier with an IEC 61131-3 motion controller in one cabinet unit. It executes camming, gearing, interpolation and high-speed axis synchronization for packaging and manufacturing machines.
Category:
Description
Technical Specifications​
  • Series: ELAU MAX-4
  • Decoded configuration: 400 V class, 11 A continuous, 128 MB memory, structured option set
  • Input voltage: 3-phase 400 VAC nominal
  • Continuous output current: 11 A
  • User memory: 128 MB program and recipe storage
  • Feedback interfaces: resolver, incremental encoder, optional absolute encoder
  • Communication: CANopen and Ethernet based interfaces, SERCOS capable configurations
  • Programming: IEC 61131-3 with ELAU EPAS-4 environment
  • Safety: enable and inhibit digital inputs, safe-stop capable design
  • Operating temperature: 0°C to 55°C drive dependent, 0°C to 40°C in high-load enclosures
  • Protection: IP20 cabinet installation
Functional Features​
  • Integrated PLC and servo amplification reduces separate controller hardware
  • Electronic cam, electronic gear and multi-axis interpolation
  • Deterministic motion tasks with real-time operating system
  • Centralized parameter management for motors, feedback and bus nodes
  • Diagnostic LEDs and fault reporting for overcurrent, overheating and encoder loss
Application Scenarios​
  • Flow wrapping, cartoning and case packing machines
  • Filling, capping and rotary indexing systems
  • Labeling and printing web control
  • Pharmaceutical solid-dose and sterile packaging lines
  • High-speed handling and robotic feeding systems
Performance Parameters​
  • 11 A continuous current supports medium inertial servo axes
  • 128 MB memory stores motion programs, recipes and audit data
  • Millisecond task cycles maintain synchronized multi-axis profiles
  • Resolver or encoder feedback provides accurate speed and position loops
Material And Construction​
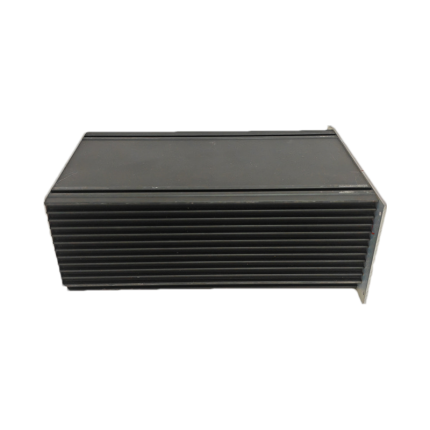
  • Sheet metal and aluminum drive enclosure
  • Insulated PCB assemblies with industrial-grade components
  • Panel mounting brackets and cabinet fixing points
  • Ventilation openings or fan assistance according to load profile
Working Principle​
The unit receives 3-phase mains and converts it to regulated DC, then generates PWM output for the servo motor. The internal controller runs IEC 61131-3 tasks and motion algorithms, comparing feedback position with target trajectory. Output current, voltage and frequency are modulated to follow cam, gear or interpolated profiles while safety inputs monitor enable conditions.
Installation Requirements​
  • Install inside IP54 or higher cabinet with adequate airflow
  • Use 3-phase 400 VAC supply with proper grounding and mains filtering
  • Connect motor power, brake and feedback with shielded cables separated from control bus
  • Bond ELAU SH or SB servo motors according to drive rating
  • Configure EPAS-4 project before initial commissioning
Usage Precautions​
  • Do not exceed 11 A continuous per axis without derating
  • Verify encoder resolution and motor parameters before autotuning
  • Keep firmware, boot project and amplifier settings matched
  • Disable output before any motor or brake maintenance
  • Protect communication ports from static discharge and incorrect cabling
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “ELAU MAX-41103128991100”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.