Electrocraft MAX250DCMB209103-0110

Product Name​
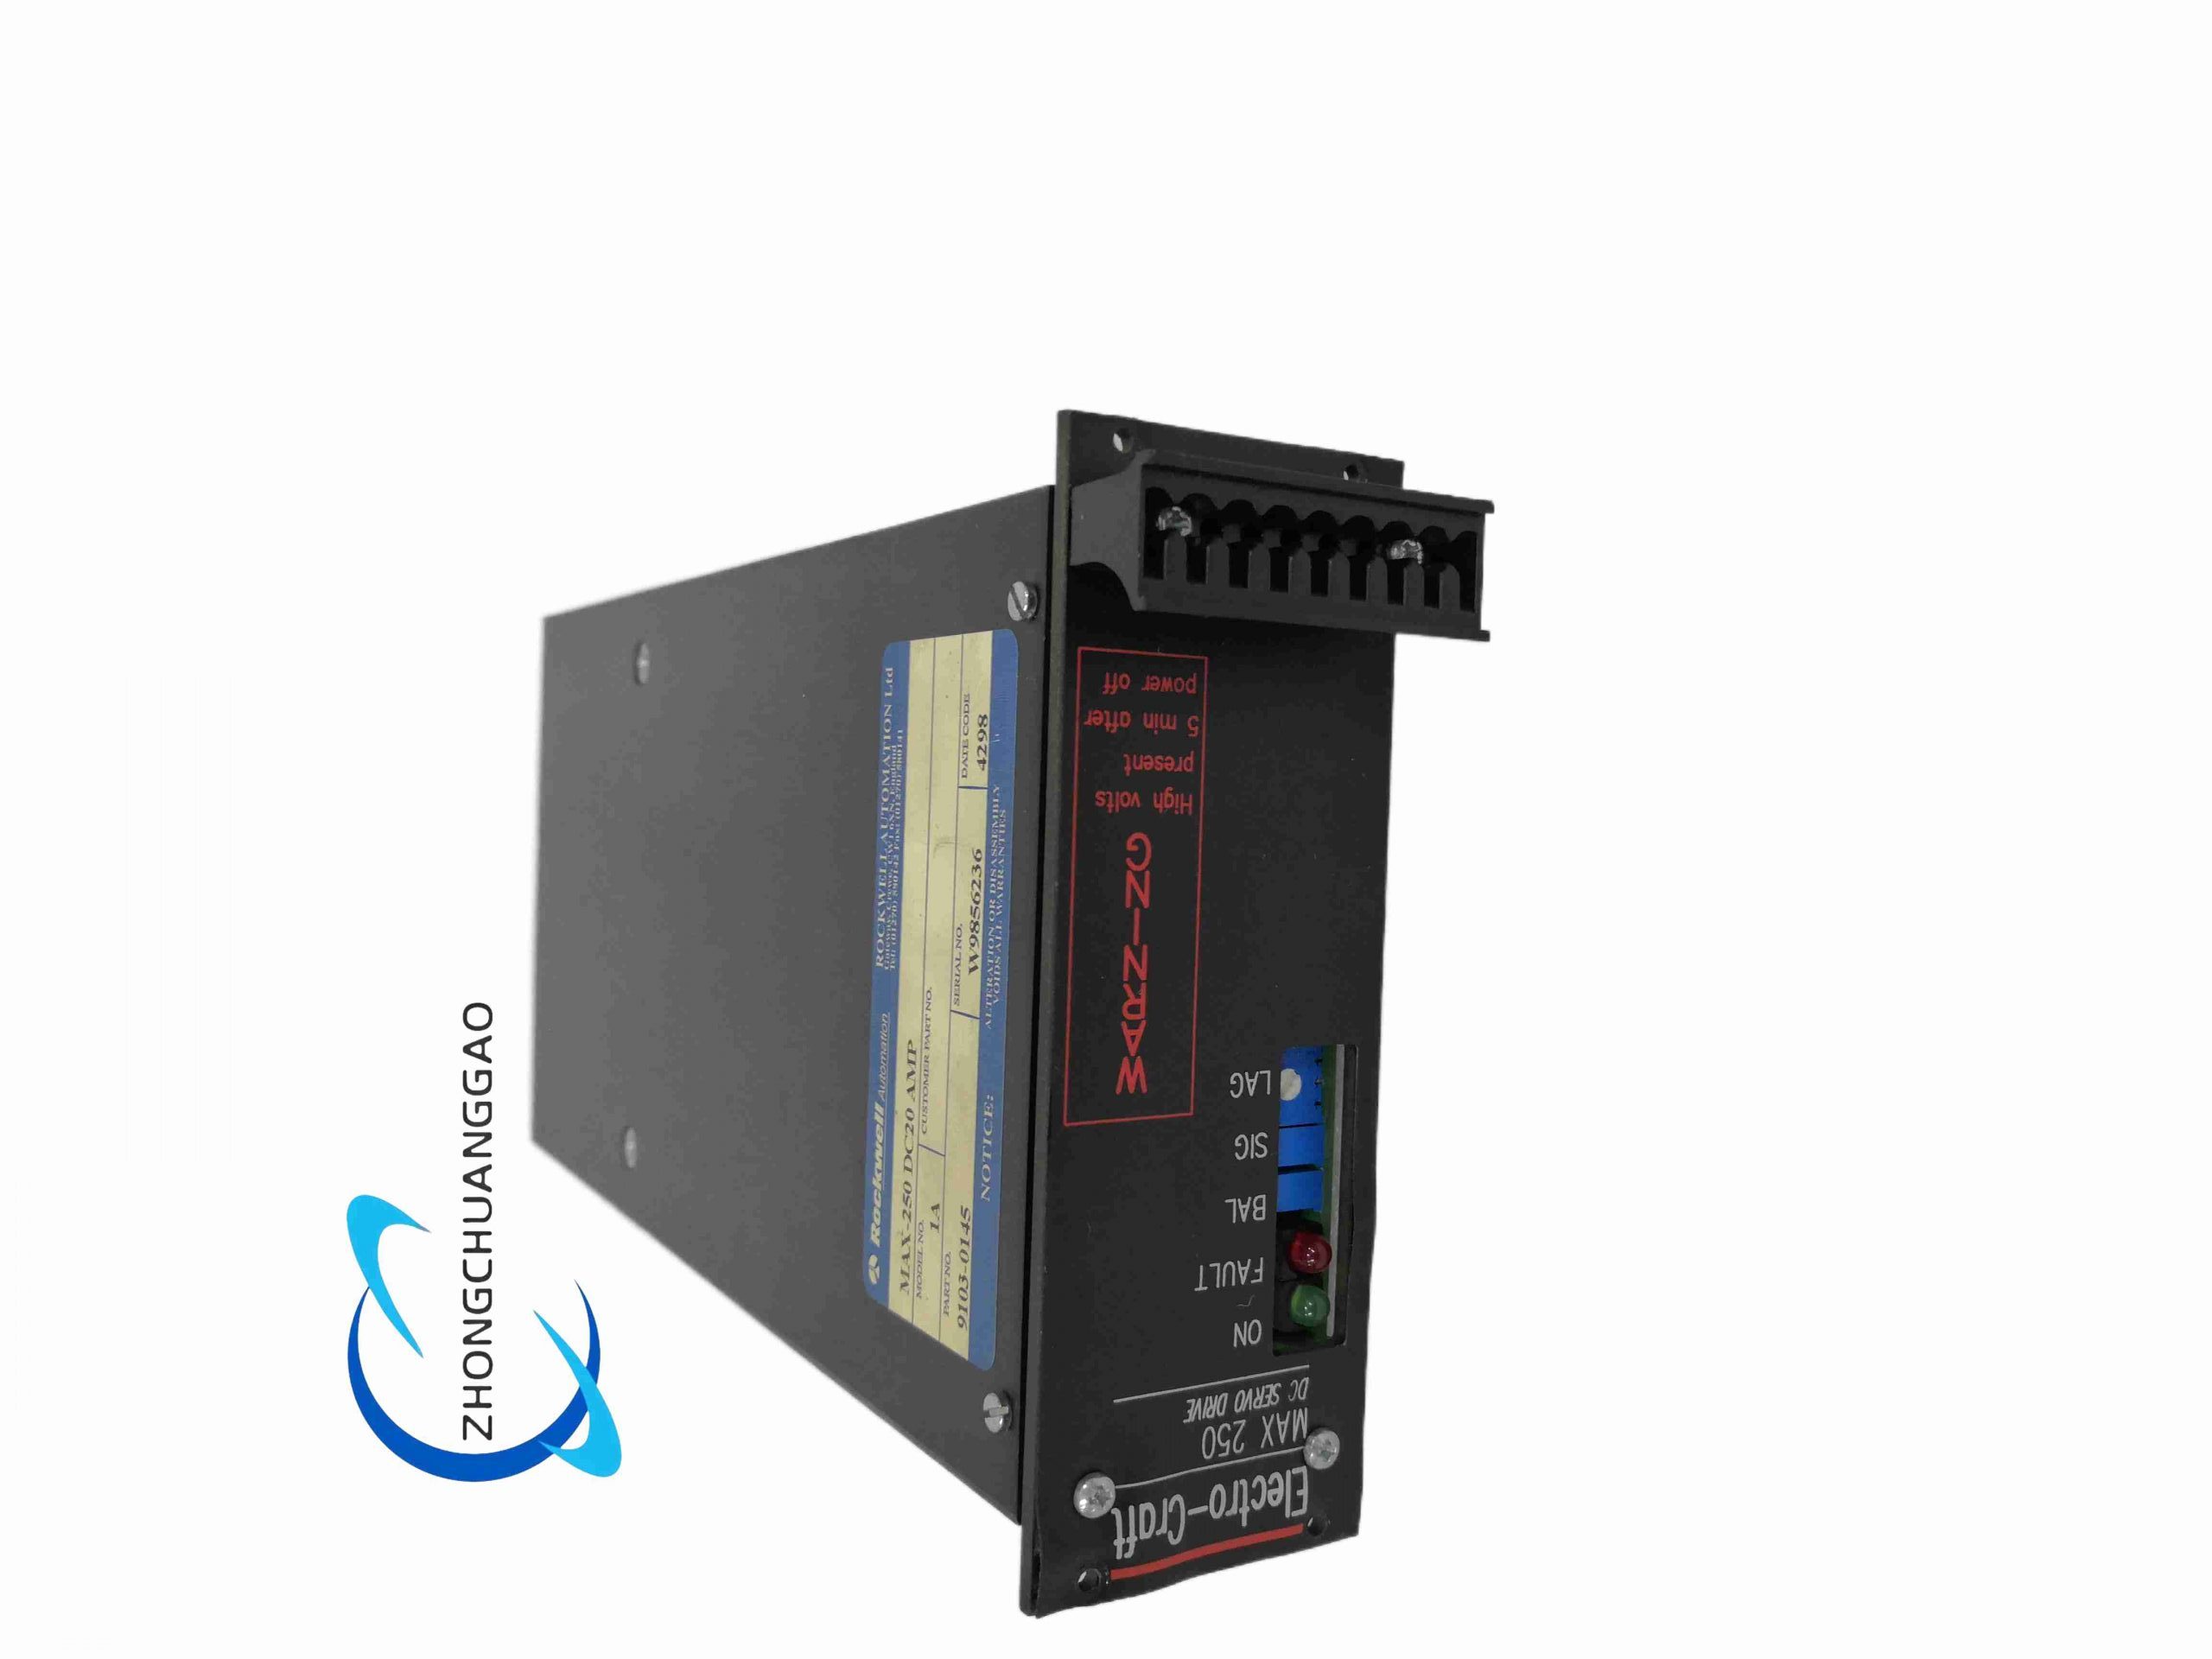
ElectroCraft MAX250DC MB209103-0110 Industrial DC Motor
Product Introduction​
The MAX250DC unit with code MB209103-0110 is a high-performance industrial DC motor designed for automation, robotics and machinery requiring controllable speed and torque. It operates with compatible DC drives and provides continuous output for dynamic acceleration loads.
Category:
Description
Technical Specifications​
  • Model: MAX250DCMB209103-0110
  • Motor type: industrial DC motor, servo capable configuration
  • Voltage range: 24 VDC to 80 VDC
  • Continuous current: 9.7 A
  • Peak current: 30 A
  • Rated power: 550 W
  • Rated speed: 2500 RPM
  • Rated torque: 1.8 Nm
  • Cooling: natural convection or forced air according to enclosure
  • Mounting: standard flange with shaft coupling interface
Functional Features​
  • Wide 24 VDC to 80 VDC operating range for flexible battery or supply design
  • High peak current capacity for rapid acceleration and load impact
  • Constant torque output across adjusted speed band with proper controller
  • Compact frame suitable for space-limited automation equipment
  • Compatible with ElectroCraft and third-party DC servo drives
Application Scenarios​
  • Robotic joints and mobile robotic drivetrains
  • Conveyor and material handling actuators
  • Printing, converting and labeling machinery
  • Medical device positioning systems
  • Industrial automation fixtures and rotary tables
Performance Parameters​
  • 550 W rated power supports continuous motion duties
  • 1.8 Nm torque enables direct drive of small-to-medium loads
  • 2500 RPM base speed accommodates gearing or direct coupling
  • 30 A peak current provides startup and intermittent overload margin
Material And Construction​
  • Laminated steel stator and commutator assembly
  • Machined shaft with keyway or coupling preparation
  • Aluminum or steel housing for thermal conduction
  • Sealed bearing system according to environmental specification
  • Terminal box or connector outlet for power and tachometer feedback
Working Principle​
DC voltage applied to the armature produces magnetic interaction with the permanent magnet or wound field stator. Commutator and brushes route current to successive armature windings, creating continuous rotation. Speed is proportional to armature voltage; torque is proportional to armature current. External DC drive regulates voltage and current to follow speed or torque commands.
Installation Requirements​
  • Mount on rigid flange or base with correct shaft alignment
  • Use cabling rated for 30 A peak with separate tachometer or encoder shielding
  • Provide DC supply with overcurrent protection sized to 9.7 A continuous
  • Ensure ventilation path around motor housing
  • Balance coupled loads to avoid vibration and bearing wear
Usage Precautions​
  • Operate only within 24 VDC to 80 VDC supply limits
  • Inspect brush wear periodically on brushed configurations
  • Avoid prolonged overload above 9.7 A continuous without duty evaluation
  • Keep commutator and terminals clean and dry
  • Confirm controller tuning before full-speed commissioning
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “Electrocraft MAX250DCMB209103-0110”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.