
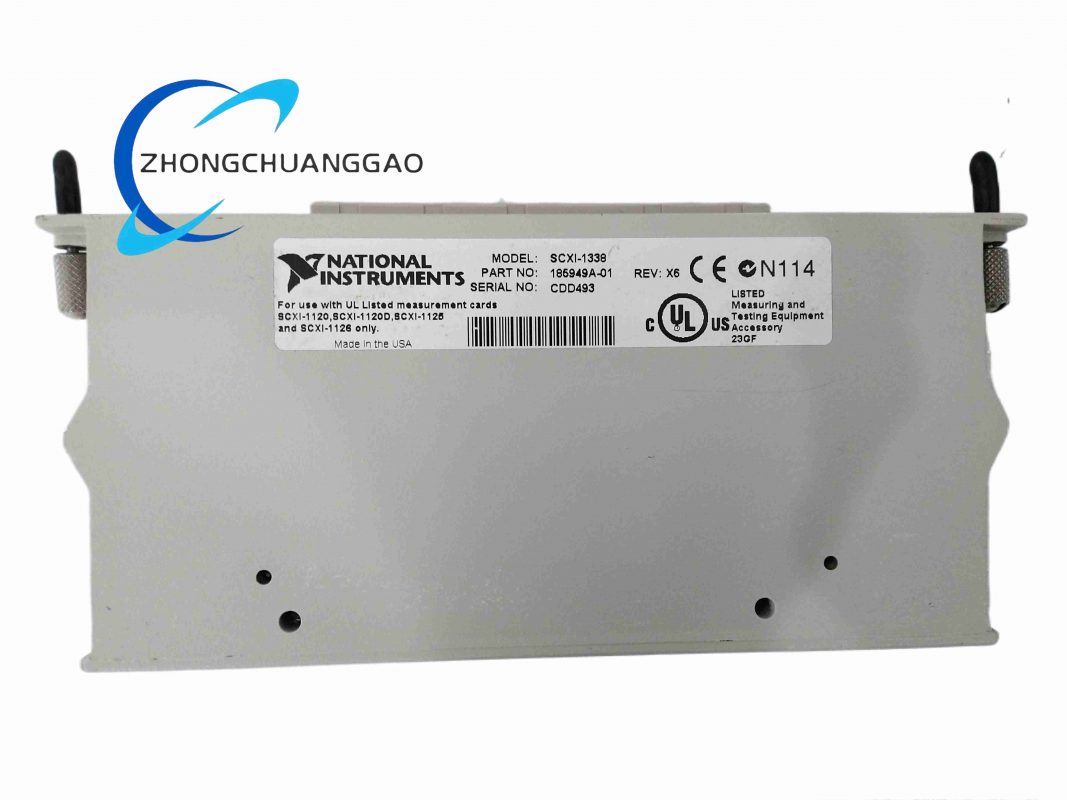
NI SCXI-1338
Product Name Current Input High-Voltage Terminal Block
Product Introduction The SCXI-1338 is a shielded current-input terminal block for SCXI analog input modules. It integrates precision current-sense resistors to convert 0–20 mA and 4–20 mA process current signals into voltage signals for measurement by compatible SCXI modules.
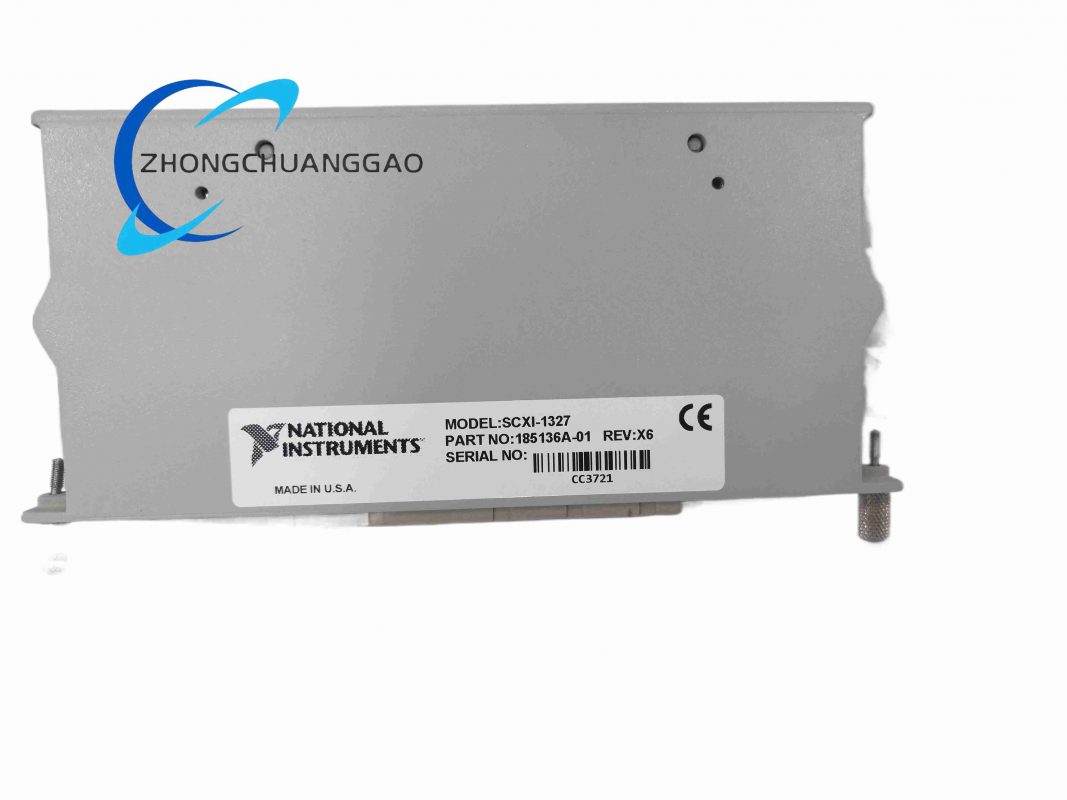
NI SCXI-1327
Product Name High-Voltage Attenuator Terminal Block
Product Introduction The SCXI-1327 is a shielded high-voltage attenuator terminal block for SCXI analog input modules. It integrates precision 100:1 resistive voltage dividers to extend the input voltage range of compatible modules up to 300 Vrms or ±300 VDC.
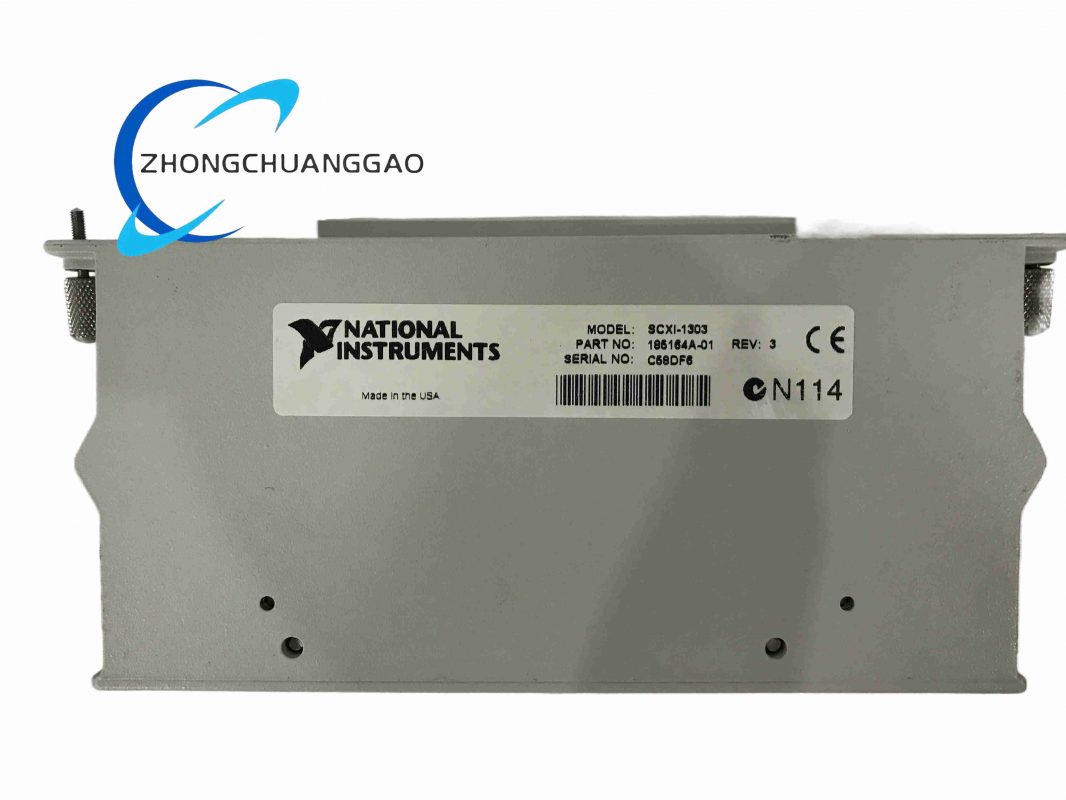
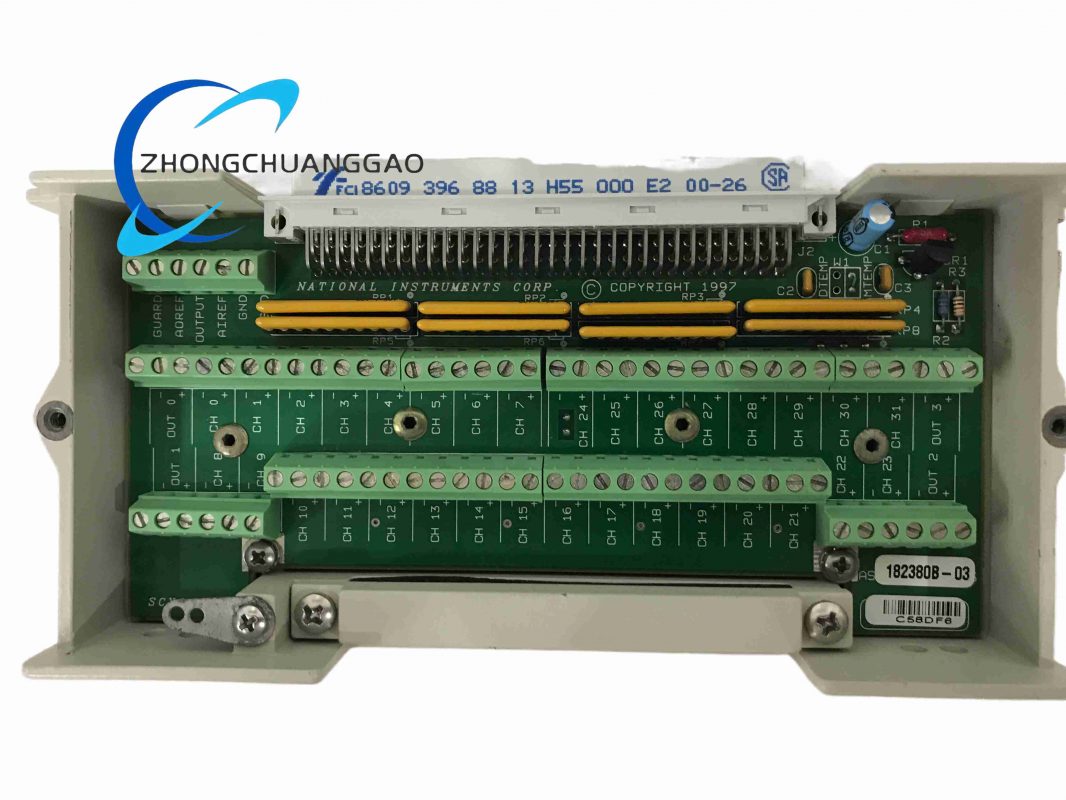
NI SCXI-1303
Product Name 32-Channel Isothermal Thermocouple Terminal Block
Product Introduction The SCXI-1303 is a high-accuracy isothermal terminal block designed for thermocouple measurement applications with SCXI-1100 and SCXI-1102/B/C modules. It features isothermal construction and integrated cold-junction sensing to minimize temperature measurement errors.
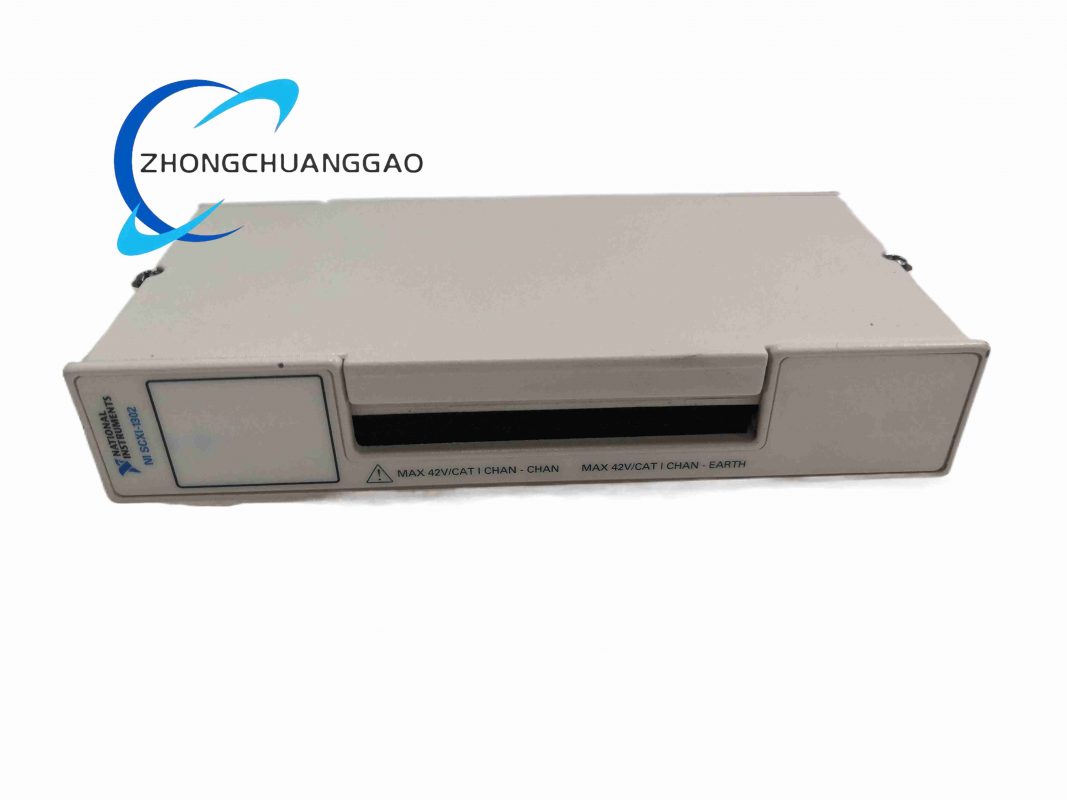
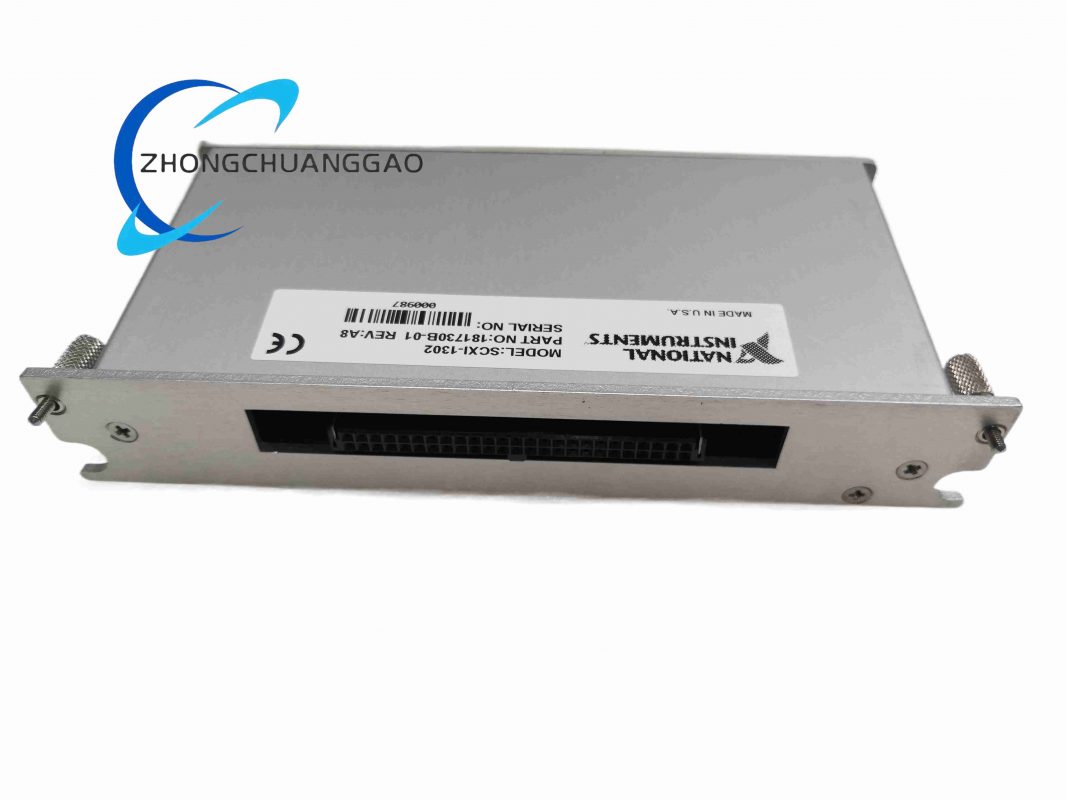
NI SCXI-1302
Product Name 50-Screw Signal Breakout Terminal Block
Product Introduction The SCXI-1302 is a front-mounting terminal block designed for use with SCXI-1180 feedthrough modules. It provides 50 screw terminals for signal breakout and routing, with built-in filtering and shielding for reliable signal transmission in DAQ systems.
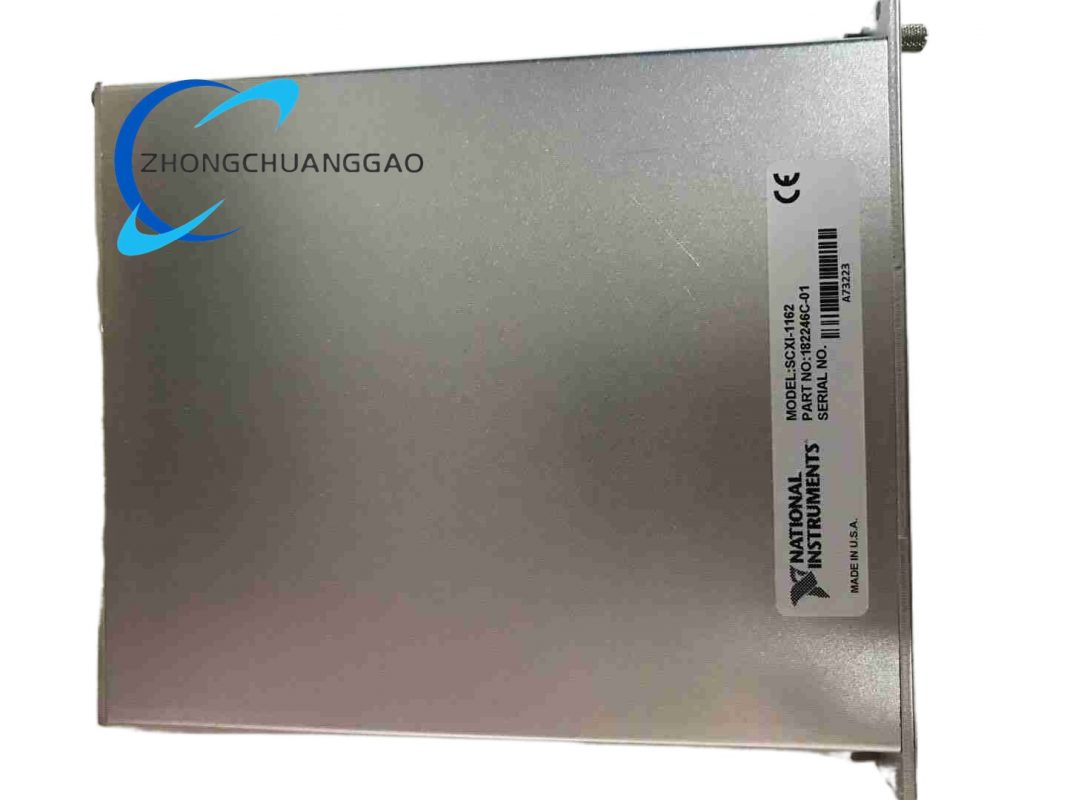
NI SCXI-1162
Product Name 32-Channel Optically Isolated Digital Input Module
Product Introduction The SCXI-1162 is a 32-channel optically isolated digital input module for SCXI signal conditioning systems. It provides electrical isolation between field signals and the control system, supporting TTL, CMOS and other common logic level signal acquisition.
NI SCXI-1130
Product Name 256-Channel Reed Relay Multiplexer/Matrix Switch Module
Product Introduction The SCXI-1130 is a high-density, multi-configuration reed relay switch module for SCXI systems. It supports multiple multiplexer and matrix topologies, providing flexible signal routing solutions for large-channel-count data acquisition and test systems.
NI SCXI-1125
Product Name 8-Channel High-Precision Isolated Analog Input Module
Product Introduction The SCXI-1125 is a high-performance isolated analog input module for precision voltage signal measurement. It provides 12 selectable gain settings, wide input range and channel-to-channel isolation, making it suitable for demanding industrial and test measurement applications.
NI SCXI-1102
Product Name 32-Channel Thermocouple/Voltage Input Module
Product Introduction The SCXI-1102 is a 32-channel differential analog input signal conditioning module designed for thermocouple, low-bandwidth voltage, millivolt and process current signal measurement. It integrates selectable gain amplifiers and low-pass filters, and supports cold-junction compensation for thermocouple applications.
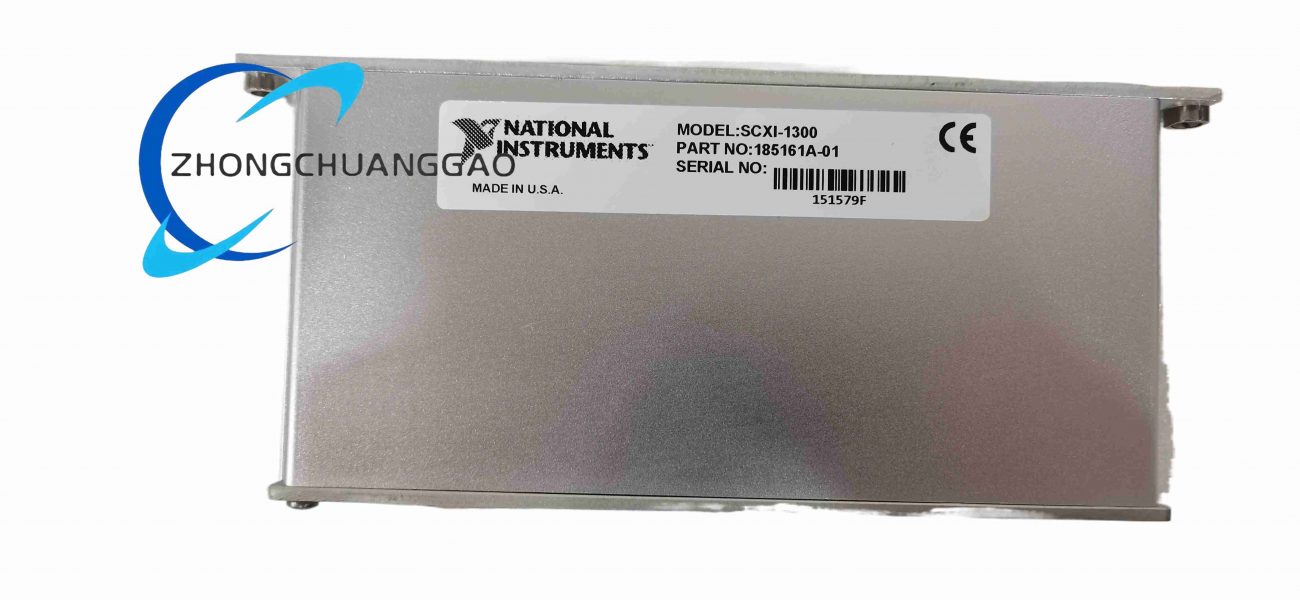
NI SCXI-1300
Product Name 32-Channel General-Purpose Terminal Block
Product Introduction The SCXI-1300 is a screw-type terminal block designed for 32-channel SCXI analog input modules. It provides reliable signal connection for differential input signals and integrates an onboard cold-junction temperature sensor to support thermocouple temperature measurement systems.
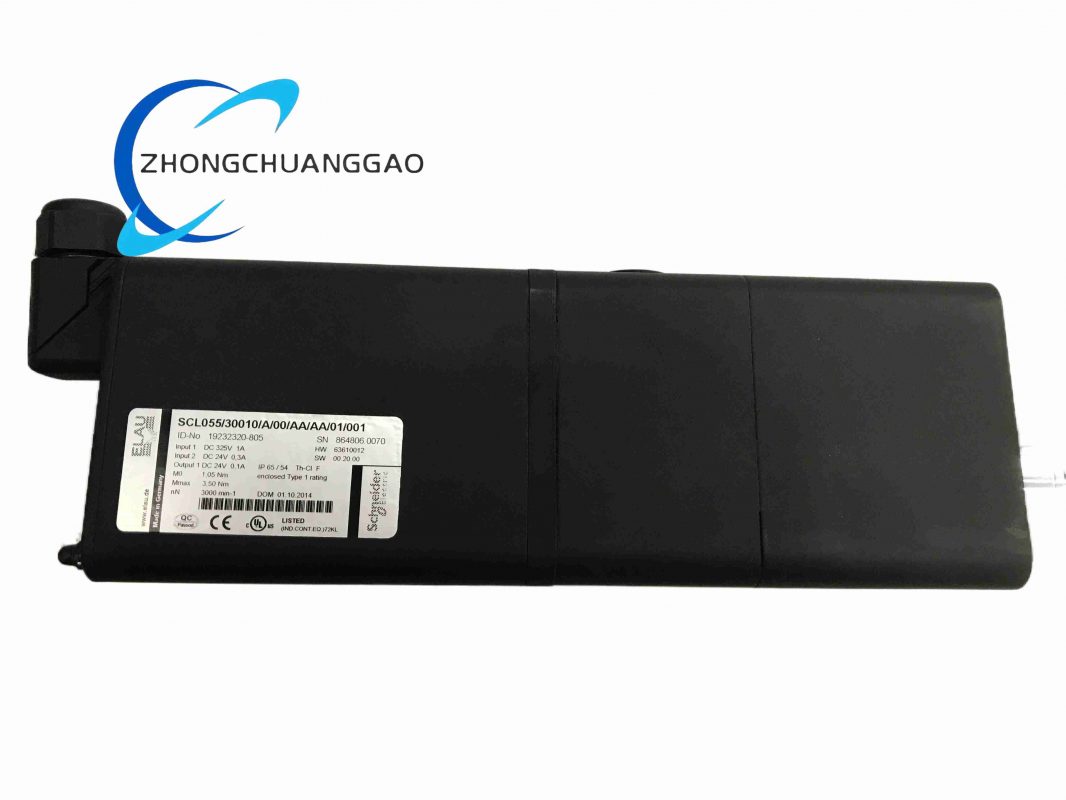
ELAU SCL055/30010/A/00/AA/AA/01/001
Product Name Servo Motor
Product Introduction This servo motor delivers high-speed and high-precision motion performance for industrial automation systems. It integrates advanced control algorithms and precision feedback systems to guarantee accurate motion execution with minimal deviation. The unit features a robust mechanical design and wide system compatibility, making it suitable for diverse industrial scenarios.
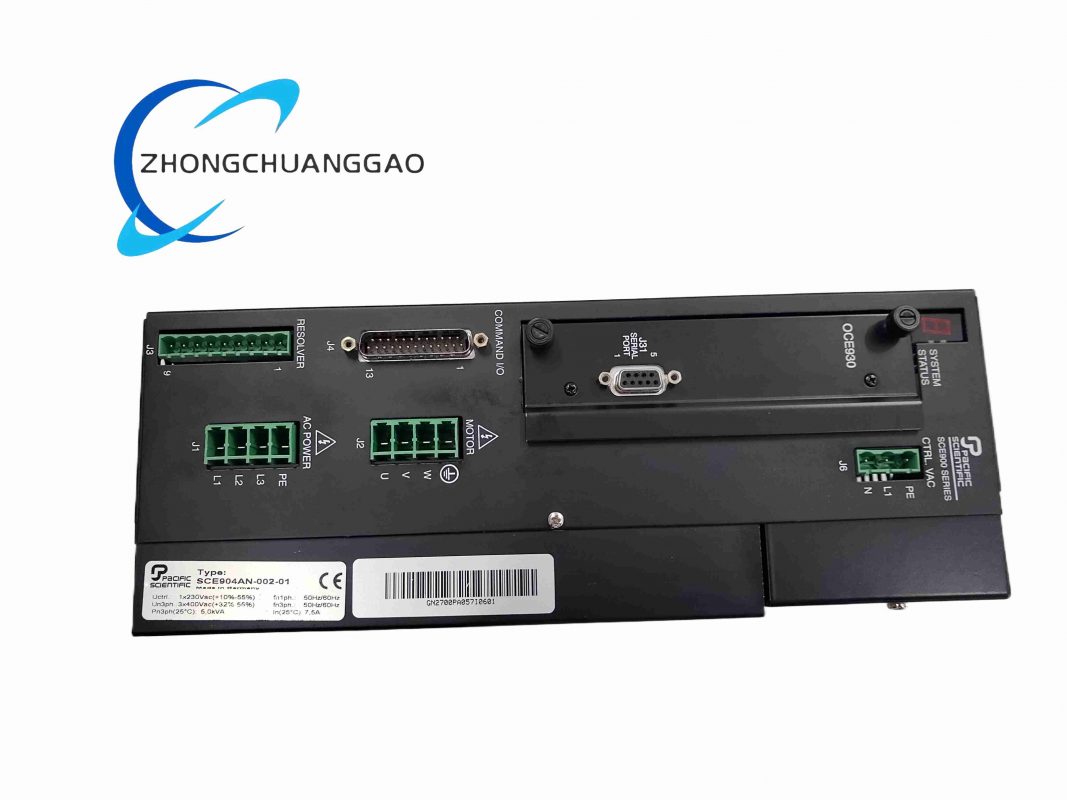
Pacific Scientific SCE904AN-002-01
Product Name SCE900 Series Single-Axis Digital Servo Drive
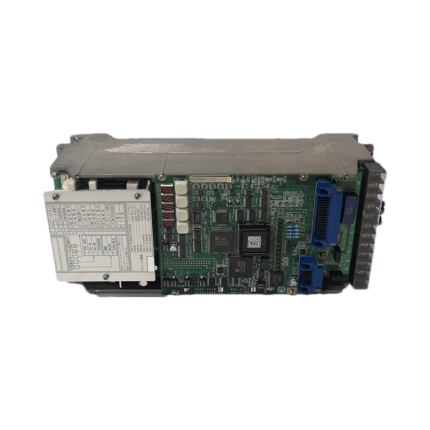
Product Description The SCE904AN-002-01 is an industrial-grade single-axis digital servo drive from Pacific Scientific’s SCE900 product line. It provides precise three-loop control for AC permanent magnet synchronous motors and brushless DC motors, with built-in protection features for reliable operation in demanding environments.
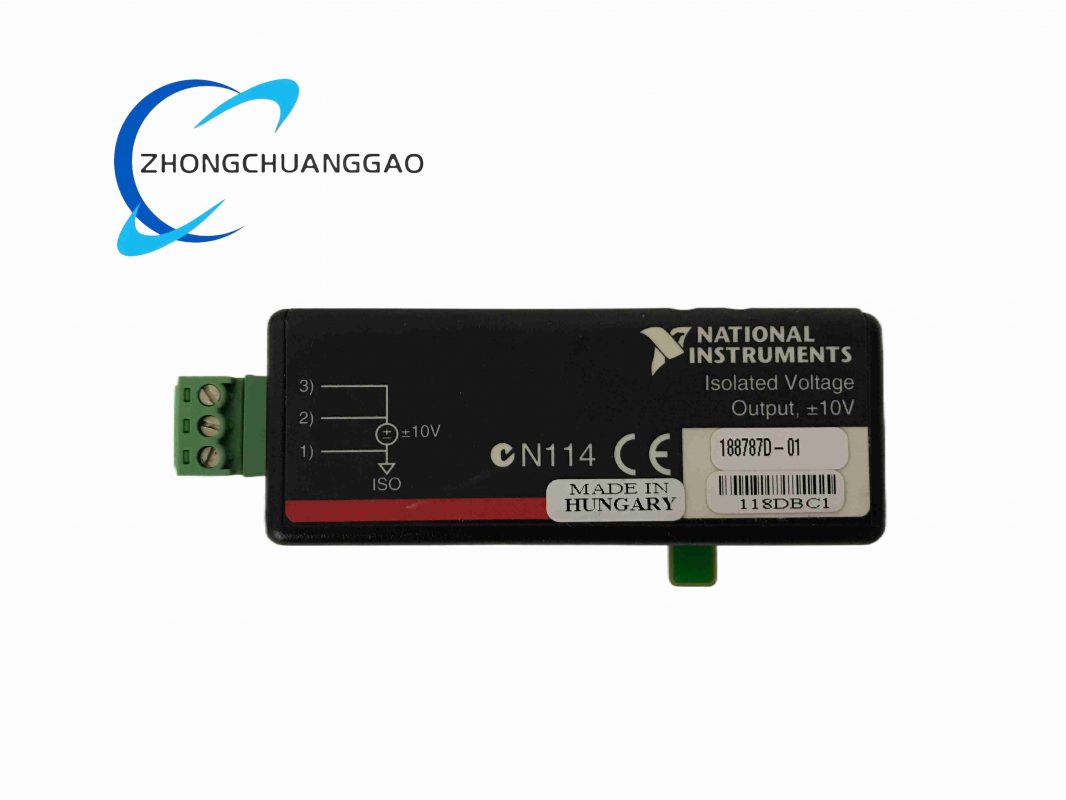
NI SCC-AO10
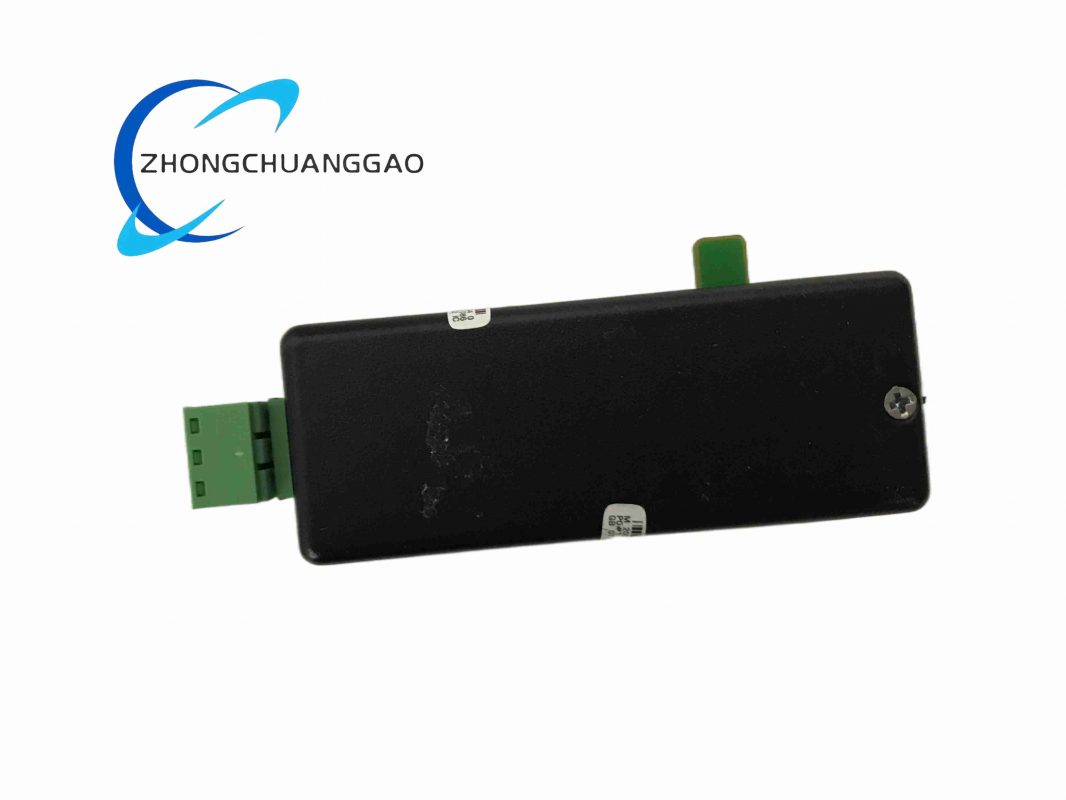
Product Name Isolated Analog Output Module
Product Description The SCC-AO10 is an isolated analog voltage output module from National Instruments’ SCC product family. It works with E/M Series DAQ devices to provide high-voltage, isolated analog output capability for test, measurement and control applications.


Reviews
There are no reviews yet.