Technical Specifications
- Independent Encoder Input Axis Count: 24 differential quadrature feedback channels
- Supported Encoder Signal Types: Differential A/B/Z quadrature line driver signals, digital index marker pulses
- Maximum Channel Input Frequency: 8 MHz per single encoder axis channel
- Host Compatibility: PMAC, PMAC-2, PMAC-3 motion control mainframe backplane expansion bus
- Logic Supply Voltage: 5 VDC sourced from PMAC mainframe internal backplane
- Operating Ambient Temperature: 0 °C to +60 °C control cabinet operating range
- Channel Isolation Standard: 1,500 VDC galvanic optocoupler isolation per axis
- Position Counter Resolution: 32-bit hardware quadrature accumulator for each of 24 axes
Functional Features
- 24 parallel independent hardware 32-bit position counters eliminating host CPU pulse counting overhead
- Configurable on-card DIP switch differential line termination resistance per encoder channel group
- Hardware index pulse latch circuit for fast automated axis home position referencing
- Per-group hardware loss-of-encoder-signal fault detection with front panel LED visual indication
- EMI suppression differential input circuits rejecting industrial high-frequency electrical noise
Performance Parameters
- Aggregate maximum quadrature edge processing throughput: 76 million edges per second
- Channel-to-channel signal skew matching: ≤ 50 ns propagation delay deviation
- Dielectric isolation withstand voltage per axis channel: 1,500 VDC continuous rating
- Automatic counter rollover without loss of absolute position tracking data
- Rated MTBF value: 575,000 operating hours at nominal +25 °C cabinet temperature
- Minimum index pulse capture width: 120 ns hardware trigger threshold
Material Composition
- Circuit board substrate: Industrial grade FR4 fiberglass reinforced laminate
- Signal isolation hardware: High-speed linear optocoupler integrated circuits
- Front panel wiring headers: Gold-plated multi-pin connector terminal blocks
- Configuration interface: Mechanical gold-contact DIP switch arrays
- Chassis mounting bracket: Electromagnetic shielding cold-rolled steel panel
Structural Characteristics
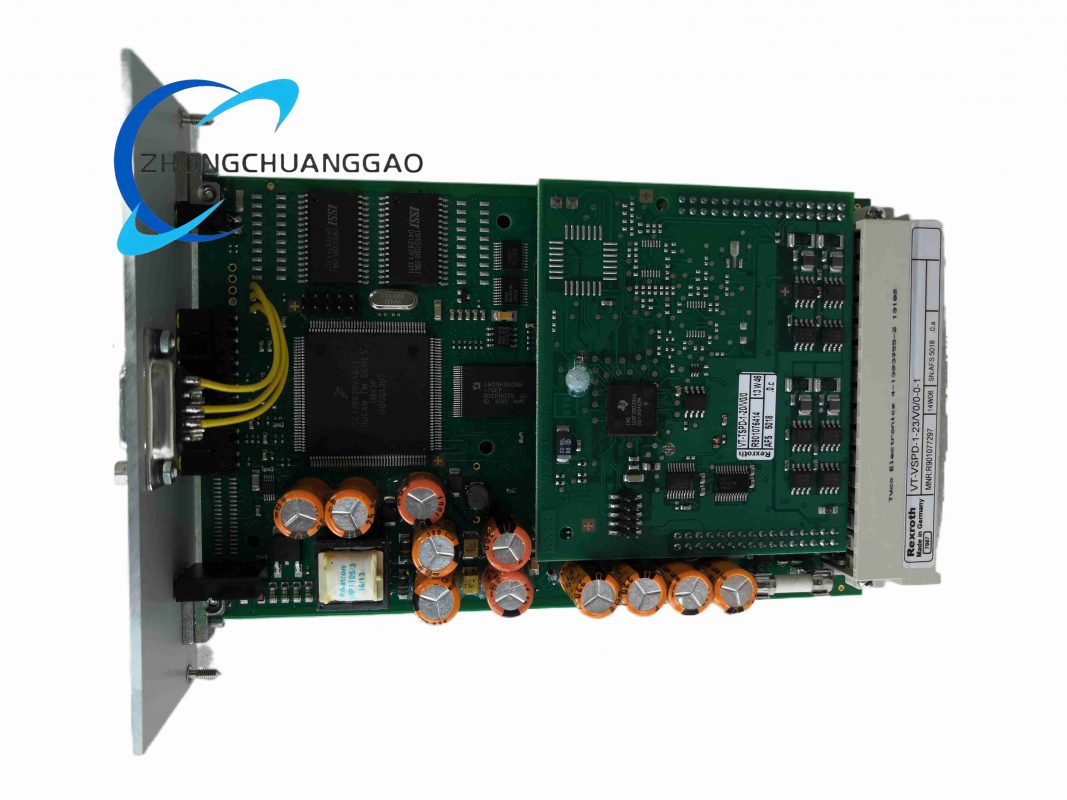
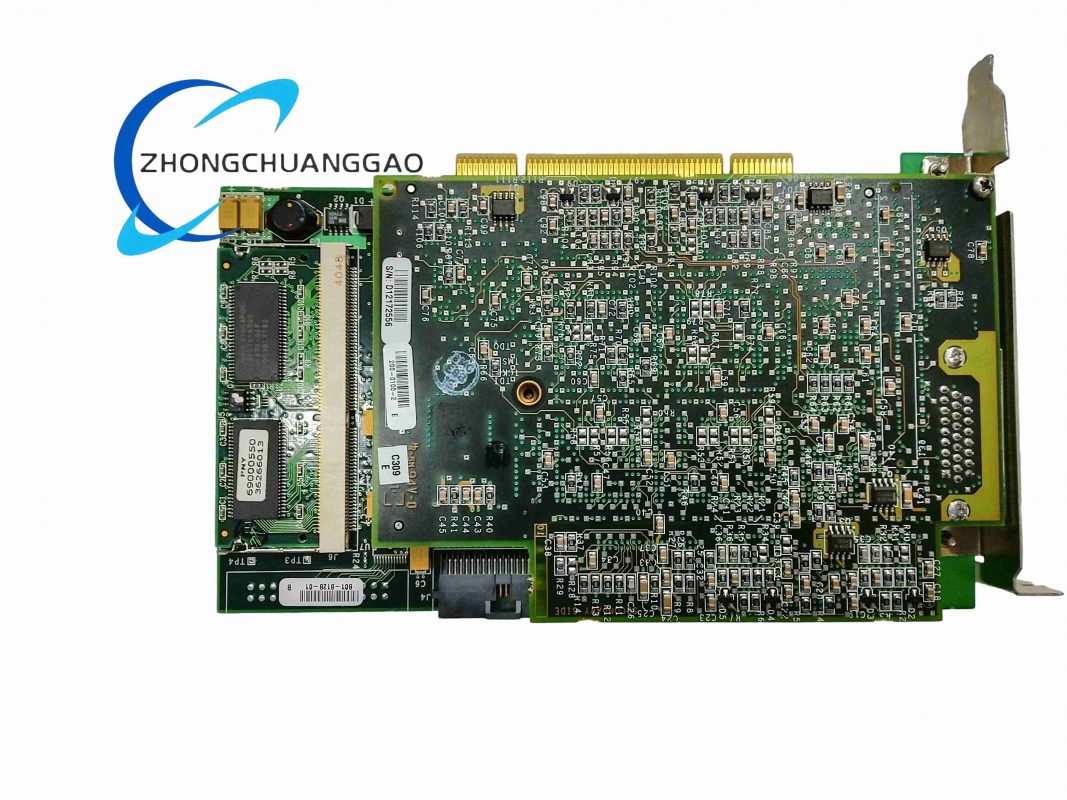
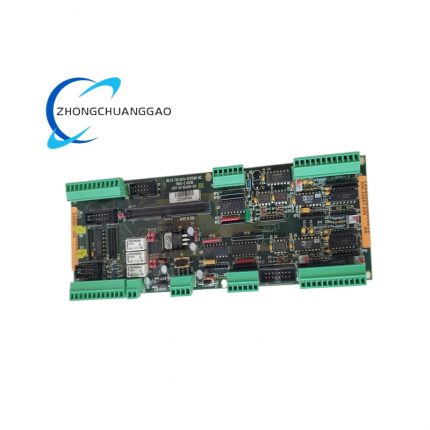
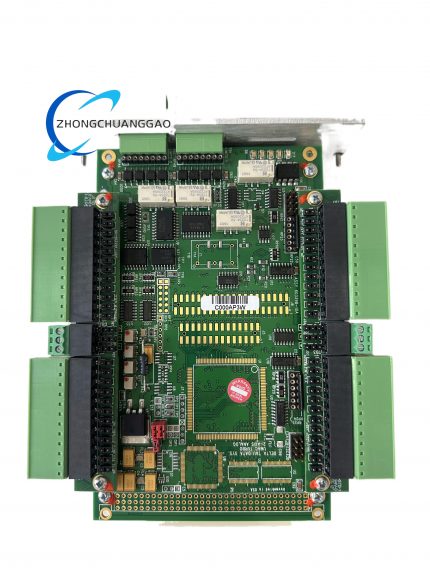
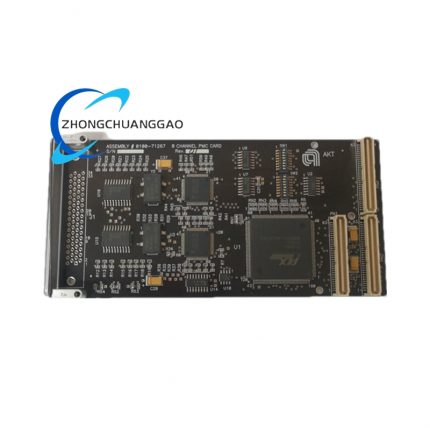
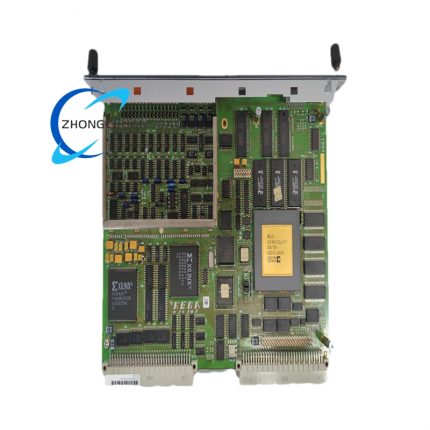
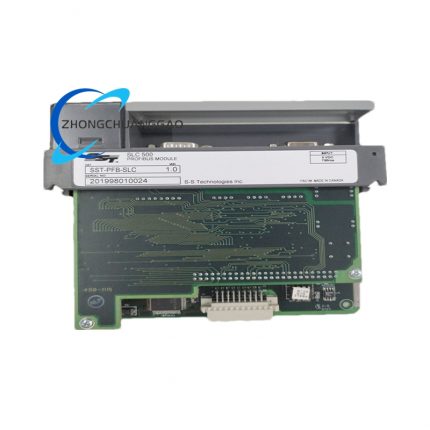
- Standard PMAC mainframe internal expansion card form factor
- Dual multi-pin front panel terminal header blocks segregated into three groups of 8 encoder axes each
- Front panel grouped LED status indicators for power, bus communication, and channel group signal faults
- Direct edge connector mating interface to PMAC series motion controller backplane expansion slots
- Segregated surface-mount signal conditioning circuits grouped per 8-axis channel banks
Working Principle
Differential quadrature position feedback signals from servo and stepper motor encoders enter grouped terminal headers on the card front panel. On-board optocoupler isolation circuits decouple encoder transducer electrical domains from PMAC control logic to block ground loop noise. Dedicated FPGA hardware logic processes A/B quadrature pulse edges to continuously update independent 32-bit position accumulators for all 24 axes simultaneously. Index Z pulse signals trigger hardware latch registers to capture exact axis home coordinates during calibration cycles. The PMAC mainframe motion processor retrieves all 24 axis position register datasets via the dedicated expansion backplane bus to execute closed-loop PID positioning control algorithms for large multi-axis automation machinery.
Core Advantages
- Industry-leading 24-axis encoder channel density minimizing total expansion card quantity for multi-axis systems
- Parallel hardware counting architecture eliminates motion control CPU pulse processing bottlenecks
- Grouped channel fault detection simplifies troubleshooting of large multi-encoder wiring harnesses
- Universal compatibility with all legacy and modern Delta Tau PMAC motion controller hardware platforms
- Integrated EMI filtering reduces requirement for external signal conditioning hardware
Applicable Industries
Large gantry automated machining systems, multi-spindle semiconductor manufacturing equipment, multi-axis automated packaging robotics, aerospace composite material layup machinery, multi-station automated test rigs for automotive component production
Installation Requirements
- Complete full power shutdown of PMAC mainframe before inserting or removing ACC-24E2 expansion card
- Fully align backplane edge connector pins with PMAC expansion slot receptacles for zero pin bending
- Fasten steel front panel mounting bracket to controller chassis with factory specified machine screw torque
- Adjust DIP switch termination resistance groups to match differential impedance of connected encoder cables
- Install fully shielded twisted pair differential cabling for all 24 encoder feedback channel connections
Usage Precautions
- Ambient cabinet temperature exceeding +60 °C causes FPGA frequency timing errors and position drift
- All encoder cable shielding must terminate to a single chassis ground point to avoid differential noise interference
- Signal loss fault events require full re-homing sequence for all axes within the affected channel group
- Maintain physical separation between encoder signal wiring and high-power motor drive power cables
- Power cycle PMAC mainframe after modifying on-card DIP switch termination configuration settings




Reviews
There are no reviews yet.