Technical Specifications
- Model Power Stage Rating: BUM61-2030 base unit with 30 Amp continuous output current
- DC Bus Supply Voltage Range: 540 VDC nominal shared rack DC bus input
- Control Hardware Variant Suffix: -B denotes EtherCAT industrial real-time bus communication interface
- Motor Control Modes: Torque mode, velocity mode, position closed-loop control
- Encoder Interface Support: Resolver, EnDat 2.2, incremental sine/cosine encoder feedback
- Dynamic Overload Capacity: 200% rated current for 60 seconds peak overload
- Cooling Method: Integrated base plate liquid cooling channel
- Safety Function: STO Safe Torque Off SIL3 certified hardware safety circuit
- Operating Ambient Temperature: 0°C to +55°C cabinet air temperature
Functional Features
- High bandwidth PID motion control algorithm for fast dynamic load response
- EtherCAT real-time industrial bus for synchronized multi-axis motion coordination
- Built-in regenerative braking control for energy recovery during motor deceleration
- Hardware STO safety torque off circuit compliant with machinery functional safety standards
- Auto-tuning motor parameter identification for all Baumuller servo motor models
Structural Characteristics
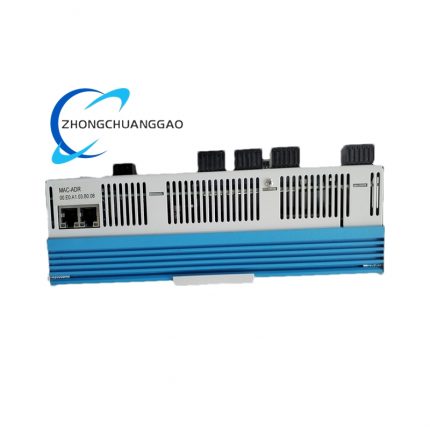
- Standard rack-mount modular single-width drive unit form factor
- Bottom integrated liquid cooling base plate with inlet/outlet fluid ports
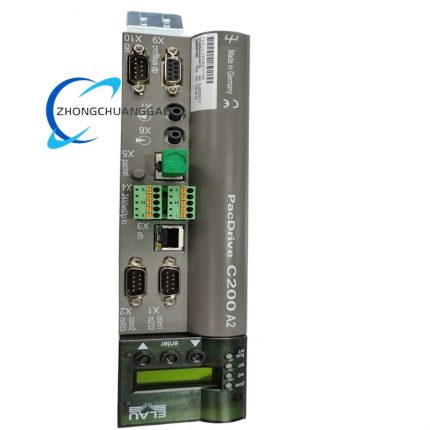
- Front panel status LED indicators, local operation control buttons and diagnostic display
- Rear high-current DC bus bar connection terminals and motor power output terminals
- Side pluggable terminal module for encoder feedback, digital I/O and EtherCAT bus wiring
Material Composition
- Drive housing: Flame retardant aluminum alloy extrusion frame
- Power semiconductor substrate: Direct bonded copper (DBC) insulated substrate
- Liquid cooling base plate: Copper alloy high thermal conductivity cooling manifold
- Control PCB: High-reliability industrial FR4 circuit board with conformal coating
- Bus bar terminals: Silver-plated copper high-current conductive hardware
Working Principle
Receive synchronized motion position command from upper-level motion controller via EtherCAT real-time bus; internal DSP digital processor executes closed-loop torque/speed/position control loop based on motor encoder position feedback; power IGBT semiconductor module converts shared 540 VDC rack DC bus power to variable frequency three-phase AC output to drive servo motor stator windings; liquid cooling base plate dissipates power stage switching loss heat to external coolant circulation system; regenerative energy from decelerating motor fed back to shared DC bus for utilization by other axes; STO safety circuit immediately disables IGBT gate drive signals upon safety interlock trigger to cut motor torque output.
Advantage Highlights
- 30A continuous high-current output suitable for heavy torque large frame servo motors
- SIL3 certified STO safety circuit meets global machinery functional safety compliance requirements
- EtherCAT bus sub-microsecond synchronization for precision multi-axis coordinated motion
- Liquid cooling design enables continuous full-load operation without cabinet forced air fans
- Native auto-identification compatible with full Baumuller servo motor product portfolio
Applicable Industries
Metal forming press automation, textile spinning multi-axis machinery, printing press drive systems, packaging heavy-duty palletizing robots, woodworking CNC machining centers, battery manufacturing automated production equipment
Installation Requirements
- Insert module into standardized Baumuller BUM61 series shared DC bus rack, lock side retention latches
- Connect liquid cooling inlet/outlet ports to closed-loop industrial coolant circulation system
- Wire motor power shielded cable to rear high-current three-phase output terminals with specified torque
- Terminate EtherCAT bus cable to side communication terminal module with proper line termination resistor
- Maintain cabinet ambient temperature below +55°C with auxiliary heat exhaust ventilation
Usage Precautions
- Do not operate unit without active liquid coolant circulation; immediate power stage thermal shutdown occurs
- Avoid hot-swap module removal while shared 540 VDC rack DC bus remains energized
- Calibrate motor auto-tune parameters after motor replacement or mechanical load modification
- Conduct quarterly insulation resistance testing on motor power output wiring
- Keep front panel ventilation slots unobstructed to maintain control board ambient cooling




Reviews
There are no reviews yet.