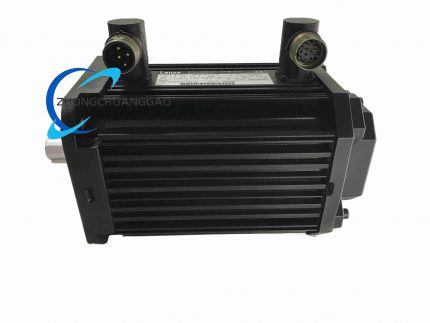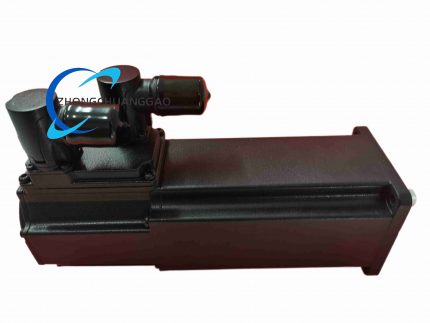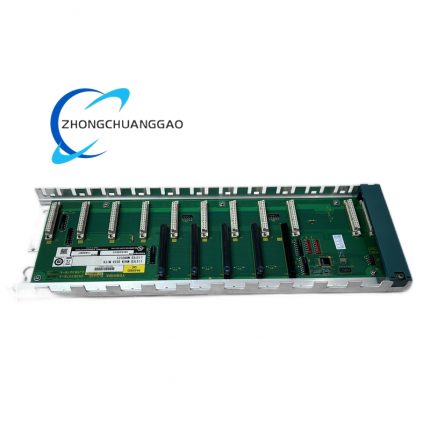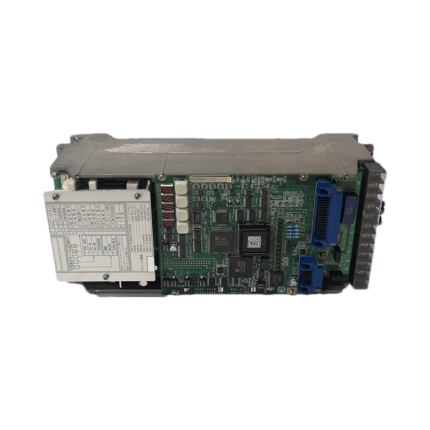
NABCO MG-800MCG-302-M1

Product Name
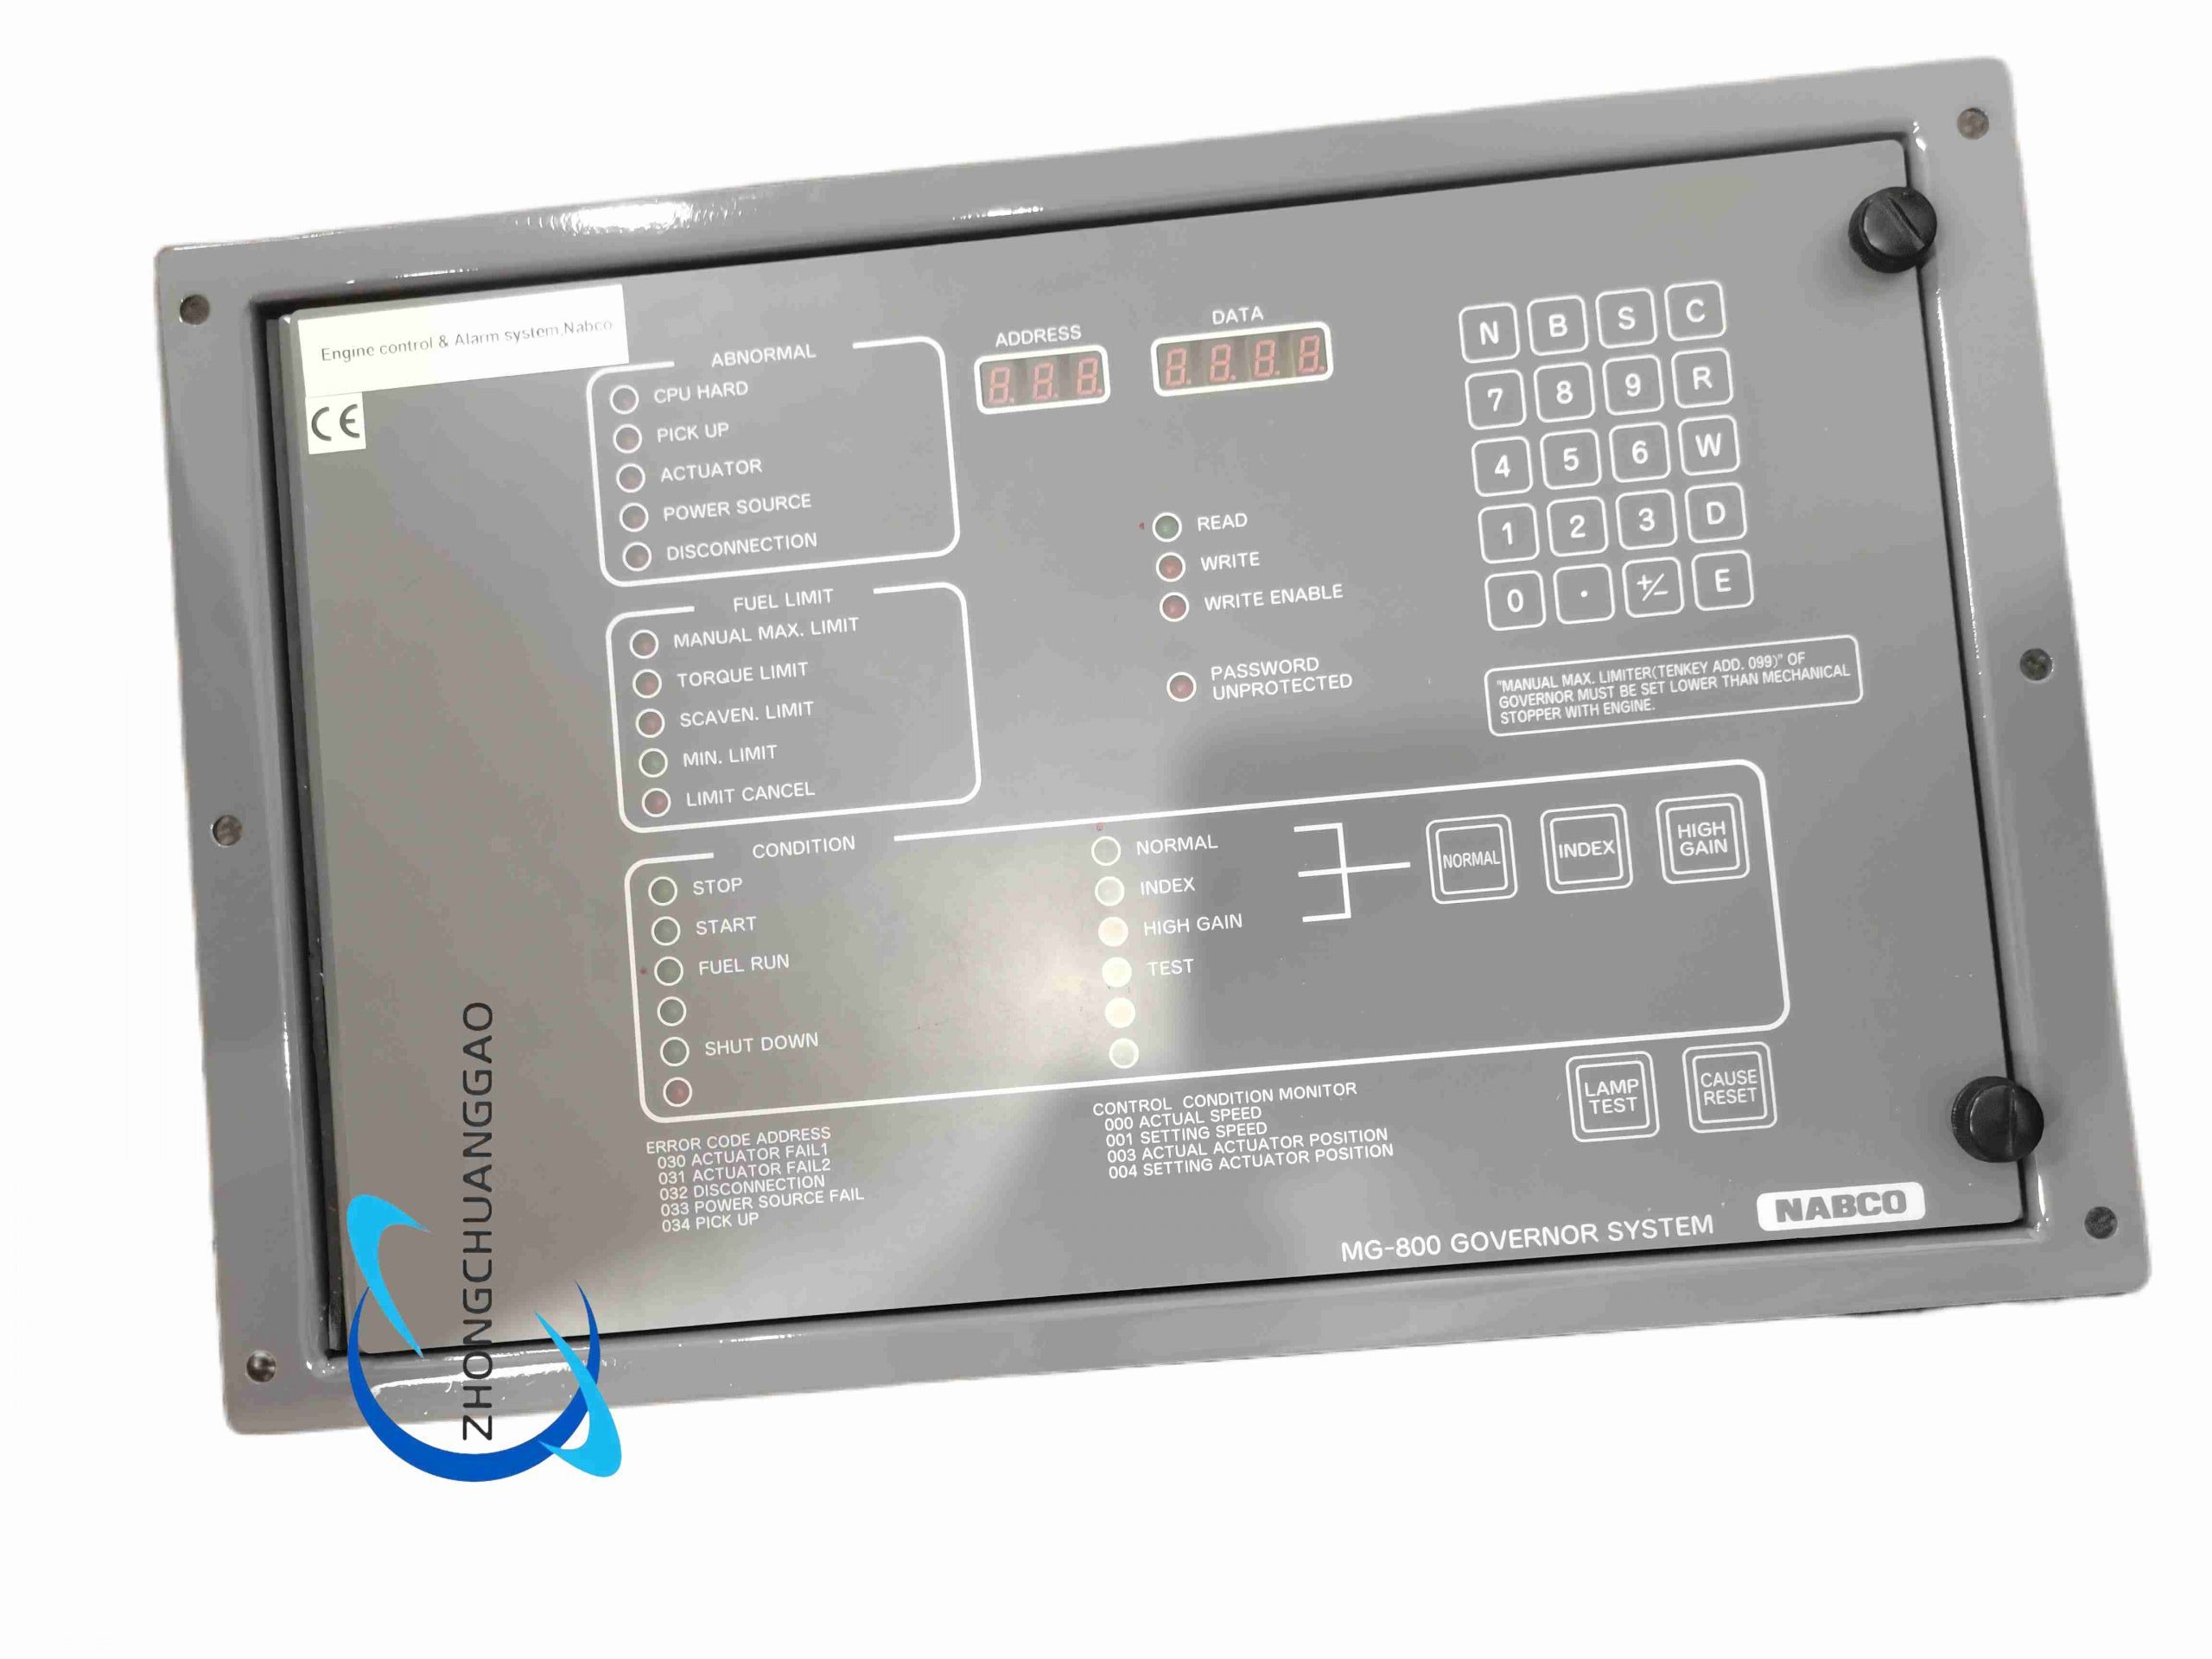
MG-800 electronic governor control unit with MCG-302 controller configuration.
Product Introduction
MG-800MCG-302-M1 belongs to the Nabtesco/NABCO MG-800 marine electronic governor platform. The MCG-302 controller processes engine speed signals and commands the actuator to regulate fuel delivery. The system maintains diesel engine speed under variable load for main propulsion and generator applications.
Category:
Description
Technical Specifications
System: MG-800 electronic governor.
Controller: MCG-302.
Configuration suffix: M1 as supplied package option.
Controller unit weight: approximately 11 kg for MCG-302/MCG-301 class units listed as part 87A109.
System power: DC 24 V and AC 100 V or 220 V, 50/60 Hz depending on supplied module.
Speed sensing: magnetic or encoder pickup compatible with MG-800 system.
Actuator interface: compatible with Nabtesco/NABCO ADU actuator drive units and EAL/EAR actuator series.
Control modes: normal, index, high-gain, direct and test according to MG-800 configuration.
Protection functions: overspeed, actuator fault, sensor fault, power-supply fault, communication fault.
Functional Features
Closed-loop RPM regulation with microcomputer control.
Adjustable speed setting, fuel limit, torque limit, scavenge limit and minimum-speed parameters.
Diagnostic alarms for sensor, actuator and power anomalies.
Fuel-saving control strategies available in MG-800 software configurations.
Stable operation during sudden load changes on marine diesel engines.
Application Scenarios
Main propulsion diesel engines, auxiliary generator sets, emergency generators, offshore power units and marine power plants requiring precise speed or load control.
Performance Parameters
The controller holds commanded engine speed against load transients by comparing actual RPM with setpoint. Actuator output positions the fuel rack or fuel-control element. Overspeed protection and fault monitoring reduce engine damage risk. High-gain mode improves stability in rough-sea load disturbances.
Material Composition
Sheet-metal or coated electronic enclosure, printed circuit boards, connectors, relays, power supply components, speed-input conditioning circuits and calibrated control potentiometers or digital interface elements.
Structural Characteristics
Central MCG-302 control unit, separate speed pickup sensor, actuator drive interface, power supply module, alarm monitoring circuit and parameter setting interface. The M1 package defines the supplied I/O and actuator configuration and must be verified from the Nabtesco configuration sheet.
Working Principle
The speed sensor measures actual engine RPM and sends the signal to the MCG-302 controller. The controller compares actual speed with the commanded setpoint. The control algorithm calculates the required actuator position and sends a command to the actuator drive. The actuator moves the fuel rack to increase or decrease fuel. Continuous feedback from speed and actuator-position sensors keeps engine speed within the preset band.
Installation Requirements
Mount the controller in an engine-control panel or machinery control room with vibration isolation. Connect the speed sensor with proper air gap and shielded cable. Install the actuator mechanically on the engine fuel mechanism. Provide independent DC 24 V control supply and the specified AC power for system modules. Ground the enclosure and separate sensor, power and actuator wiring.
Usage Precautions
Verify the M1 option sheet before commissioning because actuator type and I/O differ by package. Test overspeed and alarm functions during planned maintenance. Never bypass speed-sensor isolation during running tests. Inspect sensor gap, connector seals and power supply voltage on a scheduled interval. Use only Nabtesco/NABCO approved software and parameter backups.
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “NABCO MG-800MCG-302-M1”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.