TEKNIC M-2330-109

Product Name​
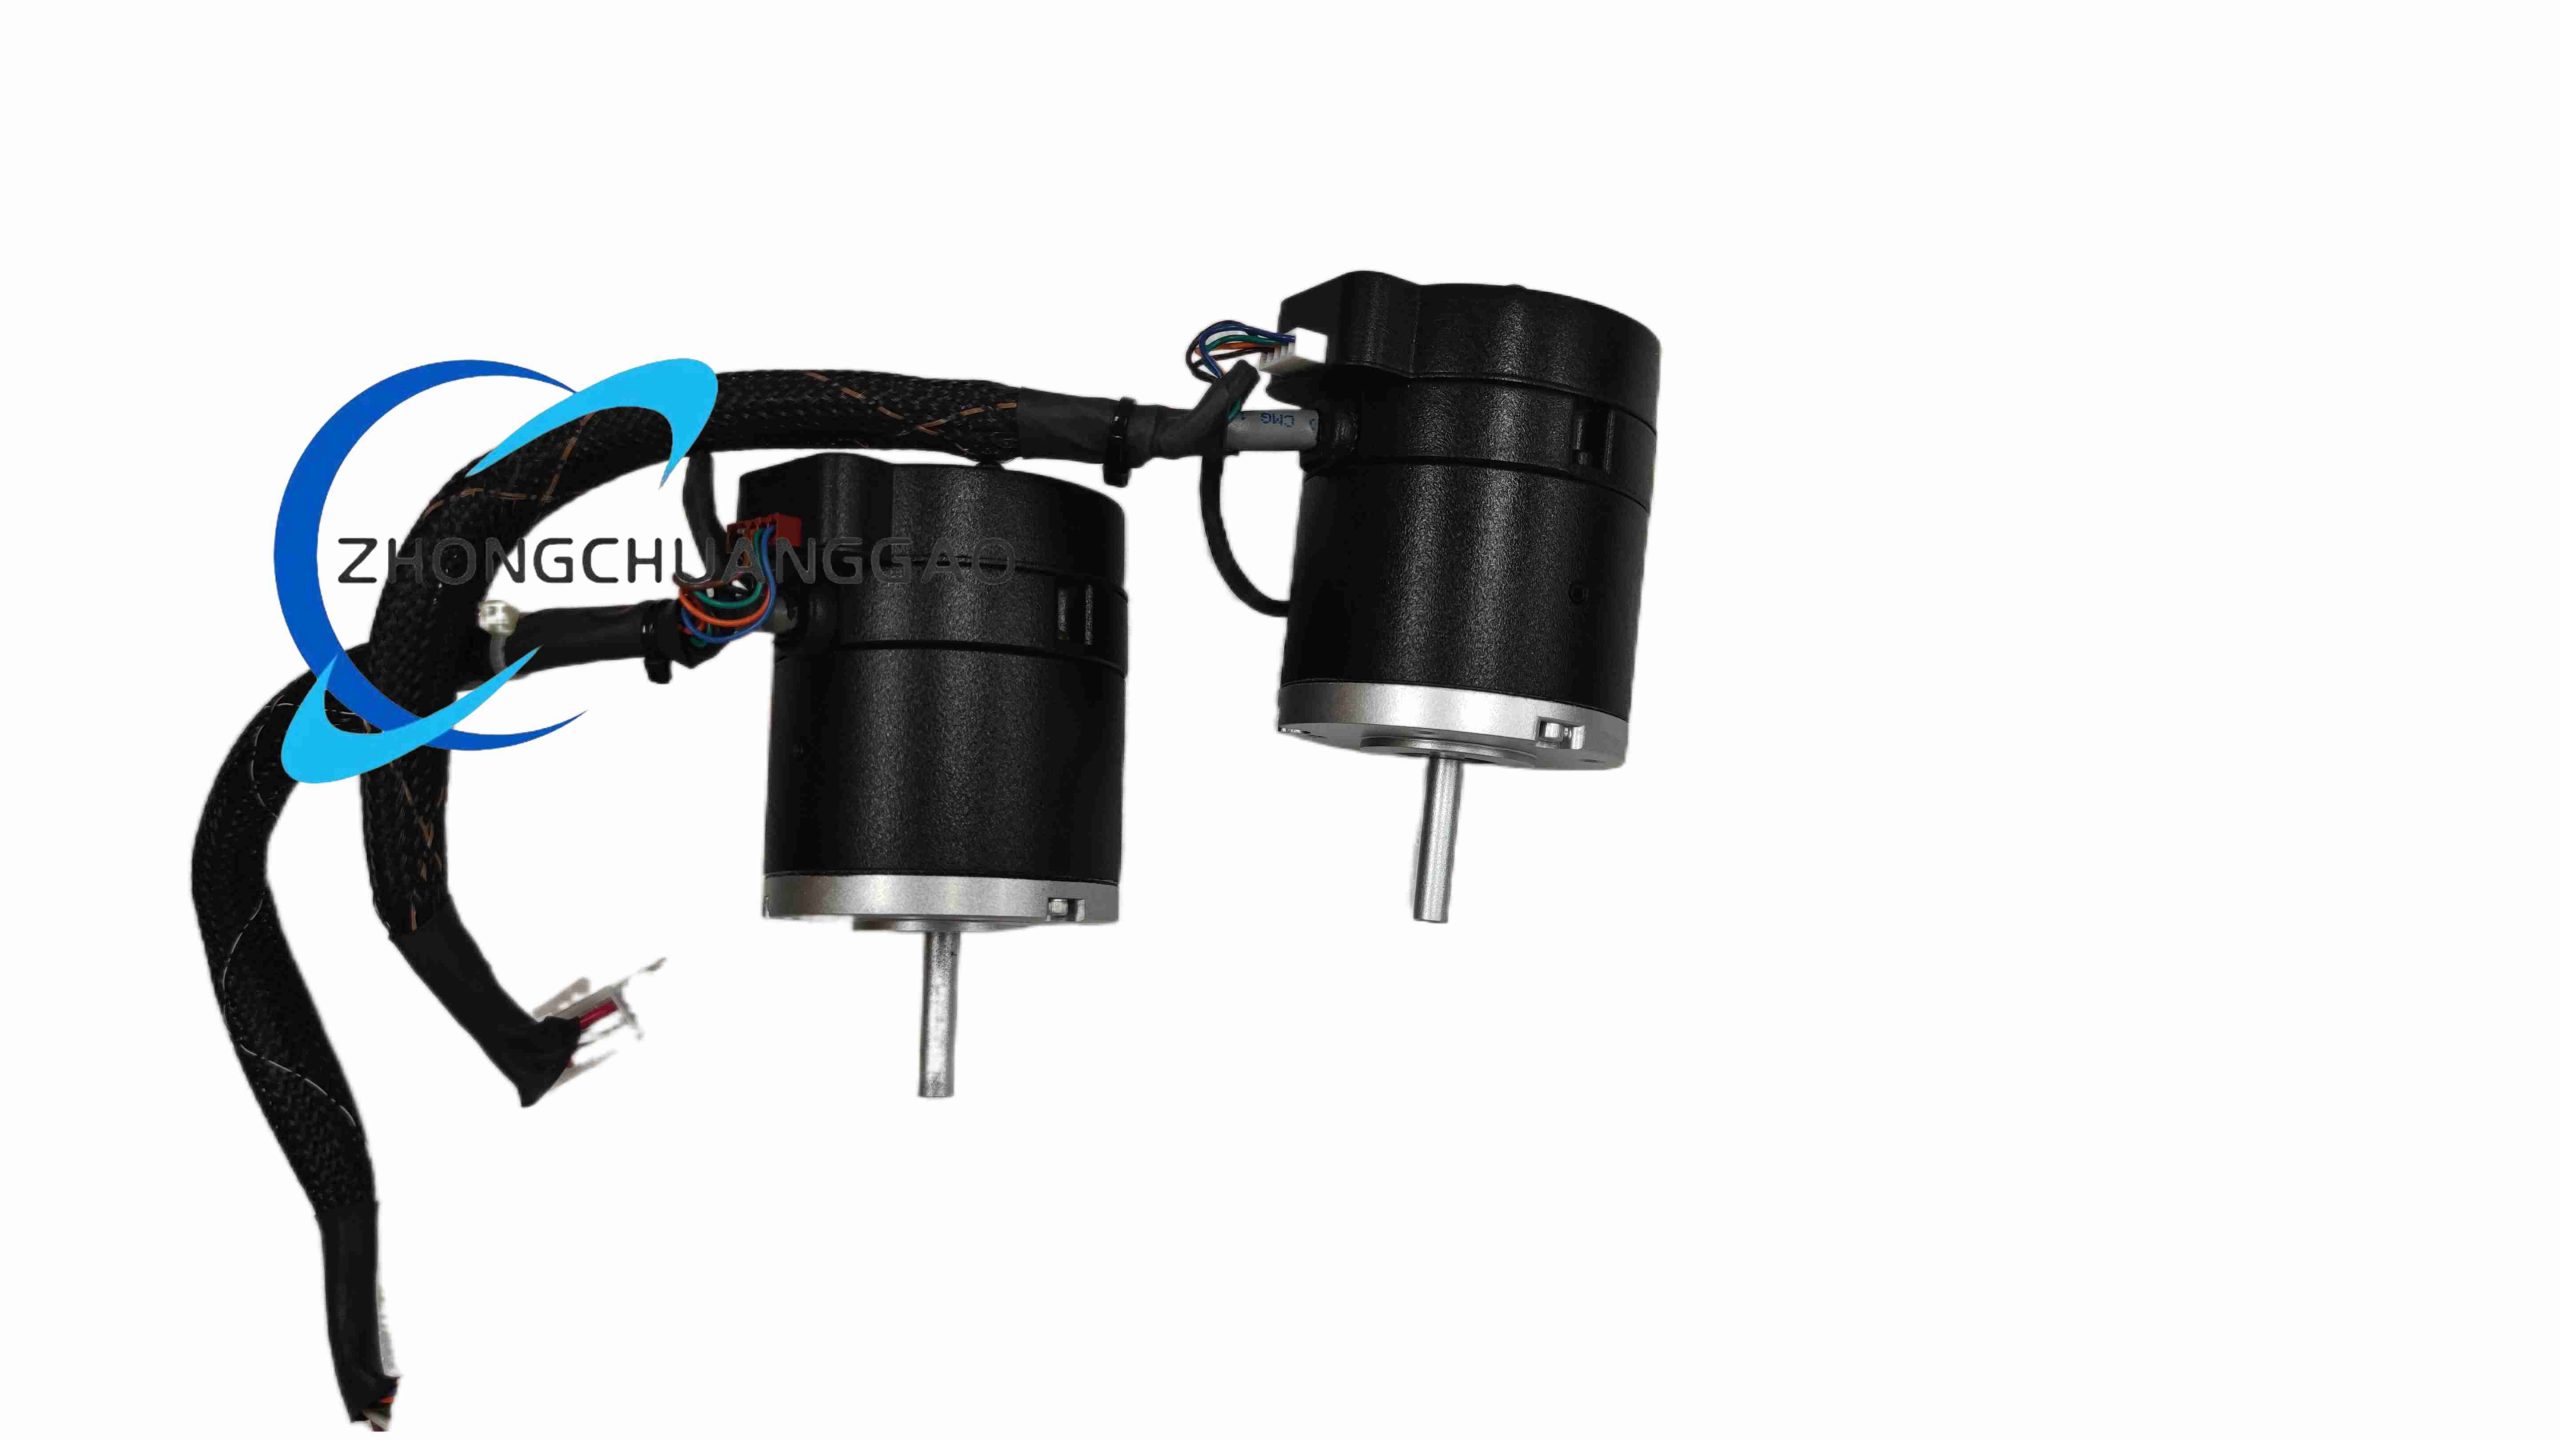
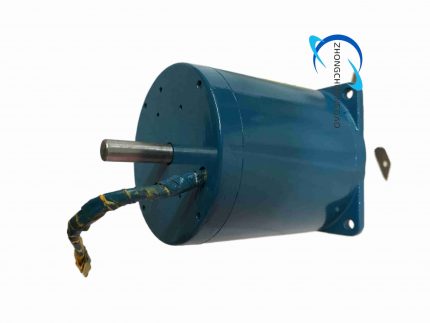
Teknic M-2330-109 NEMA 23 brushless DC servo motor with integrated encoder and Hall sensors.
Introduction​
M-2330-109 is a Hudson-series brushless servomotor in the Teknic M-2330 family. It integrates an incremental encoder and 120° Hall sensors for commutation, targeting clean-to-moderately-dirty OEM motion applications such as packaging, semiconductor handling and medical automation.
Category:
Description
Technical Specifications​
NEMA 23 frame. Brushless DC servo, rare-earth neodymium-iron-boron magnets. Operating voltage 20-90 V DC. Peak current 7.6 A. Winding resistance 0.96 ohm. Winding inductance 0.91 mH. Back-EMF constant 6.08 V peak per 1000 rpm. Continuous torque 60 oz-in, equal to 0.42 N·m. Peak torque 160 oz-in, equal to 1.13 N·m. Maximum speed 5000 rpm. Encoder 8000 counts per revolution after quadrature, 5 V DC supply, incremental optical. Hall sensors 120° for commutation. Shaft 0.25 in, equal to 6.35 mm, with flat or keyway per build. Insulation class H, 155 °C. Ingress IP53 for control-cabinet/indoor use. Connector Molex MiniFit integrated motor and feedback plug.
Functional Features​
Sinusoidal low-distortion back-EMF, Class H windings, oversized deep-groove bearings, rare-earth magnets for high power density, integrated encoder plus Hall commutation, low detent torque, low electrical time constant, powder-coated stator for thermal conduction, and shatterproof encoder module.
Application Scenarios​
Laboratory automation, semiconductor handling, medical instruments, packaging machines, light CNC axes, pick-and-place mechanisms, and OEM equipment requiring compact NEMA 23 servo torque with 8000-count feedback.
Performance Parameters​
0.42 N·m continuous, 1.13 N·m peak, 5000 rpm maximum, 20-90 V DC input, 7.6 A peak, 6.08 Vpeak/krpm back-EMF, 0.96 ohm/0.91 mH winding, 8000 counts/rev encoder, IP53, Class H insulation.
Material Composition​
Aluminum NEMA 23 housing, powder-coated stator stack, neodymium-iron-boron rotor magnets, steel shaft, deep-groove ball bearings, optical encoder disc and sensor, Hall sensor PCB, and molded MiniFit connector assembly.
Structural Characteristics​
Square NEMA 23 flange, 0.25 in output shaft, rear-mounted encoder/Hall assembly, single integrated cable connector for power, encoder and Hall where fitted, standard face-mounting holes, smooth body without heavy-duty sealed conduit entries.
Working Principle​
The controller energizes the three-phase stator windings based on Hall sensor rotor position and encoder feedback. The rare-earth rotor follows the rotating magnetic field. Back-EMF and encoder signals provide speed and position闭环 control. The servo loop regulates current for torque, velocity or position commands within the 20-90 V DC supply range.
Installation Requirements​
Mount to NEMA 23 compatible face using standard bolt pattern. Align couplings to the 6.35 mm shaft without inducing side load. Connect the MiniFit plug to a matched Teknic or compliant drive rated 20-90 V DC and 7.6 A peak. Provide 5 V encoder supply through the drive encoder interface. Ensure cabinet environment remains within IP53 expectations; add shaft seals or external shielding for washdown.
Usage Precautions​
Do not exceed 90 V DC supply or 7.6 A peak without drive authorization. Keep winding temperature within Class H limits. Avoid radial shaft loads beyond bearing specification; cited distributor data list approximately 29.9 lb center load at 1 in for related M-2330 builds. Handle encoder and Hall connectors as ESD-sensitive. Recalibrate only with approved Teknic tooling; replaced encoders may require factory alignment.
Reviews (0)

Reviews

There are no reviews yet.

Be the first to review “TEKNIC M-2330-109”

Your email address will not be published. Required fields are marked *

Shipping and Delivery

MAECENAS IACULIS

Vestibulum curae torquent diam diam commodo parturient penatibus nunc dui adipiscing convallis bulum parturient suspendisse parturient a.Parturient in parturient scelerisque nibh lectus quam a natoque adipiscing a vestibulum hendrerit et pharetra fames nunc natoque dui.

ADIPISCING CONVALLIS BULUM

  • Vestibulum penatibus nunc dui adipiscing convallis bulum parturient suspendisse.
  • Abitur parturient praesent lectus quam a natoque adipiscing a vestibulum hendre.
  • Diam parturient dictumst parturient scelerisque nibh lectus.

Scelerisque adipiscing bibendum sem vestibulum et in a a a purus lectus faucibus lobortis tincidunt purus lectus nisl class eros.Condimentum a et ullamcorper dictumst mus et tristique elementum nam inceptos hac parturient scelerisque vestibulum amet elit ut volutpat.